24 Projected entangled pair states and the Fundamental Theorem
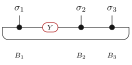
A projected entangled pair state (PEPS) is built from a finite simple graph \(G=(V,E)\) by placing a local tensor \(A_v\) at every vertex \(v\) and contracting the tensors along the edges. Each vertex carries one physical index \(\sigma (v)\in \{ 0,\ldots ,d-1\} \), and each edge \(e\) carries a virtual index of bond dimension \(D_e\) shared by its two endpoints. On a square lattice this is the picture
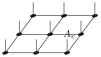
in which every black dot is a local tensor, the thin in-plane bonds are the virtual edges, and the vertical leg at each vertex is its physical index.
The state generated by \(A\) is the tensor whose coefficient at a physical configuration \(\sigma \colon V\to \{ 0,\ldots ,d-1\} \) is obtained by summing the product of the local tensors over all virtual configurations, \(c_A(\sigma )=\sum _{\eta }\prod _{v\in V}A_v(\eta _v,\sigma (v))\), where \(\eta \) ranges over the assignments of a bond index \(\eta (e)\in \{ 0,\ldots ,D_e-1\} \) to every edge and \(\eta _v\) is the family of indices that \(\eta \) places on the edges incident to \(v\). Closing every virtual bond while keeping the physical legs open gives the full state tensor; fixing the legs to a configuration \(\sigma \) evaluates the scalar \(c_A(\sigma )\). On the five-vertex example graph this is

A PEPS is injective when at every vertex the physical vectors \(A_v(\eta _v,\cdot )\in \mathbb {C}^d\), indexed by the virtual configurations \(\eta _v\) on the incident edges, are linearly independent; equivalently, the linear map they define from the coefficient space on virtual configurations into \(\mathbb {C}^d\) has trivial kernel, \(\ker A_v=\{ 0\} \):
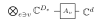
It is normal when blocking the tensors over suitable regions makes the blocked tensors injective, following [ 220 , Section 4, lines 1316–1318 ] .
Two PEPS that generate the same state need not have equal tensors. The virtual indices are internal, so on any edge \(e\) one may insert an invertible matrix \(X_e\) on one endpoint and its inverse on the other without changing any coefficient. Such a gauge on the bonds is the only freedom, and the two main results of the chapter make this precise.
For injective PEPS on a connected graph with positive bond dimensions, two tensors generate the same state if and only if they are related by a gauge on the edges, with the gauges unique modulo the balanced edge scalars of Section 24.11. A gauge always gives the same state (Theorem 24.1.2.9); the converse is the positive-bond case of [ 220 , Theorem 2 ] (Theorem 24.4.1.24).
For a normal PEPS on a connected graph the same conclusion holds once the tensors become injective after blocking suitable regions (Theorem 24.8.7; the general normal-PEPS theorem in [ 220 , Section 4 ] , following its Theorem 3).
In the citations below, [ 220 , Theorem 3 ] denotes only the translationally invariant square-lattice theorem. The connected-graph normal theorem and the normal-MPS corollaries are cited as results of [ 220 , Section 4 ] .
We begin in Section 24.1 with the core setting of PEPS on finite graphs, fixing conventions for contractions, the generated state, bond gauges, and vertex injectivity. Section 24.2 reduces a single edge to an effective three-site chain by blocking its complementary middle region. Section 24.3 turns virtual insertions into physical operations at an endpoint and extracts the per-edge gauge. Section 24.4 develops region transfer operators and proves the Fundamental Theorem for injective PEPS. Section 24.5 establishes that injective regions are closed under finite unions when bond dimensions are positive. Sections 24.6 and 24.7 supply the square-lattice and torus geometries, respectively. Section 24.8 presents the Fundamental Theorem for normal PEPS, Section 24.9 specializes it to matrix product states on closed chains, and Section 24.11 characterizes the residual gauge freedom modulo balanced edge scalars. The examples on the torus, the \(G\)-injective tensors of the quantum double models, and the ground spaces and reduced densities of finite regions follow in Chapters 25, 26, and 27.
24.1 Finite Graph Tensor Networks
We establish the tensor-network setting on finite graphs: the local tensors, the state they generate, the gauge freedom on the bonds, and the vertex injectivity condition together with the local inverse it provides.
24.1.1 PEPS tensors and the states they generate
For a finite simple graph \(G\), an edge is an ordered pair \((u,v)\) with \(u {\lt} v\) and \(u\) adjacent to \(v\). The ordering serves to avoid double counting.
For a vertex \(v\), an incident edge is an edge of \(G\) having \(v\) as one of its endpoints.
A PEPS tensor on \(G\) with physical dimension \(d\) consists of a bond dimension \(D_e\) for every edge \(e\), together with a local tensor at each vertex \(v\) whose virtual indices are indexed by the edges incident to \(v\) and whose physical index lies in \(\{ 0,\ldots ,d-1\} \). The local tensor at \(v\) has one physical leg and one virtual leg for each incident edge:

A virtual configuration assigns to every edge \(e\) one basis index in the corresponding bond space of dimension \(D_e\).
A predicate on the edges splits a virtual configuration canonically into its restrictions to the selected and unselected edges. An equality between two bond-dimension families also induces a canonical reindexing between their virtual configurations. For a vertex \(v\), selecting the incident edges splits a virtual configuration into its local labels at \(v\) and the labels on all nonincident edges.
The two restrictions recover the original edge labels on their respective domains. Reindexing acts edgewise by the corresponding identification of bond indices, commutes with piecewise merging, and splitting a piecewise merge recovers its selected and unselected inputs.
Each identity follows by evaluating at an edge and distinguishing whether that edge satisfies the selection predicate.
Given two virtual configurations and a predicate on edges, their piecewise merge reads the first configuration on selected edges and the second configuration elsewhere. For a vertex region, the regionwise merge selects precisely the edges incident to that region.
A piecewise merge reads the first input on a selected edge and the second input on an unselected edge; merging a configuration with itself leaves it unchanged. In particular, a regionwise merge reads the first input on region-incident edges and the second input on all remaining edges.
Evaluate the merge at an edge and use the defining alternative according to whether the edge is selected.
The vertex product on a region reads the first input of its regionwise merge. A product on a second region reads the second input whenever the two configurations agree on edges incident to both regions. Consequently, agreement on the boundary of a region lets the complementary product read the second input through the same merge.
Compare the local tensor entry at every vertex. Each incident edge is read from the prescribed input, while an edge incident to both regions is handled by the assumed agreement; a boundary edge is exactly the corresponding special case for a region and its complement.
Let a finite set map to the virtual configurations so that every fiber has cardinality \(n\). For every function \(g\) into an additive commutative monoid, \(\sum _x g(m(x))=n\mathbin {\boldsymbol {\cdot }}\sum _{\eta }g(\eta )\), where the first sum ranges over the finite set and the second over all virtual configurations.
Group the first sum by the value of \(m\). Each grouped summand is repeated exactly \(n\) times by the common fiber-cardinality hypothesis.
For a physical configuration \(\sigma \) on the vertices, the PEPS state coefficient is obtained by summing over all virtual configurations and, for each such configuration, multiplying the local tensor entries over all vertices.
Two PEPS tensors represent the same state if all their state coefficients agree for every physical configuration.
24.1.2 Gauge transformations on the bonds
An invertible matrix on an edge acts on its two endpoint tensors by opposite oriented insertions. Absorbing such a matrix on every edge gives a gauge transformation that leaves the generated state unchanged.
For an edge \(e=(u,w)\) with \(u{\lt}w\) and gauge \(X_e\in \mathrm{GL}(D_e)\), the gauge matrix applied at vertex \(v\) is \(X_e\) if \(v=u\) and \((X_e^{-1})^\top \) if \(v=w\).
The gauged tensor at vertex \(v\) is \(A^X_v\). For each incident edge \(ie\), write \(M_{ie}\) for the matrix specified by Definition 24.1.2.1, applied at the vertex \(v\) to the gauge on the underlying edge of \(ie\). Then
The PEPS tensor obtained by applying edge-gauge matrices to \(A\), with vertex tensors \(A^X_v\).
Given a tensor family \(B\) and an oriented gauge matrix \(X_e\) on every edge, the absorbed tensor family is \(\widetilde B=B^X\); at each vertex, its local tensor is obtained by inserting the oriented endpoint matrices on the incident virtual legs.
The absorbed tensor family has \(D_{\widetilde B}(e)=D_B(e)\) for every edge \(e\).
Since \(\widetilde B=B^X\) is defined with the same bond-dimension function as \(B\), one has \(D_{\widetilde B}(e)=D_{B^X}(e)=D_B(e)\) for every edge \(e\).
If \(M_{ie}\) is the oriented endpoint matrix attached to an incident edge \(ie\) at \(v\), then \(\widetilde B_v(\eta ,\sigma ) =\sum _{\eta '}(\prod _{ie}M_{ie}(\eta (ie),\eta '(ie))) B_v(\eta ',\sigma )\).
Expanding \(\widetilde B=B^X\) at a vertex gives \(\widetilde B_v(\eta ,\sigma )=(B^X)_v(\eta ,\sigma ) =\sum _{\eta '}(\prod _{ie}M_{ie}(\eta (ie),\eta '(ie))) B_v(\eta ',\sigma )\).
Two PEPS tensors \(A,B\) are gauge-equivalent if they have the same bond dimensions and \(B\) is obtained from \(A\) by applying invertible gauge matrices on each edge.
Applying a gauge to a PEPS tensor preserves the state coefficients. Along each internal edge, the two endpoint insertions cancel:
If \(A \sim B\) are gauge-equivalent PEPS tensors, then they represent the same state: for every physical configuration \(\sigma \),
24.1.3 Vertex injectivity and the local inverse
When the linear map from the coefficient space on virtual configurations to \(\mathbb {C}^d\), sending the basis vector at \(\eta _v\) to \(A_v(\eta _v,\cdot )\), is injective, the family is linearly independent and the map has a left inverse. This inverse turns a matrix inserted on an incident bond into an operation on the physical leg, the construction that drives the gauge extraction in later sections.
A PEPS tensor \(A\) is vertex-injective if, at every vertex \(v\), the family of physical vectors \((A_v(\eta ,\cdot )\in \mathbb {C}^d)_{\eta }\) indexed by virtual configurations \(\eta \) on the edges incident to \(v\) is linearly independent in \(\mathbb {C}^d\). Equivalently, extending \(A_v\) by linearity to a map from the free vector space on virtual configurations into the physical space \(\mathbb {C}^d\) gives a linear map with trivial kernel. This matches the injectivity formulation of [ 220 , Section 3 ] , where the local tensor is interpreted as a map from virtual configurations to the physical space.
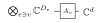 \(\ker A_v=\{ 0\} \).
For a fixed vertex \(v\), the family of local physical vectors \(\eta \mapsto A_v(\eta ,\cdot )\) extends by linearity to a map from the coefficient space on local virtual configurations at \(v\) into \(\mathbb {C}^d\).
If \(A\) is vertex-injective and \(R\) is a coefficient function on the local virtual configurations at \(v\) satisfying \(\sum _{\eta }R(\eta )A_v(\eta ,\tau )=0\) for every physical index \(\tau \), then \(R=0\).
The hypothesis says that the local tensor map sends \(R\) to the zero vector. Vertex injectivity makes this map injective, hence \(R=0\).
If the family of local physical vectors \((A_v(\eta ,\cdot ))_{\eta }\) indexed by the virtual configurations \(\eta \) at \(v\) is linearly independent, one may choose a linear map \(\Psi _v\) from \(\mathbb {C}^d\) to the coefficient space on local virtual configurations at \(v\) such that \(\Psi _v\circ \Phi _v=\mathbb {1}\).
For an endomorphism \(T\) of the coefficient space on local virtual configurations at \(v\), define the local physical operator \(O_T=\Phi _v\circ T\circ \Psi _v\).
For every coefficient function \(c\) on the local virtual configurations at \(v\), one has \(O_T(\Phi _v(c))=\Phi _v(Tc)\).
This follows from \(\Psi _v\circ \Phi _v=\mathbb {1}\).
Suppose the family of local physical vectors at \(v\) is linearly independent. If two virtual operations at \(v\) have the same canonical physical realization, then they agree.
Evaluate both physical realizations on vectors in the image of the local tensor map, where linear independence makes that map injective.
The local projector is the physical realization of the identity virtual operator, \(P_v=\Phi _v\circ \Psi _v\).
For a physical operator \(O\) on the local physical space at \(v\), define its virtual pullback by \(\Psi _v\circ O\circ \Phi _v\). This is the local injectivity step used in the physical-to-virtual direction of the insertion-algebra argument in [ 220 , Section 3 ] .
For every coefficient function \(c\), applying the local tensor map after the virtual pullback gives the projection of \(O(\Phi _v(c))\) onto the image of \(\Phi _v\).
Expand the definitions. The chosen left inverse gives \(\Psi _v\Phi _v=\mathbb {1}\), and the remaining map is the local projector.
If \(O\) sends every vector in the image of \(\Phi _v\) back into that image, then its virtual pullback realizes exactly the action of \(O\) on \(\Phi _v(c)\).
Use the preceding theorem and the image-preservation hypothesis.
Suppose the family of local physical vectors at \(v\) is linearly independent. If a physical operator \(O\) realizes a virtual operation \(T\) on every vector in the image of \(\Phi _v\), then pulling back \(O\) recovers \(T\).
After applying the local tensor map, both virtual operations have the same image. Linear independence makes the local tensor map injective, so the virtual operations agree.
Suppose the family of local physical vectors at \(v\) is linearly independent. Two physical endpoint operations then have the same virtual pullback exactly when their projected actions agree on every vector in the image of the local tensor map. For every coefficient function \(c\),
Apply the local tensor map to the two virtual pullbacks and use the pullback specification. The converse follows from injectivity of the local tensor map; the forward direction is obtained by rewriting the two virtual pullbacks.
Pulling back the canonical physical realization of a virtual operation recovers the original virtual operation.
The canonical physical realization agrees with the virtual operation on the image of the local tensor map. Apply the preceding recovery theorem.
Let \(P_v=\Phi _v\circ \Psi _v\) be the local projector, and let \(T_O=\Psi _v\circ O\circ \Phi _v\) be the virtual pullback of a physical operator \(O\). Then \(\Phi _v\circ T_O\circ \Psi _v=P_v\circ O\circ P_v\).
Expand the definitions of the physical realization, the virtual pullback, and the local projector.
Suppose that the compressed physical action \(P_vOP_v\) agrees with the canonical physical realization of a virtual operation \(T\). Then the virtual pullback of \(O\) is \(T\).
The physical realization of the virtual pullback of \(O\) is \(P_vOP_v\). By hypothesis this is the physical realization of \(T\). Injectivity of the canonical physical realization gives equality of the virtual operations.
The compressed physical action \(P_vOP_v\) is the canonical physical realization of a virtual operation \(T\) if and only if the virtual pullback of \(O\) is \(T\).
One implication follows by realizing both virtual operations physically and using the formula for the physical realization of a pulled-back operator. The converse is the preceding recovery theorem.
A matrix on one edge incident to \(v\) acts on the coefficient space of local virtual configurations by applying the matrix to that edge coordinate and summing over the input edge index while keeping the residual virtual configuration fixed.
If the coefficient function is the unit basis function at one local virtual configuration, and the matrix acts on the distinguished incident edge, the result is the sum over the new distinguished edge index with the residual local boundary held fixed.
Evaluate both sides on a local virtual configuration and split into the two cases according to whether the residual boundary agrees with the fixed residual boundary.
Applying the local tensor map after a one-edge matrix action on a basis virtual configuration gives the corresponding linear combination of local tensor components.
Use the preceding coefficient identity and linearity of the local tensor map.
If the family of local physical vectors at \(v\) is linearly independent, then a matrix acting on one edge incident to \(v\) is realized by a physical operator on the physical space at \(v\).
Apply the physical realization of local virtual operations to the one-edge matrix action.
Choosing one incident edge at \(v\) identifies the set of local virtual configurations with the product of the bond index on that edge and the residual indices on the remaining incident edges.
24.1.4 Edge-centred decomposition of a contraction
Fixing an edge \(e=(u,v)\) splits the vertex set into the two endpoints and the middle region \(V\setminus \{ u,v\} \). The state coefficient factors accordingly, which is the starting point for the edge-middle reduction of the next section.
For an edge \(e=(u,v)\), the middle region is the complement \(V\setminus \{ u,v\} \).
For an edge \(e=(u,v)\), the three regions \(\{ u\} \), \(V\setminus \{ u,v\} \), and \(\{ v\} \) cover the whole vertex set.
Every vertex is either \(u\), \(v\), or different from both.
If \(2{\lt}|V|\), then for every edge \(e=(u,v)\) the middle region \(V\setminus \{ u,v\} \) is nonempty.
The middle region has cardinality \(|V|-2\). Hence \(2{\lt}|V|\) gives \(|V|-2{\gt}0\).
For any edge \(e=(u,v)\) and any function \(f\) on the vertex set with values in a commutative monoid \(M\),
Isolate the two distinguished endpoints in the product over \(V\) and group the remaining factors into the middle region.
For any edge \(e=(u,v)\), each summand in the PEPS coefficient factors into the tensor contribution at \(u\), the product over the middle region \(V\setminus \{ u,v\} \), and the tensor contribution at \(v\).
Expand the state coefficient and apply the product splitting at the chosen edge to the per-vertex product inside each summand.
For an edge \(e=(u,v)\), the boundary data consist of the virtual index on \(e\), the remaining virtual indices incident to \(u\), and the remaining virtual indices incident to \(v\). These are the indices over which the endpoint tensors couple to the blocked middle region.
A global virtual configuration determines edge-centered boundary data by reading the index on the distinguished edge and the residual endpoint indices.
A global virtual configuration is compatible with fixed edge-centered boundary data if it has the prescribed index on the distinguished edge and the prescribed residual indices at both endpoint stars.
For fixed boundary data \(\beta \), the middle configurations are the subtype of global virtual configurations satisfying the compatibility condition with \(\beta \).
A global virtual configuration is equivalently a choice of edge-centered boundary data together with a middle configuration in the corresponding fibre.
The left endpoint local virtual configuration is reconstructed from the edge index and the residual data on the left endpoint star.
The right endpoint local virtual configuration is reconstructed from the edge index and the residual data on the right endpoint star.
If a global virtual configuration is compatible with boundary data, then its restriction to the left endpoint star is the local configuration reconstructed from those data.
If a global virtual configuration is compatible with boundary data, then its restriction to the right endpoint star is the local configuration reconstructed from those data.
For an edge \(e=(u,v)\), inserted-edge boundary data consist of two independent indices on the bond \(e\), together with the residual virtual indices incident to \(u\) and to \(v\). These are the boundary indices used when a matrix is inserted on the distinguished bond.
Ordinary edge-centered boundary data determine inserted-edge boundary data by using the same bond index at both endpoints. This is the diagonal boundary datum selected by the identity matrix in the edge-insertion coefficient.
Ordinary edge-boundary data together with an independent right endpoint bond index are equivalent to inserted-edge boundary data. The ordinary boundary supplies the left bond index and the two residual endpoint boundaries.
Ordinary edge-boundary data together with an independent left endpoint bond index are equivalent to inserted-edge boundary data. The ordinary boundary supplies the right bond index and the two residual endpoint boundaries.
The diagonal inserted-boundary configurations are those inserted-edge boundary data for which the two distinguished bond indices agree. This is the support of the identity matrix inside the inserted-boundary sum.
Ordinary edge-boundary data are equivalent to diagonal inserted-boundary data. This is the finite reindexing map used after the identity matrix has removed all off-diagonal inserted-boundary summands.
24.2 Edge-Middle Reduction
Fixing an edge \(e=(u,v)\) and blocking the whole complementary middle region \(V\setminus \{ u,v\} \) presents the state coefficient as a three-site contraction: the endpoint tensors at \(u\) and \(v\) joined through one blocked middle tensor. Inserting the identity on the bond \(e\) recovers the original coefficient, so a matrix inserted on \(e\) records the difference between two tensors that generate the same state. Injectivity of this middle tensor provides the foundation used by the edge-kernel argument of Section 24.3.
Fixing the residual boundary configurations at the endpoint vertices \(u\) and \(v\) but leaving the bond \(e\) out of the middle region, the open middle tensor is the contraction over all virtual indices away from \(e\) that are compatible with those boundary configurations.
For an edge \(e=(u,v)\), the middle physical configurations are the physical indices on the vertices in \(V\setminus \{ u,v\} \). A global physical configuration restricts to such a middle configuration.
The ordinary and open middle contractions may be written using only the middle physical configuration, rather than a physical configuration on all vertices. This is the middle tensor in the three-site chain obtained after the edge blocking in arXiv:1804.04964, Section 3.
The middle contractions written with a global physical configuration are the corresponding middle-indexed contractions evaluated on the restricted middle physical configuration.
Rewrite the product over \(V\setminus \{ u,v\} \) as the product over the corresponding finite set of middle vertices.
An ordinary middle configuration for the edge-blocked contraction restricts to a virtual configuration on all edges except the distinguished edge. This is the first reindexing map needed to compare the identity insertion with the ordinary edge-blocked middle tensor.
Conversely, a compatible open middle configuration becomes an ordinary middle configuration after the fixed edge-boundary index is restored on the distinguished edge. Together with the restriction map, this gives the finite reindexing underlying the identity-insertion specialization.
For fixed edge-boundary data, ordinary middle configurations are equivalent to compatible open-middle configurations. This is the finite reindexing used when the inserted matrix is the identity.
The ordinary middle tensor and the open middle tensor agree after restoring the fixed distinguished-edge index and reindexing the finite sum, with the physical index already restricted to the middle block.
Reindex the ordinary middle configurations by the equivalence with compatible open-middle configurations, then compare each local tensor entry.
For an edge \(e=(u,v)\) and a matrix \(X\) acting on the bond space of \(e\), the edge insertion coefficient is the contraction obtained by inserting \(X\) between the endpoint tensors and the open middle tensor:
Restoring the fixed distinguished-edge index identifies the ordinary blocked middle tensor with the open middle tensor. This is the finite reindexing used before the identity matrix collapses the two inserted bond indices to the diagonal.
Reindex the ordinary middle configurations by the finite equivalence with open-middle configurations and compare the local tensor factors pointwise.
On the diagonal boundary datum selected by the identity matrix, the inserted-edge summand is the ordinary edge-blocked summand. Thus the remaining identity-insertion step is purely a finite summation statement: the off-diagonal inserted boundary data vanish and the diagonal data reindex the ordinary edge-boundary sum.
Substitute the identity matrix entry \(\mathbb {1}_{a,a}=1\) and apply the reindexing \(C_{A,M_e}(\beta )=C^{\mathrm{open}}_{A,M_e}(\beta )\) from Theorem 24.2.10.
If the two inserted bond indices are distinct, then the corresponding summand in the identity insertion is zero. This is the pointwise off-diagonal vanishing used before the inserted-boundary sum is restricted to its diagonal part.
For \(a\ne b\), the identity matrix entry \(\mathbb {1}_{a,b}=0\) makes the inserted summand vanish.
If the inserted matrix on the distinguished edge is the identity, then the edge insertion coefficient is the ordinary edge-blocked coefficient.
Split the inserted-boundary sum according to whether the two bond indices \(a,b\) agree:
The off-diagonal sum vanishes because \(\mathbb {1}_{a,b}=0\) for \(a\ne b\), and the diagonal sum reindexes to \(C_A(e;\sigma )\) through the equivalence between diagonal inserted-boundary configurations and ordinary edge-boundary configurations.
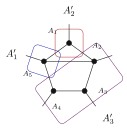
Fixing the edge-centered boundary data, the blocked middle tensor is the sum over global virtual configurations compatible with those data of the product of local tensor entries over the middle region \(V\setminus \{ u,v\} \). The graph-local contraction is read as a three-site chain:
 \(\quad \rightsquigarrow \quad \)
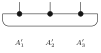
The edge-blocked coefficient is the three-block contraction obtained from the left endpoint tensor, the blocked middle tensor, and the right endpoint tensor at the chosen edge.
For every edge \(e\), the edge-blocked three-block coefficient is exactly the original PEPS state coefficient.
Write \(\operatorname{Coeff}_A(\sigma )\) for the PEPS state coefficient and \(C_A(e;\sigma )\) for the edge-blocked coefficient, and put \(e=(u,v)\) and \(M_e=V\setminus \{ u,v\} \). The equivalence \(\omega \leftrightarrow (\beta ,\omega _{M_e})\) between global virtual configurations and an edge boundary configuration with a compatible middle configuration rewrites the PEPS coefficient as
Under the equivalence, \(\omega |_u=\beta _u\) and \(\omega |_v=\beta _v\); the inner sum over \(\omega _{M_e}\) is exactly \(C_{A,M_e}(\beta ,\sigma |_{M_e})\). Thus \(C_A(e;\sigma )=\operatorname{Coeff}_A(\sigma )\).
If the inserted matrix on the distinguished edge is the identity, then the edge insertion coefficient is the original PEPS state coefficient.
Let \(e=(u,v)\) and put \(M_e=V\setminus \{ u,v\} \). With \(\mathbb {1}\) inserted on \(e\), the inserted-boundary sum is
Here \(a,b\) are the two copies of the distinguished bond index, while \(\lambda ,\rho \) are the remaining virtual configurations at \(u\) and \(v\). The factor \(\delta _{a,b}\) leaves only the diagonal \(a=b\), and the open-middle reindexing gives \(C^{\mathrm{open}}_{A,M_e}(\lambda ,\rho ;\sigma |_{M_e}) =C_{A,M_e}(a,\lambda ,\rho ;\sigma |_{M_e})\). Hence \(C_A(e,\mathbb {1};\sigma )=C_A(e;\sigma )=\operatorname{Coeff}_A(\sigma )\).
If two PEPS tensors \(A\) and \(B\) represent the same state, then their edge-blocked coefficients agree at every edge \(e\) and every physical configuration \(\sigma \):
For every physical configuration \(\sigma \), \(C_A(e;\sigma )=\operatorname{Coeff}_A(\sigma )=\operatorname{Coeff}_B(\sigma )=C_B(e;\sigma )\).
If two PEPS tensors \(A\) and \(B\) represent the same state, then their edge-centered identity insertions agree at every edge \(e\) and every physical configuration \(\sigma \):
For every physical configuration \(\sigma \), \(C_A(e,\mathbb {1};\sigma )=\operatorname{Coeff}_A(\sigma ) =\operatorname{Coeff}_B(\sigma )=C_B(e,\mathbb {1};\sigma )\).
For the edge-blocked three-site chain at \(e=(u,v)\), the middle tensor is the family obtained by fixing the two residual endpoint boundaries and evaluating the open middle contraction on the middle physical index. Its injectivity is the middle-block part of the assertion following the edge-blocking diagram.
If the virtual configuration space on the complement of the distinguished edge is empty, then for every residual boundary label \(\rho \) the vector \(T_{A,M_e}^{\rho }\) in the edge-middle tensor family is zero.
The finite sum defining the open middle tensor is taken over the empty complement configuration space, and is therefore zero.
If the complement configuration space is empty and the residual boundary-label set is nonempty, then the edge-middle tensor family is not injective.
Choose a residual boundary label. By Lemma 24.2.21 its middle-tensor vector is the zero vector. A linearly independent family cannot contain a zero vector.
For a chosen edge \(e=(u,v)\), the edge-blocked three-site chain is injective when the left endpoint tensor map, the middle tensor family, and the right endpoint tensor map are all injective.
For a singleton block \(\{ v\} \), the blocked physical index is the original physical index and the blocked tensor is \(T_{A,\{ v\} }(\eta ,\sigma )=A_v(\eta ,\sigma )\). Its injectivity is \(\operatorname{inj}(T_{A,\{ v\} })\). The comparison with a region-injectivity predicate \(\kappa \) records the implication \(\operatorname{inj}(T_{A,\{ v\} })\Longrightarrow \kappa (\{ v\} )\).
Let \(A\) be vertex-injective with every bond dimension positive. Then the concrete region-injectivity predicate of \(A\) satisfies the singleton comparison: injectivity of a singleton blocked tensor implies injectivity of the corresponding singleton region.
Under vertex injectivity and positive bond dimensions every finite region is injective. In particular the singleton region \(\{ v\} \) is injective, so the comparison holds independently of the singleton-tensor hypothesis.
If \(A\) is vertex-injective, then every singleton blocked tensor is injective. For every vertex \(v\), \(\operatorname{inj}(T_{A,\{ v\} })\).
For \(R=\{ v\} \), the contraction defining \(T_{A,R}\) has one factor. Hence \(T_{A,\{ v\} }(\eta ,\sigma )=A_v(\eta ,\sigma )\). Thus \(\operatorname{inj}(A_v)\) is exactly \(\operatorname{inj}(T_{A,\{ v\} })\). Vertex injectivity gives \(\forall v,\operatorname{inj}(A_v)\), and therefore \(\forall v,\operatorname{inj}(T_{A,\{ v\} })\). For a fixed \(v\), this is the displayed assertion.
Assume that a region-injectivity predicate \(\kappa \) satisfies, for every vertex \(v\), \(\operatorname{inj}(T_{A,\{ v\} })\Longrightarrow \kappa (\{ v\} )\). Then, for every vertex \(v\), \(A\text{ vertex-injective}\Longrightarrow \kappa (\{ v\} )\).
For each \(v\), Theorem 24.2.26 gives \(A\text{ vertex-injective}\Longrightarrow \operatorname{inj}(T_{A,\{ v\} })\). The comparison hypothesis gives \(\operatorname{inj}(T_{A,\{ v\} })\Longrightarrow \kappa (\{ v\} )\). Their composition is the claimed implication.
Assume that \(\kappa \) satisfies singleton comparison and union closure: \(\operatorname{inj}(T_{A,\{ v\} })\Longrightarrow \kappa (\{ v\} )\) for every vertex \(v\), and \(\kappa (R)\wedge \kappa (S)\Longrightarrow \kappa (R\cup S)\). If \(A\) is vertex-injective, then every nonempty finite region \(R\) satisfies \(\kappa (R)\).
For \(R\ne \varnothing \), write \(R=\bigcup _{v\in R}\{ v\} \). Theorem 24.2.27 turns singleton comparison and vertex injectivity into \(\kappa (\{ v\} )\) for every \(v\in R\). Applying the finite-union consequence of union closure to these singleton regions gives \(\kappa (R)\).
A comparison from finite-region injectivity to the edge-middle tensor records the following assertion: if the middle vertex region \(V\setminus \{ u,v\} \) is injective after blocking, then the middle tensor in the edge-blocked three-site chain is injective. This isolates the finite-region contraction claim in [ 220 , Section 3 ] .
If the original PEPS tensor \(A\) is vertex-injective, then for each edge \(e=(u,v)\), the two endpoint tensor maps in the edge-blocked three-site chain are injective:
If \(e=(u,v)\), vertex injectivity gives \(\operatorname{inj}(T_{A,u})\) and \(\operatorname{inj}(T_{A,v})\), which are the left and right endpoint tensor maps of the edge-blocked chain.
For a vertex-injective PEPS tensor \(A\), injectivity of the edge-blocked middle tensor gives the full injectivity statement for the edge-blocked three-site chain at \(e=(u,v)\):
where \(M_e = V\setminus \{ u,v\} \).
Let \(e=(u,v)\) and put \(M_e=V\setminus \{ u,v\} \). The endpoint theorem supplies \(\operatorname{inj}(T_{A,u})\) and \(\operatorname{inj}(T_{A,v})\), while the hypothesis is \(\operatorname{inj}(T_{A,M_e})\). Hence \(\operatorname{inj}(T_{A,u})\wedge \operatorname{inj}(T_{A,M_e})\wedge \operatorname{inj}(T_{A,v})\).
If every edge-middle tensor is injective, then a vertex-injective PEPS tensor \(A\) gives an injective edge-blocked three-site chain at every edge \(e=(u,v)\):
For each \(e=(u,v)\), put \(M_e=V\setminus \{ u,v\} \). Vertex injectivity gives \(\operatorname{inj}(T_{A,u})\) and \(\operatorname{inj}(T_{A,v})\), while the hypothesis gives \(\operatorname{inj}(T_{A,M_e})\). Hence \(\operatorname{inj}(T_{A,u})\wedge \operatorname{inj}(T_{A,M_e})\wedge \operatorname{inj}(T_{A,v})\) is the injectivity assertion for the edge-blocked three-site chain at \(e\).
Suppose the middle region \(V\setminus \{ u,v\} \) is injective after blocking, and suppose this region-injectivity assertion has been identified with injectivity of the corresponding edge-middle tensor family. Then a vertex-injective PEPS tensor gives an injective edge-blocked three-site chain at the edge \(e=(u,v)\).
Let \(e=(u,v)\) and put \(M_e=V\setminus \{ u,v\} \). The comparison gives \(\kappa (M_e)\Longrightarrow \operatorname{inj}(T_{A,M_e})\). Vertex injectivity supplies \(\operatorname{inj}(T_{A,u})\) and \(\operatorname{inj}(T_{A,v})\). Theorem 24.2.31 then gives \(\operatorname{inj}(T_{A,u})\wedge \operatorname{inj}(T_{A,M_e})\wedge \operatorname{inj}(T_{A,v})\).
Suppose every edge-middle region \(V\setminus \{ u,v\} \) is injective after blocking, and suppose finite-region injectivity has been identified with injectivity of the corresponding edge-middle tensor family. Then every edge-middle tensor family is injective.
For each edge \(e=(u,v)\), put \(M_e=V\setminus \{ u,v\} \). The hypotheses give \(\kappa (M_e)\). The comparison implication \(\kappa (M_e)\Longrightarrow \operatorname{inj}(T_{A,M_e})\) yields \(\operatorname{inj}(T_{A,M_e})\) for every edge.
Suppose every edge-middle region \(V\setminus \{ u,v\} \) is injective after blocking, and suppose finite-region injectivity has been identified with injectivity of the corresponding edge-middle tensor family. Then a vertex-injective PEPS tensor gives an injective edge-blocked three-site chain at every edge.
For every edge \(e=(u,v)\), put \(M_e=V\setminus \{ u,v\} \). The region hypothesis gives \(\kappa (M_e)\), and the comparison gives \(\kappa (M_e)\Longrightarrow \operatorname{inj}(T_{A,M_e})\). Vertex injectivity gives \(\operatorname{inj}(T_{A,u})\) and \(\operatorname{inj}(T_{A,v})\). Thus \(\operatorname{inj}(T_{A,u})\wedge \operatorname{inj}(T_{A,M_e})\wedge \operatorname{inj}(T_{A,v})\).
Let \(e=(u,v)\) and put \(M_e=V\setminus \{ u,v\} \). Assume \(M_e\ne \varnothing \). Assume also singleton comparison, union closure for \(\kappa \), and the comparison \(\kappa (M_e)\Longrightarrow \operatorname{inj}(T_{A,M_e})\). If \(A\) is vertex-injective, then the edge-middle tensor family \(T_{A,M_e}\) is injective.
The finite-region theorem applied to \(M_e=\bigcup _{w\in M_e}\{ w\} \) gives \(\kappa (M_e)\). The edge-middle comparison sends this to \(\operatorname{inj}(T_{A,M_e})\).
Let \(e=(u,v)\) and put \(M_e=V\setminus \{ u,v\} \). Under the hypotheses of Theorem 24.2.36, vertex injectivity of \(A\) gives injectivity of the edge-blocked three-site chain at \(e\).
Theorem 24.2.36 gives \(\operatorname{inj}(T_{A,M_e})\). The endpoint reduction combines this middle-tensor injectivity with vertex injectivity at \(u\) and \(v\).
If \(M_e=V\setminus \{ u,v\} \) is nonempty for every edge \(e=(u,v)\), then Theorem 24.2.37 applies at every edge. Thus vertex injectivity of \(A\) gives injectivity of every edge-blocked three-site chain.
Apply the one-edge statement separately to each edge \(e\).
Assume singleton comparison, union closure for \(\kappa \), the comparison \(\kappa (M_e)\Longrightarrow \operatorname{inj}(T_{A,M_e})\), and vertex injectivity of \(A\). If \(2{\lt}|V|\), then \(V\setminus \{ u,v\} \ne \varnothing \) for every edge \(e=(u,v)\), and these hypotheses give \(\operatorname{inj}(T_{A,V\setminus \{ u,v\} })\) and edge-blocked three-site injectivity at every edge.
24.3 Edge Kernels and Gauge Transport
When the endpoint tensors are injective, a matrix inserted on the bond \(e\) is realized by a physical operation on a neighbouring physical leg, and conversely. This sets up an isomorphism between the bond-\(e\) matrix algebra of \(A\) and that of \(B\), which by the Skolem–Noether theorem is conjugation by an invertible matrix \(X_e\), the edge gauge: for every physical configuration \(\sigma \) and bond matrix \(M\), \(C_A(e,\sigma ,M)=C_B(e,\sigma ,X_eMX_e^{-1})\). Collecting the \(X_e\) over all edges and reconciling them on the shared bonds produces the global gauge family that relates the two tensors.
Let \(V\) be a vertex type with decidable equality. A finite kernel descent datum is a predicate \(K\) on finite subsets \(S\subseteq V\) together with implications \(j\in S\Longrightarrow K(S)\Longrightarrow K(S\setminus \{ j\} )\). In the edge-blocking proof, \(K(S)\) is the assertion that the boundary coefficients \(c_{\rho }\), with the virtual indices exposed at that stage, give zero after the tensors in \(S\) have been contracted.
For a finite kernel descent datum and any finite \(R\subseteq V\), \(K(R)\Longrightarrow K(\varnothing )\). More generally, if \(K(\varnothing )\Longrightarrow Q\), then \(K(R)\Longrightarrow Q\).
Induct on the finite set \(R\). If \(R=\varnothing \), there is nothing to prove. Otherwise write \(R=S\cup \{ j\} \) with \(j\notin S\). The deletion implication gives \(K(R)\Longrightarrow K(S)\), and the induction hypothesis gives \(K(S)\Longrightarrow K(\varnothing )\).
Let \(e=(u,v)\) and \(M_e=V\setminus \{ u,v\} \). An edge-middle kernel descent datum is indexed by boundary labels \(\rho \) consisting of the two residual endpoint configurations. It assigns to every finitely supported coefficient family \(c=(c_{\rho })_{\rho }\) a finite kernel descent datum \(K_c(S)\) such that
Let \(e=(u,v)\) and \(M_e=V\setminus \{ u,v\} \). If an edge-middle kernel descent datum is given, then \(T_{A,M_e}\) is injective. Consequently, if \(A\) is vertex-injective, the edge-blocked three-site chain at \(e\) is injective.
Let \(c=(c_{\rho })_{\rho }\) be a finite linear relation among the middle tensor vectors: \(\sum _{\rho }c_{\rho }T_{A,M_e}^{\rho }(\tau )=0\) for every \(\tau \). The initial part of the descent datum gives \(K_c(M_e)\). The finite descent lemma gives \(K_c(M_e)\Longrightarrow K_c(\varnothing )\), and the terminal part gives \(\forall \rho ,\ c_{\rho }=0\). Thus every finite relation is trivial, which is \(\operatorname{inj}(T_{A,M_e})\). Vertex injectivity at \(u\) and \(v\) gives \(\operatorname{inj}(T_{A,u})\) and \(\operatorname{inj}(T_{A,v})\); the edge-blocked three-site injectivity at \(e\) follows.
For a tensor map or blocked tensor family \(T\), write \(\operatorname{inj}(T)\) for the assertion that \(T\) is injective. If \(A\) is vertex-injective and every bond dimension is positive, then for every edge \(e=(u,v)\), \(\operatorname{inj}(T_{A,u})\), \(\operatorname{inj}(T_{A,V\setminus \{ u,v\} })\), and \(\operatorname{inj}(T_{A,v})\). Here \(T_{A,u}\) and \(T_{A,v}\) are the two endpoint tensor maps, and \(T_{A,V\setminus \{ u,v\} }\) is the blocked middle tensor family. This is the precise assertion after the edge-blocking diagram in [ 220 , Section 3 ] . The positive-bond hypothesis is the source’s standing assumption that injective PEPS have nonzero virtual bond spaces. Without it, an empty complement configuration space can make the middle tensor vanish identically; Lemmas 24.2.21 and 24.2.22 record this obstruction.
Fix \(e=(u,v)\) and put \(M_e=V\setminus \{ u,v\} \). From vertex injectivity, construct the edge-middle descent datum required by Theorem 24.3.4: for each finite relation \(\sum _{\rho }c_{\rho }T_{A,M_e}^{\rho }(\tau )=0\) for every \(\tau \), the associated conditions \(K_c(S)\) satisfy \(K_c(M_e)\), \(j\in S\Longrightarrow K_c(S)\Longrightarrow K_c(S\setminus \{ j\} )\), and \(K_c(\varnothing )\Longrightarrow \forall \rho ,\ c_{\rho }=0\). The descent implication is the local contraction identity: for \(j\in S\), vertex injectivity at \(j\) gives a left inverse \(L_j\), and applying \(L_j\) to the relation contracts away that tensor, \(j\in S,\ K_c(S)\mathrel {\stackrel{L_j}{\Longrightarrow }} K_c(S\setminus \{ j\} )\). The contraction at \(j\) uses the factorization
where \(\mathcal{C}_e\) is the complement virtual-configuration space for the distinguished edge \(e\) and \(\mathcal{V}_j\) is the local virtual configuration space at \(j\). The terminal step \(K_c(\varnothing )\Longrightarrow \forall \rho ,\ c_{\rho }=0\) isolates each boundary coefficient by surjectivity of the boundary labelling, which is where the positive bond dimensions are used to fill the interior virtual indices of a witness configuration. The kernel descent theorem gives \(\operatorname{inj}(T_{A,M_e})\). The same theorem, together with vertex injectivity at \(u\) and \(v\), gives \(\operatorname{inj}(T_{A,u})\), \(\operatorname{inj}(T_{A,M_e})\), and \(\operatorname{inj}(T_{A,v})\) as the edge-blocked three-site injectivity assertion.
Let \(A\) be vertex-injective and let \(e=(u,v)\) be an edge. For every matrix \(M\) on the bond space of \(e\), the one-leg virtual action induced by \(M\) on the local tensor at \(u\), and likewise at \(v\), is realized by a physical operator on that endpoint’s physical space. On a closed three-site chain, the corresponding state equality is
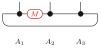 \( = \)
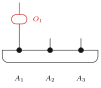 \( = \)
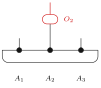
Apply the one-edge realization theorem to the two endpoint incidences of the distinguished edge.
Let \(e=(u,v)\) and suppose the family of local physical vectors at the left endpoint \(u\) is linearly independent. A physical operator at that endpoint then pulls back to the one-edge virtual action of \(M^{\mathsf T}\) if and only if its compressed physical action is the canonical realization of that one-edge virtual action.
This is the projected local recovery equivalence applied to the left incident edge of \(e\), with the transpose convention used by the left-endpoint coefficient identity.
Let \(e=(u,v)\) and suppose the family of local physical vectors at the right endpoint \(v\) is linearly independent. A physical operator at that endpoint then pulls back to the one-edge virtual action of \(M\) if and only if its compressed physical action is the canonical realization of that one-edge virtual action.
This is the projected local recovery equivalence applied to the right incident edge of \(e\).
Let \(e=(u,v)\). If \(P_uO_1P_u=\Phi _uT_{u,e}(M^{\mathsf T})\Psi _u\) and \(P_vO_2P_v=\Phi _vT_{v,e}(M)\Psi _v\), then \(\Psi _uO_1\Phi _u=T_{u,e}(M^{\mathsf T})\) and \(\Psi _vO_2\Phi _v=T_{v,e}(M)\). Here \(T_{w,e}(N)\) denotes the virtual operator on the legs incident to \(w\) which acts by \(N\) on the leg belonging to \(e\) and by the identity on the other incident legs.
The endpoint equivalences give
The two hypotheses are the left sides of these equivalences.
Let \(e=(u,v)\). Suppose that \(P_uO_1P_u=\Phi _uT_{u,e}(M^{\mathsf T})\Psi _u\) and \(P_vO_2P_v=\Phi _vT_{v,e}(M)\Psi _v\). Suppose also that \(O_1\) maps the image of \(\Phi _u\) into itself and \(O_2\) maps the image of \(\Phi _v\) into itself. Then
The preceding endpoint theorem identifies the two virtual pullbacks with the one-edge actions of \(M^{\mathsf T}\) and \(M\). The pullback specification gives the projected physical actions, and the image-preservation hypotheses remove the endpoint projectors.
Let \(e=(u,v)\) and let \(\sigma \) be a physical configuration. If a physical operator on \(v\) realizes the one-edge virtual matrix action on the distinguished incident edge, then the inserted-edge coefficient at \(\sigma \) is obtained by leaving the left endpoint and open middle contraction explicit and applying that physical operator to the right endpoint tensor.
Expand the physical realization on a basis local configuration at the right endpoint. The resulting sum over the right bond index is then reindexed together with the ordinary edge-boundary data.
Let \(e=(u,v)\) and let \(\sigma \) be a physical configuration. If a physical operator on \(u\) realizes the one-edge virtual action of \(M^{\mathsf T}\) on the distinguished incident edge, then the inserted-edge coefficient for \(M\) at \(\sigma \) is obtained by applying that physical operator to the left endpoint tensor and leaving the open middle contraction and the right endpoint explicit.
Expand the physical realization on a basis local configuration at the left endpoint. The transpose converts the ordinary right bond index and the new left bond index into the coefficient \(M_{ij}\); the resulting finite sum is then reindexed with the ordinary edge-boundary data.
If the PEPS tensor is vertex-injective, then for every physical configuration \(\sigma \), each inserted edge matrix is realized by physical operators at the endpoint tensors: the left endpoint realizes \(M^{\mathsf T}\), the right endpoint realizes \(M\), and both realizations reproduce the same inserted-edge coefficient at \(\sigma \) in the edge-centered three-site decomposition.
Apply the local physical-realization theorem at the two endpoints and then use the two coefficient identities above.
Let \(e=(u,v)\). Assume that the edge-blocked three-site chain at \(e\) is injective and that every virtual bond has positive dimension. Let \(O_1,O_2\) be physical operators at the endpoint tensors, and write \(\Phi _u,\Phi _v\) for the two local tensor maps. Suppose that, for every physical configuration \(\sigma \),
Then
The same implication is represented diagrammatically by the \(O_1,O_2\mapsto W\) step:
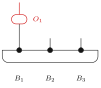 \( = \)
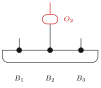 \( \Longrightarrow \)
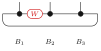
This is the converse part of the insertion-algebra lemma in [ 220 , Section 3 ] , where the recovered matrix is denoted \(W\).
Contracting the middle block out of the hypothesis leaves a bond-contracted identity between the two endpoint tensors, holding for every residual boundary configuration. Inverting the right endpoint of this identity writes the action of \(O_1\) on a left tensor vector as a bond-indexed combination of left tensor vectors with the same residual; the combining coefficients are read at a fixed reference right residual and define \(M\). Inverting the left endpoint writes the action of \(O_2\) on a right tensor vector as a bond-indexed combination of right tensor vectors. The left inverse identifies the two coefficient families, which is the source step \(V=W\), so the right-endpoint combination is also governed by \(M\). The reference residuals exist because every virtual bond has positive dimension.
Let the edge-blocked three-site chain of \(B\) at \(e\) be injective, and assume every virtual bond of \(B\) has positive dimension. If two matrices \(M,M'\in M_{D_B(e)}(\mathbb {C})\) give the same inserted coefficient at every physical configuration, \(C_B(e,\sigma ,M)=C_B(e,\sigma ,M')\) for every \(\sigma \), then \(M=M'\).
Realize \(M\) on the right endpoint and \(M'^{\mathsf T}\) on the left endpoint. The endpoint realizations and the equality \(C_B(e,\sigma ,M)=C_B(e,\sigma ,M')\) give, for every physical configuration \(\sigma \),
Theorem 24.3.14 gives a single virtual matrix realizing both endpoint operators. Endpoint uniqueness then identifies this matrix with \(M\) and with \(M'\).
For two PEPS tensors \(A\) and \(B\) and an edge \(e\), this property is
Suppose the two edge-blocked three-site chains associated to \(A\) and \(B\) at the edge \(e\) are injective, suppose every virtual bond of \(A\) and \(B\) has positive dimension, and suppose the two PEPS tensors define the same state. Then
This is the edge-blocked form of the algebra isomorphism \(X\mapsto Y\) in [ 220 , Section 3 ] :
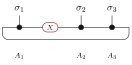 \(=\)
For a matrix \(X\in M_{D_A(e)}(\mathbb {C})\), realize the insertion of \(X\) at the two endpoints of the first edge-blocked chain by physical operators \(O_1,O_2\). Write \(C_{\mathrm{mid}}^A\) and \(C_{\mathrm{mid}}^B\) for the open middle weights of the two edge-blocked chains. For every physical configuration \(\sigma \), endpoint realization of \(X\) and equality of the PEPS states give
and
Therefore, for every physical configuration \(\sigma \),
The positive-bond physical-to-virtual recovery applied to the second edge-blocked chain gives a matrix \(Y\in M_{D_B(e)}(\mathbb {C})\) such that \(C_A(e,\sigma ,X)=C_B(e,\sigma ,Y)\) for every physical configuration \(\sigma \). Thus \(X\mapsto Y\) gives the required coefficient correspondence. Denote this correspondence by \(T\). For every physical configuration \(\sigma \),
Similarly, \(T(cX)=cT(X)\). The multiplicative identity is read from the inserted two-endpoint realization:
The unit satisfies \(C_B(e,\sigma ,T(1))=C_A(e,\sigma ,1)=C_B(e,\sigma ,1)\). Theorem 24.3.15 identifies the inserted matrices in these coefficient identities. Exchanging \(A\) and \(B\) gives the inverse correspondence, hence a \(\mathbb {C}\)-algebra isomorphism.
If the full matrix algebras \(M_{D}(\mathbb {C})\) and \(M_{E}(\mathbb {C})\) are isomorphic as \(\mathbb {C}\)-algebras, then \(D=E\).
The isomorphism preserves complex vector-space dimension, and \(\dim _{\mathbb {C}}M_{D}(\mathbb {C})=D^2\) and \(\dim _{\mathbb {C}}M_{E}(\mathbb {C})=E^2\), so \(D=E\).
Let \(\varphi :M_{D}(\mathbb {C})\to M_{E}(\mathbb {C})\) be a \(\mathbb {C}\)-algebra isomorphism. Then \(D=E\); let \(h\) denote this equality and \(\iota _h:M_{D}(\mathbb {C})\to M_{E}(\mathbb {C})\) the canonical index-relabelling isomorphism. There is \(X\in \mathrm{GL}_E(\mathbb {C})\) with \(\varphi (M)=X\iota _h(M)X^{-1}\) for all \(M\in M_{D}(\mathbb {C})\).
By Theorem 24.3.18, \(D=E\), so \(\iota _h\) is defined. Then \(\varphi \circ \iota _h^{-1}\) is a \(\mathbb {C}\)-algebra automorphism of \(M_{E}(\mathbb {C})\), and Skolem–Noether (Theorem [ 216 , “Skolem–Noether” ] ) gives \(X\in \mathrm{GL}_E(\mathbb {C})\) with \((\varphi \circ \iota _h^{-1})(N)=XNX^{-1}\). Evaluating at \(N=\iota _h(M)\) gives \(\varphi (M)=X\iota _h(M)X^{-1}\).
Suppose the edge insertion correspondence is a \(\mathbb {C}\)-algebra isomorphism between the two full matrix algebras on the chosen bond. Then the two bond dimensions on that edge are equal. If \(h_e:D_A(e)=D_B(e)\) is this equality, and if \(\phi _{h_e}:M_{D_A(e)}(\mathbb {C})\to M_{D_B(e)}(\mathbb {C})\) is the induced algebra isomorphism, then, for an invertible edge matrix \(Z_e\), the insertion correspondence is \(Y=Z_e\phi _{h_e}(X)Z_e^{-1}\). This is the finite-dimensional matrix-algebra step in [ 220 , Section 3 ] .
Apply Theorem 24.3.19 to the full matrix algebras determined by the two edge bond spaces.
Let \(A\) and \(B\) be vertex-injective PEPS tensors with the same PEPS state. Suppose the corresponding virtual bond dimensions are equal and every virtual bond of \(A\) has positive dimension. Then there is a family \(X_e\in \mathrm{GL}(D_A(e))\) such that, for every edge \(e\), there is a \(\mathbb {C}\)-algebra isomorphism \(\Phi _e:M_{D_A(e)}(\mathbb {C})\to M_{D_B(e)}(\mathbb {C})\) satisfying \(C_A(e,\sigma ,M)=C_B(e,\sigma ,\Phi _e(M))\) for every physical configuration \(\sigma \) and matrix \(M\). Writing \(\phi _{h_e}:M_{D_A(e)}(\mathbb {C})\to M_{D_B(e)}(\mathbb {C})\) for the algebra isomorphism induced by the dimension equality on \(e\), one has \(\Phi _e(M)=\phi _{h_e}(X_eMX_e^{-1})\).
Vertex injectivity and positivity give edge-blocked three-site injectivity for \(A\) and \(B\) at each edge. Theorem 24.3.17 gives the algebra isomorphism \(\Phi _e\) preserving inserted coefficients. Theorem 24.3.20 realizes \(\Phi _e\) by conjugation, and the bond-dimension equality transports the conjugating matrix to the \(A\)-side bond.
Let \(A\) and \(B\) be normal PEPS on the open \(W\times H\) square lattice that satisfy the rectangular-injectivity hypotheses with union closure, have positive physical dimension \(d{\gt}0\), have equal and everywhere-positive virtual bond dimensions, and define the same PEPS state. Fix a translated horizontal interior frame with two rows and two columns of margin, that is \(2\le x_0\), \(2\le y_0\), \(x_0+8\le W\), and \(y_0+8\le H\), and let \(e\) be the distinguished horizontal edge of that frame. Then the bond dimensions agree on \(e\), \(D_A(e)=D_B(e)\), and there are an invertible edge matrix \(Z\in \mathrm{GL}(D_B(e))\) and a forward map \(\mathrm{fwd}\) given by the conjugation \(\mathrm{fwd}(M)=Z\phi _{h_e}(M)Z^{-1}\), where \(\phi _{h_e}:M_{D_A(e)}(\mathbb {C})\to M_{D_B(e)}(\mathbb {C})\) is the reindexing induced by the bond-dimension equality on \(e\). No single-vertex injectivity is used; the only injectivity hypotheses are the blocked-region injectivities of the interior blocking data and the red and host injectivities of \(B\).
The translated horizontal frame supplies, for both \(A\) and \(B\), the one-edge interior blocking datum. Because the red, blue, and complementary blocks are coordinate regions, independent of the tensor, the two data share them: \(R_A=R_B\), \(B_A=B_B\), and \(C_A=C_B\). The distinguished edge \(e\) is the unique crossing edge of the red and blue blocks. Applying the per-edge gauge construction from a one-edge blocking datum to the two blocking data yields the bond-dimension equality on \(e\) and the conjugating gauge \(Z\).
The coordinate-swap counterpart of Theorem 24.3.22. Under the same hypotheses on \(A\) and \(B\), for a translated vertical interior frame with two rows and two columns of margin, that is \(2\le x_0\), \(2\le y_0\), \(x_0+8\le W\), and \(y_0+8\le H\), with distinguished vertical edge \(e\), the bond dimensions agree on \(e\), \(D_A(e)=D_B(e)\), and there are an invertible edge matrix \(Z\in \mathrm{GL}(D_B(e))\) and a forward map \(\mathrm{fwd}\) given by the conjugation \(\mathrm{fwd}(M)=Z\phi _{h_e}(M)Z^{-1}\), with \(\phi _{h_e}:M_{D_A(e)}(\mathbb {C})\to M_{D_B(e)}(\mathbb {C})\) the reindexing induced by the bond-dimension equality on \(e\).
Interchange the two lattice coordinates. This graph isomorphism sends the vertical translated frame to the horizontal translated frame, transposes the rectangular injectivity hypotheses, and sends the distinguished vertical edge to the distinguished horizontal edge. Apply Theorem 24.3.22 to the transported tensors. Transporting its bond-dimension equality and conjugating gauge back along the inverse coordinate swap gives the required equality on \(e\) and the matrix \(Z\).
Fix \(A\), \(B\), a bond-dimension equality, and a vertex \(v\). Let \(\mathcal T^A_v\) be the local tensor map of \(A\), let \(L^A_v\) be the chosen left inverse of \(\mathcal T^A_v\), and let \(\Pi ^A_v=\mathcal T^A_vL^A_v\). The factorized local gauge datum consists of the following two identities for local virtual configurations \(\eta ,\eta '\):
with \(X_e\in \mathrm{GL}(D_A(e))\) on each incident edge. This is the local output required from the blocked-middle reduction in [ 220 , Section 3 ] .
The blocked-middle local gauge formula at \(v\) is the assertion that there are matrices \(X_e\in \mathrm{GL}(D_A(e))\), one on each incident edge, such that for all local virtual configurations \(\eta \) and physical indices \(\sigma \),
If the blocked-middle local gauge formula holds at \(v\) with matrices \(X_e\), then the factorized local gauge datum holds at \(v\) with the same matrices.
For fixed \(\eta \), set \(c_\eta (\eta ')=\prod _{e\ni v}X_e(\eta _e,\eta '_e)\). The displayed blocked-middle formula is precisely \(B_v(\eta ,-)=\mathcal T^A_vc_\eta \). Hence
Suppose that the edge-centred three-site reduction supplies invertible matrices \(X_e\) on the incident edges of \(v\) such that, for all local virtual configurations \(\eta \) and physical indices \(\sigma \),
Then the same family \(X_e\) is a local gauge at \(v\):
By Theorem 24.3.26, \(L^A_vB_v(\eta ,-)(\eta ')=\prod _{e\ni v}X_e(\eta _e,\eta '_e)\). Since \(\Pi ^A_vB_v(\eta ,-)=B_v(\eta ,-)\) and \(\Pi ^A_v=\mathcal T^A_vL^A_v\),
Given edge gauges \(X_e\), set \(\widetilde B=B^X\). Then \(D_{\widetilde B}=D_B\) and, for every vertex \(v\),
where \(M_{ie}=X_e\) or \(M_{ie}=(X_e^{-1})^t\) according to the orientation of the endpoint \(ie\). After this absorption, arbitrary insertions of the same matrix on the same edge are compared in the first PEPS and the modified second PEPS.
For tensor families \(A,\widetilde B\), the post-absorption comparison holds when \(h:D_A=D_{\widetilde B}\) and the following equality holds. For each edge \(e\), write \(\phi _{h_e}:M_{D_A(e)}(\mathbb {C}) \to M_{D_{\widetilde B}(e)}(\mathbb {C})\) for the matrix-algebra transport induced by \(h_e:D_A(e)=D_{\widetilde B}(e)\). Then, for every matrix \(X\in M_{D_A(e)}(\mathbb {C})\) and every physical configuration \(\sigma \), \(C_A(e,X;\sigma ) =C_{\widetilde B}(e,\phi _{h_e}(X);\sigma )\).
Let \(A\) and \(B\) be vertex-injective PEPS with the same state, assume every bond dimension is positive, and assume the bond-dimension equality \(h:D_A=D_B\). After the edge gauges have been absorbed into the second tensor family, there are gauges \(Z_e\) and \(\widetilde B=B^Z\) such that \(D_{\widetilde B}=D_A\) and, for every edge \(e\), write \(\phi _{h_e}:M_{D_A(e)}(\mathbb {C})\to M_{D_{\widetilde B}(e)}(\mathbb {C})\) for the matrix-algebra transport induced by the corresponding equality \(h_e:D_A(e)=D_{\widetilde B}(e)\). Then, for every matrix \(X\in M_{D_A(e)}(\mathbb {C})\) and every physical configuration \(\sigma \), \(C_A(e,X;\sigma ) =C_{\widetilde B}(e,\phi _{h_e}(X);\sigma )\). On the five-site graph used in the proof, this equality reads
 \( = \)

as in [ 220 , Section 3, lines 1037–1065 ] . The positive-bond hypothesis is the source’s standing assumption that injective PEPS have nonzero virtual bond spaces; it is needed because the edge gauges come from blocking the PEPS around each edge into a three-site injective chain.
Block the PEPS around each edge into a three-site injective chain and compare the matched matrix insertions: this assigns to every edge an invertible bond matrix \(X_e\) realizing the insertion-algebra transport as conjugation. Absorb the transpose of \(X_e\) into the second tensor family on that edge. The open-edge gauge action then conjugates each inserted matrix by the transpose of the absorbed gauge, while the insertion-algebra transport conjugates by \(X_e\); the two conjugations agree because the absorbed gauge is the transpose of \(X_e\), giving the post-absorption insertion equality.
Under the factorized local gauge hypothesis, the local gauge formula follows. What remains open is to upgrade equality of the edge-blocked coefficients to the blocked-middle formula using the corresponding three-site injective-chain argument. The physical-realization and physical-to-virtual steps in that argument are recorded separately as Theorems 24.3.6 and 24.3.14. After Theorem 24.3.30 supplies the factorized local gauge hypothesis, injectivity on the star neighborhood provides a left inverse that isolates the local edge gauges. Thus there are incident-edge matrices \(X_e\) such that
The factorized local gauge datum already supplies the incident-edge invertible matrices and the factorized local coefficient identity.
Suppose \(A\) and \(B\) are vertex-injective PEPS tensors with the same PEPS state, that the corresponding virtual bond dimensions are equal, that every virtual bond of \(A\) has positive dimension, and that the graph is connected. The connectivity assumption is necessary: on a disconnected graph the per-vertex scalars produced by the reduction below cannot be absorbed into edge gauges, since on the empty graph on two vertices the products of the vertex scalars can agree while no edge gauge relates the two tensors. Choose an edge \(e=(u,v)\) and block all other vertices into one middle tensor. The three resulting tensors form an injective chain, so the one-dimensional injective comparison assigns an invertible matrix to the edge \(e\). Repeating this for every edge and absorbing these matrices into the second tensor family gives the post-absorption insertion equality of [ 220 , Section 3 ] : for every edge and every matrix, inserting that matrix on the edge in the first PEPS gives the same state as inserting it on the same edge in the modified second PEPS. Applying the local extraction at each vertex then gives one edge gauge family whose endpoint actions transform the first tensor family into the second:
Absorbing the edge gauges into the second tensor family gives the post-absorption insertion equality. On each vertex with an incident edge, the one-vertex-versus-complement comparison supplies a nonzero scalar relating the first tensor to the absorbed second tensor. Because the state is nonzero, these per-vertex scalars multiply to one, so on the connected graph a spanning-tree construction realizes their reciprocals as the oriented incidence product of one edge-scalar family. Folding those scalars into the inverse of the absorbed edge gauges produces the global gauge. On a one-vertex graph there are no edges and the gauge is trivial.
The gauge transformation (4) expresses the algebraic content of the edge-gauge construction in [ 220 , Section 3 ] . On an ordered edge \(e=(u,w)\), the actions \(X_e\) at \(u\) and \((X_e^{-1})^\top \) at \(w\) cancel upon contraction. Absorbing these matrices into \(B\) gives \(\widetilde B\), for which every inserted-edge coefficient agrees with the corresponding coefficient of \(A\). Comparing one vertex with its injective complement then yields the local gauge equation. Repeating the argument on every edge produces a single compatible gauge family; the two-injective comparison below shows that the remaining three-leg operator is scalar.
For three virtual leg spaces \(\alpha ,\beta ,\gamma \) and an endomorphism \(Z\) of \(\beta \otimes \gamma \), define the induced endomorphism of \(\alpha \otimes \beta \otimes \gamma \) by acting as the identity on the \(\alpha \) leg and as \(Z\) on the remaining two legs. This is the \(\mathbb {1}_\alpha \otimes Z\) form appearing after the first tensor is inverted in [ 220 , Section 3 ] .
For an endomorphism \(U\) of \(\alpha \otimes \beta \), define the induced endomorphism of \(\alpha \otimes \beta \otimes \gamma \) by acting as \(U\) on the first two legs and as the identity on the \(\gamma \) leg. This is the \(U\otimes \mathbb {1}_\gamma \) form in [ 220 , Section 3 ] .
For an endomorphism \(W\) of \(\alpha \otimes \gamma \), define the induced endomorphism of \(\alpha \otimes \beta \otimes \gamma \) by acting as \(W\) on the outer two legs and as the identity on the middle \(\beta \) leg, with matrix entries \(\delta _{bb'}W_{ac,a'c'}\) for \((a,b,c),(a',b',c')\in \alpha \times \beta \times \gamma \). This is the third residual form in [ 220 , Section 3 ] .
For nonzero virtual leg spaces \(\alpha ,\beta ,\gamma \), let \(Z\in \operatorname{End}(\beta \otimes \gamma )\), \(U\in \operatorname{End}(\alpha \otimes \beta )\), and \(W\in \operatorname{End}(\alpha \otimes \gamma )\) have equal induced three-leg residual forms (Definitions 24.3.34–24.3.36) on \(\alpha \otimes \beta \otimes \gamma \), so that
for all \(a,a'\in \alpha \), \(b,b'\in \beta \), \(c,c'\in \gamma \). Then there exists \(\lambda \in \mathbb {C}\) such that all three residual matrices are scalar:
Local fix (nonzero virtual legs): The scalar reduction requires that each virtual leg space \(\alpha ,\beta ,\gamma \) be nonzero; if any leg space is empty, the compatibility conditions hold vacuously and admit non-scalar solutions (such as \(Z=\operatorname{diag}(1,2)\) when \(\alpha =\varnothing \), \(|\beta |=1\), \(|\gamma |=2\)). This models the nonzero-dimensional virtual bond spaces of [ 220 , Section 3 ] ; documented in [ 67 ] .
Write the common operator as \(T\). The equality \(\delta _{aa'}Z_{bc,b'c'}=U_{ab,a'b'}\delta _{cc'}\) gives \(Z_{bc,b'c'}=0\) whenever \(c\neq c'\) (by taking \(a=a'\)). Hence \(Z\) is diagonal in the \(\gamma \)-index. Similarly, the equality \(\delta _{aa'}Z_{bc,b'c'}=W_{ac,a'c'}\delta _{bb'}\) gives \(Z_{bc,b'c'}=0\) whenever \(b\neq b'\). Thus \(Z_{bc,b'c'}=0\) unless \(b=b'\) and \(c=c'\).
It remains to compare the surviving diagonal entries. From \(\delta _{aa'}Z_{bc,bc}=U_{ab,a'b}\), the value \(Z_{bc,bc}\) is independent of \(c\). From the middle-identity equality it is also independent of \(b\). Therefore \(Z=\lambda \mathbb {1}_{\beta \otimes \gamma }\). Substitution into the compatibility equalities gives \(U=\lambda \mathbb {1}_{\alpha \otimes \beta }\) and \(W=\lambda \mathbb {1}_{\alpha \otimes \gamma }\).
Let a finite family of legs be given, each a nonzero finite index set, with invertible matrices \(M_i\) and \(N_i\) on each leg. If \(\prod _i(M_i)_{p_iq_i}=\prod _i(N_i)_{p_iq_i}\) for every configuration pair \((p,q)\), then there are nonzero scalars \(c_i\) with \(M_i=c_iN_i\) for each leg and \(\prod _i c_i=1\).
Each \(N_i\) is invertible, so each of its rows has a nonzero entry; pick a reference configuration \((p^0,q^0)\) on which every \((N_i)_{p^0_iq^0_i}\) is nonzero. The product identity at \((p^0,q^0)\) then makes every \((M_i)_{p^0_iq^0_i}\) nonzero as well. Fix a leg \(i\) and a pair \((a,b)\), and apply the identity to the configuration that agrees with the reference except at leg \(i\), where it takes \((a,b)\). Splitting off leg \(i\) gives \((M_i)_{ab}K_i=(N_i)_{ab}L_i\), where \(K_i,L_i\) are the products of the other legs at the reference, both nonzero. The reference identity at leg \(i\) relates \(K_i\) and \(L_i\), and eliminating them yields \((M_i)_{ab}=c_i(N_i)_{ab}\) with \(c_i=(M_i)_{p^0_iq^0_i}/(N_i)_{p^0_iq^0_i}\), independent of \((a,b)\). Taking the product of the scalars over all legs and using the reference identity gives \(\prod _i c_i=1\).
Let \(A_1,A_2,B_1,B_2\) be tensors with matching external, shared-boundary, and physical index sets. Assume that the two external boundary spaces and the shared-boundary configuration space are nonempty, and that \(A_1\) and \(A_2\) are injective. Suppose that, for every pair of external indices, every pair of shared-boundary configurations, and every pair of physical indices,
Then there exists \(\lambda \in \mathbb {C}^\times \) such that \(A_1=\lambda B_1\) and \(A_2=\lambda ^{-1}B_2\).
Choose external and shared-boundary indices, and use injectivity of \(A_1\) and \(A_2\) to choose physical indices for which the two chosen coefficients are nonzero. The product equality then shows that the corresponding coefficients of \(B_1\) and \(B_2\) are also nonzero. Define \(\lambda = B_2(\eta _2^0,\nu ^0,\sigma _2^0)/ A_2(\eta _2^0,\nu ^0,\sigma _2^0)\). For every \((\eta _1,\mu ,\sigma _1)\), the product identity with \((\eta _2^0,\nu ^0,\sigma _2^0)\) fixed gives
Dividing by \(A_2(\eta _2^0,\nu ^0,\sigma _2^0)\neq 0\) gives \(A_1=\lambda B_1\). Fixing \((\eta _1^0,\mu ^0,\sigma _1^0)\) and substituting \(A_1=\lambda B_1\) into the product identity gives
Dividing by \(B_1(\eta _1^0,\mu ^0,\sigma _1^0)\neq 0\) gives \(A_2=\lambda ^{-1}B_2\).
For indices \(i\) and \(j\), let \(E_{ij}\) denote the matrix whose only nonzero entry is the \((i,j)\) entry, where it is equal to \(1\).
Suppose that the two blocks share a single virtual bond. Then inserting the matrix unit \(E_{\mu ,\nu }\) in that bond extracts the corresponding product of tensor coefficients:
Since there is only one shared bond, the condition that the two shared configurations agree away from the distinguished bond is vacuous, and
The entries of the matrix unit satisfy \((E_{\mu ,\nu })_{i,j} =\delta _{i,\mu (b)}\delta _{j,\nu (b)}\). Thus the only nonzero summand is the one with \((\mu ',\nu ')=(\mu ,\nu )\).
Suppose that the two injective blocks have exactly one shared virtual bond and nonempty external boundary spaces. If all matrix insertions on that bond give equal two-block coefficients for the pairs \((A_1,A_2)\) and \((B_1,B_2)\), then there exists \(\lambda \in \mathbb {C}^\times \) such that \(A_1=\lambda B_1\) and \(A_2=\lambda ^{-1}B_2\).
Insert the matrix unit \(E_{\mu ,\nu }\) and use the coefficient-extraction theorem to obtain the pointwise product equality
for all indices. The pointwise product cancellation theorem gives the reciprocal scalar proportionality.
Let \(A_1,A_2,B_1,B_2\) be injective tensors with the same shared virtual bonds and nonempty external boundary spaces, and assume that there is at least one shared virtual bond. For the set \(\mathcal B\) of shared bonds, a bond \(b\in \mathcal B\), and \(X\in M_{D_b}(\mathbb {C})\), set
Assume, for every \(b,X,\eta _1,\eta _2,\sigma _1,\sigma _2\), that
The following diagram records the three-shared-bond proof subcase used in the source, with the external boundary indices restored:
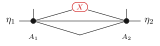 \( = \)
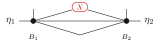
Then there exists \(\lambda \in \mathbb {C}^\times \) such that \(A_1=\lambda B_1\) and \(A_2=\lambda ^{-1}B_2\). This is the blueprint form of the two-injective tensor comparison in [ 220 , Section 3 ] .
Putting \(X=\mathbb {1}_{D_b}\) on every shared bond contracts all bonds diagonally and, by the insertion equality, equates the two fully contracted states. Writing each contracted state as a bipartite operator with the linearly independent Schmidt families supplied by injectivity, the operator-Schmidt uniqueness of [ 220 , Section 3 ] produces an invertible gauge \(g\) on the shared-bond configurations with
Substitute both gauge equations into the insertion equality for the matrix unit \(X=E_{p,q}\) on a single bond \(b\), which frees that bond and contracts the others. Separating the linearly independent families \(B_1\) and \(A_2\) gives, for every bond \(b\), every pair of endpoints \(p,q\), and all configurations \(\nu ,\rho \),
Here \(\rho ^{b\to p}\) replaces the value of \(\rho \) at \(b\) by \(p\). This is the bond-wise form of the residual identity of [ 220 , Section 3 ] , where it is formulated as the compatibility of the three residual gauges \(Z\), \(U\), \(W\) (Theorem 24.3.37). Reading (6) at the two endpoint choices shows that \(g\) vanishes whenever two configurations differ at a bond and that its diagonal value is invariant under changing any single bond. Hence \(g=\lambda \mathbb {1}\) for a scalar \(\lambda \), and invertibility forces \(\lambda \neq 0\).
Reinserting \(g=\lambda \mathbb {1}\) into the two gauge equations gives \(A_1=\lambda B_1\) and \(B_2=\lambda A_2\), that is \(A_2=\lambda ^{-1}B_2\).
24.4 Fundamental Theorem for Injective PEPS
The edge construction is transported from single edges to arbitrary regions. Reading a region \(R\) and its complement \(V\setminus R\) as two-block tensors, when the blocked tensors of \(B\) on \(R\) and \(V\setminus R\) are injective and the bonds are positive, the region-insertion identities determine the boundary conjugation uniquely: two invertible matrices \(Z_1,Z_2\) realizing the same insertion identity satisfy \(Z_1 M Z_1^{-1}=Z_2 M Z_2^{-1}\) for every boundary matrix \(M\). Comparing one vertex \(v\) against its complement then upgrades this to \(A_v=\lambda _v\widetilde B_v\) at each vertex, once the edge gauges have been absorbed into \(\widetilde B\), and the per-edge gauges combine into one gauge relating the two tensors. This establishes the Fundamental Theorem for injective PEPS (Theorem 24.4.1.24), following [ 220 , Theorem 2 ] .
For a finite region \(R\subseteq V\), the blocked tensor of \(R\) may be read as a two-block tensor with a one-point external boundary and shared bonds the edges crossing the boundary of \(R\): \(B_{A,R}(*,\eta ,\sigma )=T_{A,R}^{\eta }(\sigma )\). This is the region block used in the one-block-against-complement step of [ 220 , Section 3 ] .
The edges crossing the boundary of \(R\) are the same edges crossing the boundary of \(V\setminus R\). Thus a boundary configuration \(\eta \) for \(R\) determines the boundary configuration \(\eta ^c\) for the complement by reading the same edge labels through this identification.
For a finite region \(R\subseteq V\), the complement block \(V\setminus R\) is a two-block tensor over the same crossing bonds: \(B_{A,R^c}(*,\eta ,\tau )=T_{A,V\setminus R}^{\eta ^c}(\tau )\). This is the complementary block in the region/complement comparison of [ 220 , Section 3 ] .
If the blocked tensor family of \(V\setminus R\) is injective, then the complement-region two-block tensor is injective: \(\operatorname{inj}(T_{A,V\setminus R})\Longrightarrow \operatorname{inj}(B_{A,R^c})\).
The one-point external boundary does not change the coefficient family, and the complement-boundary identification only reindexes the crossing bonds. More explicitly, if \(\eta _1,\eta _2\) are boundary configurations on \(\partial R\), then \(\eta _1^c=\eta _2^c\Longrightarrow \eta _1=\eta _2\). Thus the coefficients of \(T_{A,V\setminus R}\) and \(B_{A,R^c}\) differ only by an injective relabelling of boundary configurations.
Let \(f\) be an edge crossing the boundary of \(R\), and let \(M\in M_{D_f}(\mathbb {C})\). The region insertion coefficient is
It is the coefficient obtained by inserting \(M\) on the boundary bond \(f\) between the region \(R\) and its complement.
Suppose that the blocked tensor maps of \(A\) on \(R\) and on \(V\setminus R\) are injective, and that every bond dimension of \(A\) is positive. If \(f\in \partial R\) and \(M,M'\in M_{D_A(f)}(\mathbb {C})\) satisfy \(C_A(R,f,M;\sigma ,\tau )=C_A(R,f,M';\sigma ,\tau )\) for every physical configuration \(\sigma \) on \(R\) and \(\tau \) on \(V\setminus R\), then \(M=M'\).
Subtracting the two coefficients gives \(C_A(R,f,M-M';\sigma ,\tau )=0\) for every \(\sigma ,\tau \). Injectivity of the region and complement blocked tensor maps reads off every entry of \(M-M'\) from configurations agreeing away from \(f\), so \(M-M'=0\) and hence \(M=M'\).
Let \(f\) be an edge crossing the boundary of \(R\), and let \(M\in M_{D_f}(\mathbb {C})\). The bond-inserted region insert \(I_{A,R,f,M}\) is the insert on \(R\) defined by
Thus the complement boundary value \(\nu \) is fixed away from \(f\), while the matrix \(M\) couples the two \(f\)-labels. This is the one-bond insertion in the region/complement coefficient of [ 220 , Section 3 ] .
For every physical configuration \(\sigma \) on \(R\) and \(\tau \) on \(V\setminus R\), the deformed state of the bond-inserted region insert is the region insertion coefficient: \(\Psi _{A,R,I_{A,R,f,M}}(\sigma ,\tau ) =C_A(R,f,M;\sigma ,\tau )\).
Expanding the deformed state gives
Substituting the definition of \(I_{A,R,f,M}\) and exchanging the two finite sums gives
For a region \(R\), a physical configuration \(\sigma \) on \(R\), and a physical configuration \(\tau \) on \(V\setminus R\), write \(\omega _{R,\sigma ,\tau }\) for the physical configuration on \(V\) with
Let \(f\) be a boundary edge of \(R\), let \(N\in M_{D_B(f)}(\mathbb {C})\), let \(\sigma \) be a physical configuration on \(R\), and let \(\tau \) be a physical configuration on \(V\setminus R\). Put \(p_B(R)=\prod _{g\notin \partial R}D_B(g)\). Then the region insertion coefficient factors through the edge-inserted coefficient:
Here \(\mathcal O_{R,f}\) is the boundary-edge orientation, equal to the identity if the left endpoint of \(f\) lies in \(R\) and to transpose otherwise.
Let \(\mathcal C_{R,f}(\sigma ,\tau )\) denote the open-edge configurations compatible with the two physical configurations and with the two boundary readings agreeing away from \(f\). For \(\xi \in \mathcal C_{R,f}(\sigma ,\tau )\), let \(\operatorname {Fib}_{R,f}(\xi )\) be the corresponding fibre of agreeing boundary readings. Grouping the expansion of \(C_B(R,f,N;\sigma ,\tau )\) by such an open-edge configuration \(\xi \) gives
Substituting this fibre cardinality gives
The final step is Definition 24.2.9 of the edge-inserted coefficient, with the inserted matrix read in the boundary-edge orientation.
Let \(R\subseteq S\), and suppose that all bond dimensions are positive. For every global physical configuration \(\sigma \),
In particular, the one-bond insertion on \(R\) may be read after extending the corresponding insert to any larger region \(S\).
The preceding theorem and state preservation for corner extension give
The abstract two-block insertion coefficient of the pair \((B_{A,R},B_{A,R^c})\) is the region insertion coefficient:
Expanding the abstract two-block coefficient gives exactly the two boundary sums in the displayed formula for \(C_A(R,f,M;\sigma ,\tau )\).
If a tensor \(B\) is transported along an equality of bond dimensions, then the region insertion coefficient is transported by the induced matrix-algebra identification on the inserted bond: \(C_{B^h}(R,f,N;\sigma ,\tau ) =C_B(R,f,\phi _f(N);\sigma ,\tau )\).
Reindex both boundary-configuration sums by the bond-dimension equivalences. The constraint away from \(f\) and the two blocked-region weights are preserved, while the inserted matrix entry becomes the transported entry \(\phi _f(N)\).
Suppose \(A\) and \(B\) have identified bond dimensions. Write \(B^h\) for the transported tensor, and write \(\phi _f\) for the induced transport on the boundary bond \(f\). If \(C_A(R,f,N;\sigma ,\tau )=C_B(R,f,\phi _f(N);\sigma ,\tau )\) for every boundary edge \(f\), matrix \(N\), and physical configurations \(\sigma ,\tau \), then the two pairs \((B_{A,R},B_{A,R^c})\) and \((B_{B^h,R},B_{B^h,R^c})\) have the same one-bond insertion coefficients after the same bond-dimension transport.
Rewrite the two abstract insertion coefficients as region insertion coefficients and use the bond-dimension transport formula:
Let \(B_1,B_2\) be two blocks joined along a shared bond \(f\). Then inserting a matrix \(X\) while contracting \(B_1\) against \(B_2\) is the same as contracting \(B_2\) against \(B_1\) with the transposed insertion:
Exchange the two boundary-configuration sums. The condition that the two configurations agree away from \(f\) is symmetric, and \((X^T)_{\nu _f,\mu _f}=X_{\mu _f,\nu _f}\).
For a boundary edge \(f\in \partial R\), the region-inserted coefficient can be read by contracting the complement block first:
Here \(C_{A,R^c;R}\) denotes the same one-bond insertion coefficient with the two blocks \(R^c\) and \(R\) interchanged.
Identify \(C_A(R,f,X;\sigma ,\tau )\) with the two-block insertion of \((B_{A,R},B_{A,R^c})\), then apply Theorem 24.4.14.
Assume that \(A\)’s and \(B\)’s components at the in-region endpoint of \(f\) are linearly independent, and that \(D_B(e){\gt}0\) for every edge \(e\). Let \(W\) be the virtual pullback, at the in-region endpoint of \(f\), of the physical operator obtained by inserting \(X^T\) on \(f\). If \(W=\mathcal I_f(P)\) is in incident-matrix form on the boundary leg \(f\), then the transfer matrix read off from \(W\) reinserts to \(W\).
The transfer matrix is defined by reading the incident matrix out of \(W\). Reading \(\mathcal I_f(P)\) gives \(P\), and reinserting \(P\) returns \(W\).
Assume that \(A\) and \(B\) have the same PEPS state, are vertex-injective, and have positive bond dimensions. Let \(v\) be the in-region endpoint of \(f\), and let \(W\) be the virtual pullback, for \(B\) at \(v\), of the physical operator obtained by inserting \(X^T\) on \(f\). Then for every local virtual coefficient \(c\), \(\mathcal T_{B,v}(Wc) =O_{A,R,f}(X^T) \mathcal T_{B,v}(c)\).
The physical endpoint operator preserves the image of \(\mathcal T_{B,v}\). The chosen left inverse defining the virtual pullback therefore realizes the same action after applying \(\mathcal T_{B,v}\).
The out-of-region endpoint of \(f\in \partial R\) is the endpoint outside \(R\). It is the in-region endpoint of the same edge viewed as an edge of \(\partial (V\setminus R)\). The blocked-region map is \(c\longmapsto \sum _{\mu \in \partial R}c_\mu \, T_{A,R}^{\mu }\), and injectivity of the blocked tensor gives a left inverse. In particular, \(L_{A,R}\! \left(T_{A,R}^{\mu }\right)=e_\mu \).
With \(f'\) the boundary edge \(f\) read on \(V\setminus R\), one has
where \(\sigma ^{cc}\) is \(\sigma \) transported across \(V\setminus (V\setminus R)=R\). Consequently the same coefficient is realized through the endpoint of \(f\) lying outside \(R\).
Reindex the two boundary-configuration sums by the boundary-edge equivalence between \(R\) and its complement. The double complement carries the blocked weight of \(V\setminus (V\setminus R)\) back to the blocked weight of \(R\). Applying the usual endpoint realization to \(V\setminus R\) gives the displayed out-of-region endpoint realization.
Assume that \(A\)’s components at the in-region endpoint of \(f\) and at the in-complement-region endpoint of the complementary boundary edge are linearly independent, and that \(A\) and \(B\) define the same PEPS state. Let \(P_R\) and \(P_{R^c}\) be the interior bond products of \(R\) and \(R^c\). Let \(O^{\mathrm{in}}_f(X)\) and \(O^{\mathrm{out}}_f(X)\) be the physical endpoint operators obtained from the two virtual insertions, and let \(\Psi _B(R;\sigma ,\tau )\) and \(\Psi _B(R^c;\tau ,\sigma ^{cc})\) be the corresponding closed \(B\)-state vectors. Then the two endpoint readings of the same inserted coefficient give
With \(\rho ^{R^c}_{X,\sigma }\) and \(\rho ^{R}_{X,\tau }\) denoting the two row functions, one has
Hence the blocked left inverses read off the rows:
The in-region and out-of-region endpoint pins both evaluate to \(C_A(R,f,X;\sigma ,\tau )\), hence they agree. Expanding \(C_A(R,f,X;\sigma ,\tau )\) as a sum over boundary configurations isolates, respectively, the \(R^c\)-blocked and \(R\)-blocked tensor maps; the left inverses then read off the row functions.
The incident-form condition associated with the region resonance asserts that, for every matrix \(X\) inserted on \(f\), the virtual pullback \(W_X\) of the in-region endpoint operator is in incident-matrix form, namely \(\exists Y\colon W_X=\mathcal{I}_f(Y)\).
A region insertion transfer along a boundary edge \(f\in \partial R\) consists of maps \(T_f:M_{D_A(f)}(\mathbb {C})\to M_{D_B(f)}(\mathbb {C})\) and \(S_f:M_{D_B(f)}(\mathbb {C})\to M_{D_A(f)}(\mathbb {C})\). For every inserted matrix and every pair of physical configurations, these maps satisfy
The forward map is required to satisfy \(T_f(XY)=T_f(X)T_f(Y)\) and \(T_f(\mathbb {1})=\mathbb {1}\).
Let \(v\) be the endpoint of \(f\) lying in \(R\). A matrix transfer \(T_f\) is realized on the region if, for every matrix \(X\) inserted on \(A\)’s boundary bond and every local virtual coefficient \(c\) for \(B\) at \(v\),
This is the region version of the physical-to-virtual insertion relation in [ 220 , Section 3, lines 254–582 ] .
If a region matrix transfer is realized in the sense of Definition 24.4.23, then its forward map is multiplicative: \(T_f(XY)=T_f(X)T_f(Y)\). If in addition the two PEPS tensors have the same state and the same bond dimensions, all bond dimensions of \(B\) are positive, and the blocked tensors of \(B\) on \(R\) and its complement are injective, then the identity insertion gives \(T_f(\mathbb {1})=\mathbb {1}\).
For multiplicativity, the physical insertion for \((XY)^T\) is the composite of the physical insertions for \(Y^T\) and \(X^T\). Realizing these insertions on the \(B\)-side gives two incident-matrix actions on the same local tensor image, \(\mathcal{I}_f(T_f(XY)^T) =\mathcal{I}_f((T_f(X)T_f(Y))^T)\). Reading the incident matrix on the boundary leg gives \(T_f(XY)=T_f(X)T_f(Y)\). For the identity, the coefficient \(C_A(R,f,\mathbb {1};\sigma ,\tau )\) is the interior bond product times the state coefficient of \(A\), hence equals \(C_B(R,f,\mathbb {1};\sigma ,\tau )\) by equality of states and bond dimensions. The two blocked-injectivity hypotheses and positivity give injectivity of the \(B\)-side region-inserted coefficient, whence \(T_f(\mathbb {1})=\mathbb {1}\).
Suppose the forward and reverse boundary matrix transfers are realized on the two tensors, the two tensors have the same state and the same bond dimensions, and the region and complement-region blocked maps of \(B\) are injective. Then the maps \(T_f\) and \(S_f\) form a region insertion transfer:
together with \(T_f(XY)=T_f(X)T_f(Y)\) and \(T_f(\mathbb {1})=\mathbb {1}\).
Assume that \(A\) and \(B\) have the same PEPS state, are vertex-injective, have positive bond dimensions, and have injective blocked maps for \(R\) and \(R^c\). If the incident-form condition holds in both directions, then the matrix reading gives maps \(T_f:M_{D_A(f)}(\mathbb {C})\to M_{D_B(f)}(\mathbb {C})\) and \(S_f:M_{D_B(f)}(\mathbb {C})\to M_{D_A(f)}(\mathbb {C})\) realizing all region insertion coefficients. If, in addition, \(D_A(e)=D_B(e)\) for every edge \(e\), then there is an invertible gauge \(Z_f\in \mathrm{GL}(D_B(f))\) such that \(T_f(X)=Z_f\, \iota _f(X)\, Z_f^{-1}\), where \(\iota _f:M_{D_A(f)}(\mathbb {C})\simeq M_{D_B(f)}(\mathbb {C})\) is the identification induced by the equality of bond dimensions.
The incident-form condition supplies incident-matrix form for every inserted matrix. Theorem 24.4.16 gives the realization identities. The forward and reverse realization identities yield the transfer datum, and the one-bond algebra theorem reads it as conjugation by an invertible matrix.
Assume that \(A\) and \(B\) define the same PEPS state, that \(B\) is vertex-injective, that \(D_B(e){\gt}0\) for every edge \(e\), and that \(D_A(e)=D_B(e)\) for every edge \(e\). Assume also that \(A\)’s and \(B\)’s components at the in-region endpoint of \(f\) are linearly independent. Suppose that for every matrix \(X\) on \(A\)’s boundary bond there is a matrix \(Y\) on \(B\)’s boundary bond such that \(C_A(R,f,X;\sigma ,\tau )=C_B(R,f,Y;\sigma ,\tau )\) for all \(\sigma ,\tau \). Then the virtual pullback of \(X\) is in incident-matrix form on \(f\).
Equality of the coefficients gives equality on the closed state vectors, one physical leg at a time. These state-vector coefficients span the local virtual coefficient space, so the equality extends to all coefficients. The virtual pullback is therefore the incident insertion determined by \(Y\).
Assume that \(B\)’s complement blocked tensor map is injective, that \(A\) and \(B\) define the same PEPS state, that \(D_A(e)=D_B(e)\) for every edge \(e\), and that \(A\)’s component at the in-region endpoint of \(f\) is linearly independent. The coefficient \(C_A(R,f,X;\sigma ,\tau )\), as a function of the complement physical configuration \(\tau \), lies in the image of \(B\)’s complement blocked map. Applying the complement blocked left inverse of \(B\) recovers the row obtained by applying \(A\)’s endpoint operator to \(B\)’s region weight vectors.
The identity insertion expresses the closed state vector as a contraction of the region and complement blocked weights. Substituting the endpoint operator into this expression gives the complement-blocked factorization, and the left inverse reads off the corresponding row.
Assume that \(B\)’s region and complement blocked tensor maps are injective, that \(A\)’s components at the in-region endpoint of \(f\) and at the in-complement-region endpoint of the complementary boundary edge are linearly independent, that \(A\) and \(B\) define the same PEPS state, and that \(D_A(e)=D_B(e)\) for every edge \(e\). For fixed \(X\) and \(\sigma \), define the row
where \(\widetilde{\nu }\) is the \(R\)-boundary configuration corresponding to the \(R^c\)-boundary configuration \(\nu \), and \(v_f\) is the endpoint of \(f\) in \(R\). The first tensor’s inserted coefficient can be written as a double contraction of the second tensor’s region and complement blocked weights:
If \(K_X\) has the incident form
then \(C_A(R,f,X;\sigma ,\tau )=C_B(R,f,Y;\sigma ,\tau )\).
First factor \(C_A\) through \(B\)’s complement block, then through \(B\)’s region block. The two left inverses define the coefficient \(K_X\). Substituting (12) into the double contraction gives the defining double sum for \(C_B(R,f,Y;\sigma ,\tau )\).
Under the hypotheses of Theorem 24.4.29, assume in addition that \(A\) and \(B\) are vertex-injective, that \(D_A(e){\gt}0\) and \(D_B(e){\gt}0\) for every edge \(e\), and that \(B\)’s component at the in-region endpoint of \(f\) is linearly independent. If the virtual pullback \(W_X\) is in incident-matrix form \(W_X=\mathcal{I}_f(Y^T)\), then the transfer coefficient \(K_X\) has the incident form determined by \(Y\):
The column of \(K_X\) at fixed \(\nu \) is the region blocked left inverse of the row \(v_X^\sigma \). If \(W_X=\mathcal{I}_f(Y^T)\), this row is precisely the incident-matrix sum of \(Y\) against the region blocked weights. The left inverse sends each blocked weight to the corresponding standard boundary configuration, giving the stated formula.
Suppose that every matrix \(X\in M_{D_A(f)}(\mathbb {C})\) has a matrix \(Y\in M_{D_B(f)}(\mathbb {C})\) with matching region-inserted coefficients, \(C_A(R,f,X;\sigma ,\tau )=C_B(R,f,Y;\sigma ,\tau )\). Choosing one such \(Y\) for each \(X\) defines a forward coefficient transfer \(T_f:M_{D_A(f)}(\mathbb {C})\to M_{D_B(f)}(\mathbb {C})\).
For every inserted matrix \(X\) and every pair of physical configurations, the chosen coefficient transfer satisfies \(C_A(R,f,X;\sigma ,\tau ) =C_B(R,f,T_f(X);\sigma ,\tau )\). If the tensors have the same state and the same bond dimensions, all \(B\)-bond dimensions are positive, and the region and complement-region blocked maps of \(B\) are injective, then \(T_f(\mathbb {1})=\mathbb {1}\).
The coefficient equality is the defining property of the chosen transfer. For \(X=\mathbb {1}\), both region-inserted coefficients are the corresponding interior bond products times the common PEPS state coefficient, so \(C_A(R,f,\mathbb {1};\sigma ,\tau )=C_B(R,f,\mathbb {1};\sigma ,\tau )\). The two blocked-map injectivity hypotheses and positivity of the \(B\)-bond dimensions make the \(B\)-side region-inserted coefficient injective. Hence the chosen matrix \(T_f(\mathbb {1})\) is equal to \(\mathbb {1}\).
Suppose coefficient transfers exist in both directions:
Assume also that the two tensors have the same state and the same bond dimensions, all \(B\)-bond dimensions are positive, and the region and complement-region blocked maps of \(B\) are injective. If the forward choice is multiplicative, \(T_f(XY)=T_f(X)T_f(Y)\), then \(T_f\) and \(S_f\) form a region insertion transfer.
Assume coefficient transfers exist in both directions, the forward transfer is multiplicative, the two tensors have the same state and the same bond dimensions, all bond dimensions are positive, and the region and complement-region blocked maps for both tensors are injective. Then there is an invertible boundary gauge \(Z_f\) such that, for every \(X\in M_{D_A(f)}(\mathbb {C})\), one has \(T_f(X)=Z_f\, \iota _f(X)\, Z_f^{-1}\), where \(\iota _f:M_{D_A(f)}(\mathbb {C})\simeq M_{D_B(f)}(\mathbb {C})\) is the identification induced by the equality of bond dimensions.
The coefficient transfers form a region insertion transfer by Definition 24.4.33. The insertion-transfer algebra isomorphism gives an algebra equivalence between the two boundary matrix algebras, and the Skolem–Noether theorem for matrix algebras writes this equivalence as conjugation by an invertible matrix.
Assume that the blocked tensors of \(B\) on \(R\) and \(R^c\) are injective and that all virtual bonds of \(B\) have positive dimension. Let \(T_1,T_2:M_{D_A(f)}(\mathbb {C})\to M_{D_B(f)}(\mathbb {C})\) be two maps. For \(i=1,2\), suppose \(T_i\) satisfies \(C_A(R,f,M;\sigma ,\tau ) =C_B(R,f,T_i(M);\sigma ,\tau )\) for every inserted matrix and every pair of physical configurations. Then \(T_1(M)=T_2(M)\) for every \(M\).
For every pair of physical configurations, the two coefficient identities give the dense equality chain
Injectivity of the region and complement blocked tensors, together with positivity of all virtual bonds of \(B\), gives
Assume that the blocked tensors of \(B\) on \(R\) and \(R^c\) are injective and that all virtual bonds of \(B\) have positive dimension. Suppose that the equality \(D_A(f)=D_B(f)\) fixes the canonical identification \(\iota :M_{D_A(f)}(\mathbb {C})\simeq M_{D_B(f)}(\mathbb {C})\). For \(i=1,2\), suppose that the invertible matrix \(Z_i\in \mathrm{GL}(D_B(f))\) realizes the region-insertion identity
Then the two conjugations agree on every boundary matrix: \(Z_1\, \iota (M)\, Z_1^{-1}=Z_2\, \iota (M)\, Z_2^{-1}\).
For \(i=1,2\), define the transfer map \(T_i(M):=Z_i\, \iota (M)\, Z_i^{-1}\). Its coefficient identity is \(C_A(R,f,M;\sigma ,\tau )=C_B(R,f,T_i(M);\sigma ,\tau )\). Theorem 24.4.35 gives \(T_1(M)=T_2(M)\). Substituting the definitions of \(T_1\) and \(T_2\) yields \(Z_1\, \iota (M)\, Z_1^{-1}=Z_2\, \iota (M)\, Z_2^{-1}\).
Let \(v\notin R\). At a fixed global virtual configuration \(\zeta \) and a physical configuration \(\sigma \) on \(R\cup \{ v\} \), the product of the local tensors over the vertices of \(R\cup \{ v\} \) factors as the local tensor at the inserted site \(v\) times the product over the vertices of \(R\):
The inserted site \(v\) is isolated from the product over \(R\cup \{ v\} \) by splitting off a single factor, and the residual product over the remaining vertices is reindexed through the bijection between the vertices of \(R\) and the non-\(v\) vertices of \(R\cup \{ v\} \).
Let \(v\notin R\). The blocked-region weight of \(R\cup \{ v\} \) is the constrained sum, over global virtual configurations \(\zeta \) whose crossing-edge label on \(R\cup \{ v\} \) is \(\mu \), of the inserted-site tensor times the vertex product over \(R\):
Each summand of the blocked-region weight is the vertex product over \(R\cup \{ v\} \), which factors by Theorem 24.4.37.
Let \(v\notin R\). A crossing edge of \(R\) whose two endpoints both differ from \(v\) is also a crossing edge of \(R\cup \{ v\} \).
A crossing edge of \(R\) has exactly one endpoint inside \(R\). Adjoining \(v\) to \(R\) leaves both endpoints on the same side as before, since neither endpoint is \(v\), so the edge still crosses the boundary of \(R\cup \{ v\} \).
Let \(v\notin R\). Given a crossing-edge label \(\mu \) for \(R\cup \{ v\} \) and a local virtual configuration \(\eta \) on the edges incident to \(v\), the crossing-edge label \(\beta (\mu ,\eta )\) of \(R\) is read off these two configurations: a crossing edge of \(R\) incident to \(v\) has become internal to \(R\cup \{ v\} \), so its label is taken from \(\eta \); a crossing edge of \(R\) not incident to \(v\) is also a crossing edge of \(R\cup \{ v\} \), so its label is taken from \(\mu \).
Let \(v\notin R\). If a global virtual configuration \(\zeta \) restricts to \(\mu \) on the crossing edges of \(R\cup \{ v\} \) and to \(\eta \) on the edges incident to \(v\), then the crossing-edge label of \(R\) read from \(\zeta \) is exactly \(\beta (\mu ,\eta )\) of Definition 24.4.40.
The two labels are compared edge by edge. On a crossing edge of \(R\) incident to \(v\) both sides read \(\zeta \) on an edge incident to \(v\), which is \(\eta \). On a crossing edge of \(R\) not incident to \(v\) both sides read \(\zeta \) on a crossing edge of \(R\cup \{ v\} \), which is \(\mu \).
Let \(X\) be an edge-gauge family, write \(B^X\) for the gauged tensor, and let \(f\) be a crossing edge of \(R\). Inserting \(M\) on \(f\) between the region and its complement in \(B^X\) equals inserting, in \(B\), the matrix obtained by orienting \(M\) to the boundary-edge convention, conjugating by the transpose of the endpoint gauge \(X_f\), and orienting back:
where \(\mathcal O_{R,f}\) is the boundary-edge orientation. This is the region-granularity analog of Theorem 24.3.28.
By Theorem 24.4.9 the region/complement contraction is the single-bond cut at \(f\) up to the interior-bond multiplicity \(p_B(R)=\prod _{g\notin \partial R}D_B(g)\), which is unchanged by a gauge. At the edge granularity every interior edge and every crossing edge other than \(f\) cancels its gauge pairwise, while on \(f\) the endpoint gauges conjugate the oriented matrix \(N=\mathcal O_{R,f}(M)\) by the transpose of \(X_f\) and its inverse:
Transporting this back through Theorem 24.4.9 on \(B\), and using that the boundary-edge orientation is an involution (\(\mathcal O_{R,f}\circ \mathcal O_{R,f}=\operatorname{id}\)), gives the displayed equality.
24.4.1 From the conjugation identity to the absorbed equality
At a region \(R\) with boundary edge \(f\), the per-edge gauge identity takes the conjugation form
where \(Z\) is the invertible bond matrix on \(f\) and \(\phi _{h_f}\) is the matrix-algebra transport induced by \(h_f:D_A(f)=D_B(f)\). The region comparison of [ 220 , Section 3 ] instead consumes the absorbed form: the gauge is absorbed into the second tensor, and the same matrix \(\phi _{h_f}(M)\) is inserted on both sides.
Let \(f\) be a boundary edge of \(R\) and let \(Z\) be an invertible matrix on the bond space of \(f\). The orientation-adapted absorbing gauge is
It is the absorbing matrix on \(f\) for which the gauge action on the region coefficient reproduces the conjugation \(Z\, (\cdot )\, Z^{-1}\).
With \(X_f\) the orientation-adapted absorbing gauge of \(Z\) and \(\mathcal O_{R,f}\) the boundary-edge orientation, for every matrix \(N\) on the bond space of \(f\),
The conjugation by \(X_f^{\mathsf T}\cdot (\cdot )\cdot (X_f^{-1})^{\mathsf T}\) carried by the region gauge action thus equals \(Z\, (\cdot )\, Z^{-1}\).
When the left endpoint of \(f\) lies in \(R\), the orientation is the identity and \(X_f=Z^{\mathsf T}\), so \(X_f^{\mathsf T}=Z\) and \((X_f^{-1})^{\mathsf T}=Z^{-1}\). Otherwise the orientation is transpose and \(X_f=Z^{-1}\), so \(X_f^{\mathsf T}=(Z^{-1})^{\mathsf T}\) and \((X_f^{-1})^{\mathsf T}=Z^{\mathsf T}\), giving
Applying the outer transpose orientation gives \(\mathcal O_{R,f}((Z\, N\, Z^{-1})^{\mathsf T})=Z\, N\, Z^{-1}\). Both cases give \(Z\, N\, Z^{-1}\).
Let \(R\) be a region with boundary edge \(f\) and assume the bond-dimension equality \(h:D_A=D_B\). Suppose the per-edge gauge \(Z\) realizes the conjugation-form region-insertion identity at \(f\): for every matrix \(M\) on the bond space of \(f\) and all physical configurations \(\sigma \) on \(R\) and \(\tau \) on \(V\setminus R\),
Let \(X\) be an edge-gauge family whose value on \(f\) is the orientation-adapted absorbing gauge \(X_f\) of \(Z\). Then \(A\) inserting \(M\) matches the absorbed tensor \(B^X\) inserting the same transported matrix:
This is the region analog of Theorem 24.3.30: the conjugation-form coefficient identity becomes the absorbed plain equality.
By Theorem 24.4.42 the region gauge action conjugates the inserted matrix by \(X_f^{\mathsf T}\cdot \mathcal O_{R,f}(\cdot )\cdot (X_f^{-1})^{\mathsf T}\) and cancels every interior gauge of the region and of its complement, so the right-hand coefficient over \(B^X\) equals the coefficient over \(B\) with the transported matrix conjugated by that gauge. Substituting the conjugation hypothesis on the left and the matrix reconciliation Theorem 24.4.1.2 matches the two conjugation forms.
Let \(R\) be a region with boundary edge \(f\), assume the bond-dimension equality \(h:D_A=D_B\) and that every bond dimension of \(A\) is positive, and suppose the absorbed region equality holds: for every matrix \(M\) on the bond space of \(f\) and all physical configurations \(\sigma \) on \(R\) and \(\tau \) on \(V\setminus R\),
Then the edge-level absorbed equality holds at \(f\): for every global physical configuration \(\sigma \) and every matrix \(N\) on the bond space of \(f\),
The edge-level identity no longer mentions the region.
The interior bond multiplicity \(p_A(R)=\prod _{g\notin \partial R}D_A(g)\) is a positive integer, and it is shared by \(A\) and \(B^X\) because the gauge preserves bond dimensions and \(D_A=D_B\). Apply Theorem 24.4.9 with the inserted matrix \(\mathcal O_{R,f}(N)\) and with configurations \((\sigma |_R,\sigma |_{V\setminus R})\). On the left-hand side,
On the right-hand side of the assumed region equality,
The displayed equalities also use \(\mathcal O_{R,f}\circ \mathcal O_{R,f}=\operatorname{id}\), the compatibility of \(\mathcal O_{R,f}\) with transport, and \(\omega _{R,\sigma |_R,\sigma |_{V\setminus R}}=\sigma \). Substituting these two identities into the assumed region equality and cancelling the shared positive multiplicity gives the edge-level identity.
Assume the bond-dimension equality \(h:D_A=D_B\) and suppose the edge-level absorbed equality holds at an edge \(e\): for every global physical configuration \(\sigma \) and every matrix \(N\) on the bond space of \(e\),
Then the region absorbed equality holds at every region \(R\) having \(e\) as a boundary edge: for every matrix \(M\) on the bond space of \(e\) and all physical configurations \(\sigma \) on \(R\) and \(\tau \) on \(V\setminus R\),
Together with the preceding theorem this expresses region-independence: the absorbed plain equality over any comparison region follows from the single edge-level identity at the boundary edge.
Read both region coefficients through the region-to-edge identity Theorem 24.4.9. The interior multiplicities agree because the gauge preserves bond dimensions and \(D_A=D_B\), and the orientation \(\mathcal O_{R,e}\) commutes with the transport. Hence the two sides are \(p_A(R)\) times the edge coefficients
The edge-level hypothesis at \(\omega _{R,\sigma ,\tau }\) equates these coefficients; multiplying by the common factor \(p_A(R)\) gives the region equality.
Let \(\phi :G\simeq G'\) be a graph isomorphism. The blocked weight of the transported tensor \(A^\phi \) over the complement of the image region, read at the image complement boundary configuration and the image complement physical configuration, equals the blocked weight of \(A\) over \(V\setminus R\):
The image of the complement of \(R\) is the complement of the image of \(R\), and after this identification the blocked weight transports along \(\phi \) by the change of summation variables on virtual configurations.
Let \(\phi :G\simeq G'\) be a graph isomorphism and let \(f\) be a crossing edge of \(R\). Two crossing-edge labels of \(R\) agree away from \(f\) if and only if their images under the boundary reindex induced by \(\phi \) agree away from the image of \(f\).
The boundary reindex is a bijection on crossing edges that carries \(f\) to its image, so it carries the crossing edges other than \(f\) bijectively to the crossing edges other than the image of \(f\). Agreement on the former family is therefore equivalent to agreement on the latter.
Let \(\phi :G\simeq G'\) be a graph isomorphism and let \(f\) be a crossing edge of \(R\). The region insertion coefficient of the transported tensor \(A^\phi \) over the image region, with \(M\) inserted on the image of \(f\) and the physical configurations relabelled by \(\phi \), equals the region insertion coefficient of \(A\) over \(R\), with \(M\) carried back to the bond of \(A\) at \(f\):
No endpoint orientation enters: the matrix is inserted between the two single boundary values on the edge.
The two crossing-label sums reindex by the boundary action of \(\phi \), the agreement-away-from-\(f\) constraint is preserved by Theorem 24.4.1.7, the region weight transports along \(\phi \), and the complement weight transports by Theorem 24.4.1.6. The inserted matrix entry is read at the two boundary values, which the bond-dimension identification carries to the corresponding entry of \(\phi ^{*}M\).
If two tensors are equal, then their region insertion coefficients are equal, with the inserted matrix carried across the induced equality of bond dimensions:
This applies to any tensor equality \(A_1=A_2\), including the equality between a translation-invariant tensor and its transported copy.
Substituting the equality of tensors identifies the two coefficients, and the induced equality of bond dimensions is the identity, so the carried matrix is the original one.
Let \(A\) be translation invariant on the discrete torus, let \(f\) be a crossing edge of \(R\), and let \(T_{a,b}\) be a translation. The bond dimension of \(A\) at the translated crossing edge equals its bond dimension at the reference crossing edge: \(D_A(T_{a,b}(f))=D_A(f)\).
Translation carries the reference edge to its image, and translation invariance fixes the tensor under transport, so the bond dimension is unchanged.
Let \(A\) and \(B\) be translation invariant on the discrete torus, and let \(f\) be a crossing edge of \(R\). Suppose a map \(g\) realizes the coefficient identity at the reference edge: \(C_A(R,f,M;\sigma ,\tau )=C_B(R,f,g(M);\sigma ,\tau )\). Then, for every translation \(T_{a,b}\), the same identity holds at the translated crossing edge of the translated region, with the inserted matrix carried between the translated and reference bonds:
where \(\widehat{g}\) applies \(g\) to the reference-bond reindex of \(M'\) and carries the result back to the translated bond.
Translation invariance identifies the transported tensor with the original, so Theorem 24.4.1.8 carries the reference coefficient of \(A\) to the translated edge with no change of tensor; Theorem 24.4.1.9 mediates the literal and transported tensors. Applying the reference identity for \(g\) and transporting back for \(B\) in the same way gives (15), the inserted matrix being carried across the equal bond dimensions of Theorem 24.4.1.10.
Fix a vertex \(v\). The single-vertex tensor \(A_v\) is regarded as a two-block tensor whose shared bonds are the edges incident to \(v\), whose external boundary is a one-point space, and whose physical index is the physical index at \(v\): \(T_v(*,\eta ,\sigma )=A_v(\eta ,\sigma )\).
If \(A\) is vertex-injective, then the single-vertex two-block tensor at every vertex is injective.
Vertex injectivity is linear independence of the coefficient family \(\eta \mapsto A_v(\eta ,-)\). The auxiliary one-point boundary only reindexes this same family, so the two-block injectivity condition is the same linear independence statement.
For a vertex \(v\), the complementary block \(V\setminus \{ v\} \) defines a two-block tensor on the same incident shared bonds. Its coefficient is the contraction of all tensors away from \(v\), with the incident bond indices left open at the complement endpoints: \(T_{v^c}(*,\eta ,\tau )=A_{v^c}(\eta ,\tau )\).
For a vertex \(v\), the edges crossing the boundary of \(V\setminus \{ v\} \) are precisely the edges incident to \(v\). Hence the boundary configurations of \(V\setminus \{ v\} \) identify with the local virtual configurations at \(v\). Similarly, the vertices in \(V\setminus \{ v\} \) identify with the vertices distinct from \(v\), giving the corresponding identification of physical configurations.
Under the preceding identifications, the blocked tensor of \(V\setminus \{ v\} \) is the vertex-complement tensor:
Expanding the blocked contraction as a sum over the virtual configurations of the complement,
where \(\zeta \) runs over the virtual configurations of the complement whose boundary restriction \(\zeta |_{\partial }\) is the prescribed boundary configuration \(\rho \). The boundary identification \(\Psi _v\) turns the crossing-edge constraint \(\zeta |_{\partial }=\rho \) into the prescribed incident-edge labels, and the vertex identification \(\Phi _v\) reindexes the product over the vertices distinct from \(v\); both bijections match the summation sets and their factors termwise.
If \(A\) is vertex-injective and every virtual bond space has positive dimension, then the coefficient family \(\eta \longmapsto (\tau \longmapsto A_{v^c}(\eta ,\tau ))\) of the vertex-complement contraction is linearly independent.
Apply the injectivity theorem for an arbitrary finite region to \(R=V\setminus \{ v\} \). Theorem 24.4.1.16 identifies the resulting blocked tensor with the vertex-complement tensor. Reindexing the boundary family and the physical coordinates by bijections preserves linear independence.
If \(A\) is vertex-injective and every virtual bond space has positive dimension, then the complement two-block tensor at every vertex is injective.
The previous theorem gives linear independence of the coefficient family \(\eta \mapsto A_{v^c}(\eta ,-)\). The two-block tensor only adds a one-point external boundary, so this is the same injectivity condition after the harmless reindexing \((*,\eta )\leftrightarrow \eta \).
Let the shared bond type and the two external boundary spaces be nonempty. After the edge gauges have been absorbed into the second tensor family \(\widetilde B\), block one vertex \(v\) against its complement. Assume that \(A_v,A_{v^c},\widetilde B_v,\widetilde B_{v^c}\) are injective as two-block tensors. The post-absorption insertion equality gives, for every shared bond \(b\), every matrix \(X\in M_{D_b}(\mathbb {C})\), and all external and physical indices,
Then \(\exists \lambda _v\in \mathbb {C}^\times \) such that \(A_v=\lambda _v\widetilde B_v\).
With \(A_1=A_v\), \(A_2=A_{v^c}\), \(B_1=\widetilde B_v\), and \(B_2=\widetilde B_{v^c}\), the post-absorption equality is precisely, for every \(b\), \(X\), \(\eta _v\), \(\eta _{v^c}\), \(\sigma _v\), and \(\sigma _{v^c}\),
Applying Theorem 24.3.43 yields \(\lambda _v\in \mathbb {C}^\times \) such that
giving the desired local proportionality.
The normal-region application in [ 220 , Section 4 ] uses the same scalar comparison after comparing two injective regions \(R\subset S=R\cup \{ v\} \). If the region comparisons give \(A_R=\lambda _R\widetilde B_R\) and \(A_S=\lambda _S\widetilde B_S\), the source-paper comparison is
 \(=\)
 \(\propto \)
 \(=\)
 .
Applying the left inverse supplied by injectivity of the block \(A_R=\lambda _R\widetilde B_R\) gives \(A_v=(\lambda _S/\lambda _R)\widetilde B_v\).
A PEPS tensor \(A\) is injective if it is vertex-injective and every virtual bond space is nonzero, that is, \(D_e{\gt}0\) for every edge \(e\). The first condition is the injectivity of [ 220 , Section 3 ] . The second is the standing convention of that section, which picks reference virtual configurations and full matrix algebras on the bonds. Without it a zero-dimensional bond makes every state coefficient vanish, while vertex injectivity can hold vacuously at its endpoints. The convention is recorded in [ 67 ] .
Suppose that the corresponding virtual edge spaces of \(A\) and \(B\) are already identified and the graph is connected. If \(A\) and \(B\) are injective PEPS tensors and give the same PEPS state, then there are invertible matrices \(X_e\), one for each edge, such that at every vertex the tensor \(B_v\) is obtained from \(A_v\) by the oriented endpoint action of the incident matrices.
Gauge consistency supplies the edge gauges directly, which combine with the identified bond dimensions to yield the gauge equivalence.
Let \(A\) and \(B\) be injective PEPS tensors on the same finite simple graph, and suppose that they represent the same state. Then
for every edge \(e\). This conclusion does not require the graph to be connected. It is the bond-dimension consequence of the virtual-operation algebra isomorphism in [ 220 , lines 279–282 and 571–582 ] .
Fix an edge. Blocking around it gives two injective three-site chains. Their matched insertions on the distinguished bond form an algebra equivalence between \(M_{D_A(e)}(\mathbb {C})\) and \(M_{D_B(e)}(\mathbb {C})\). Equality of the linear dimensions of these full matrix algebras gives \(D_A(e)^2=D_B(e)^2\), hence \(D_A(e)=D_B(e)\).
Let \(A\) and \(B\) be injective PEPS tensors on a finite simple graph, and suppose that the graph is connected. If they give the same PEPS state, then their corresponding virtual edge spaces have the same dimensions and, after identifying these spaces, there are invertible matrices \(X_e\), one for each edge, such that \(B_v\) is obtained from \(A_v\) by the oriented endpoint action of the matrices incident to \(v\).
By Theorem 24.4.1.23, the bond dimensions agree edgewise. With the bond dimensions identified, the conditional form of the theorem applies.
24.5 Union Closure for Normal PEPS
A normal PEPS is injective only after blocking certain regions, so the injective theorem applies once those regions are available. The closure property that makes them available is that, for positive bond dimensions, the union of two injective regions is again injective, \(\operatorname{inj}(A)\wedge \operatorname{inj}(B)\Longrightarrow \operatorname{inj}(A\cup B)\). Writing \(P_0=A\setminus B\), \(P_1=A\cap B\), \(P_2=B\setminus A\), and \(P_3=(A\cup B)^c\), a boundary operator \(X\) attached to \(P_3\) that is annihilated by the contraction over \(A\cup B\) descends through the contraction chain
so the union contraction has trivial kernel. Iterating gives injectivity of every finite union of injective regions.
Let \(V\) be a finite vertex set. For two regions \(A,B\subseteq V\), define the four regions \(A\setminus B\), \(A\cap B\), \(B\setminus A\), and \(V\setminus (A\cup B)\). These are the four regions used in the proof of Lemma 24.5.7. They also form an indexed family over \(\{ 0,1,2,3\} \) in the order \(A\setminus B\), \(A\cap B\), \(B\setminus A\), \(V\setminus (A\cup B)\).
Let \(V\) be a finite vertex set and let \(A,B\subseteq V\). The left-only and overlap regions reconstruct \(A\), the overlap and right-only regions reconstruct \(B\), the three inside regions reconstruct \(A\cup B\), and all four regions reconstruct \(V\). The same identities also hold in the indexed four-region family: pieces \(0\) and \(1\) reconstruct \(A\), pieces \(1\) and \(2\) reconstruct \(B\), and pieces \(0,1,2\) reconstruct \(A\cup B\). These same reconstructions are available as finite unions over the corresponding subfamilies of the indexed four-region family. Piece \(3\) is the complement of \(A\cup B\), equivalently the complement of the three inside indexed pieces, and also \(A^c\cap B^c\). The singleton subfamily \(\{ 3\} \) gives the outside block. Pieces \(2,3\) reconstruct \(A^c\), equivalently the complement of pieces \(0,1\), and pieces \(0,3\) reconstruct \(B^c\), equivalently the complement of pieces \(1,2\), again both as explicit unions and as finite unions over the indexed subfamilies. Conversely, pieces \(0,1\) are the complement of pieces \(2,3\), pieces \(1,2\) are the complement of pieces \(0,3\), and adding all four pieces reconstructs \(V\). Equivalently, each vertex lies in one of the four regions, and the indexed four-region family has union \(V\). In fact, every vertex belongs to exactly one indexed piece.
Check membership of an arbitrary vertex in \(A\) and in \(B\).
In the four-region decomposition, the left-only and right-only parts are disjoint from the overlap and from each other. Each inside part, and hence the union of the three inside regions, is disjoint from the outside region. In indexed form, the pieces forming \(A\) are disjoint from the pieces forming \(A^c\), and the pieces forming \(B\) are disjoint from the pieces forming \(B^c\), both as explicit binary unions and as finite unions over the corresponding selected indexed subfamilies. The indexed four-region family is pairwise disjoint.
Use the standard disjointness identities for set difference and intersection, together with the reconstruction of \(A\cup B\).
Let \(K\), \(E_{012}\), \(E_2\), and \(E_{12}\) be complex vector spaces. A contraction-map family for the union-injectivity lemma in [ 220 , Section 4 ] consists of three linear maps \(\mathcal C_{\{ 0,1,2\} }:K\to E_{012}\), \(\mathcal C_{\{ 2\} }:K\to E_2\), and \(\mathcal C_{\{ 1,2\} }:K\to E_{12}\).
Let \(P_0=A\setminus B\), \(P_1=A\cap B\), \(P_2=B\setminus A\), and \(P_3=(A\cup B)^c\). Let \(K\) be the boundary vector space attached to \(P_3\), and let \(\mathcal C_{\{ 0,1,2\} }:K\to E_{012}\), \(\mathcal C_{\{ 2\} }:K\to E_2\), and \(\mathcal C_{\{ 1,2\} }:K\to E_{12}\) be the three contraction maps in the proof of the union-injectivity lemma in [ 220 , Section 4 ] . If
and \(\mathcal C_{\{ 1,2\} }(X)=0\Longrightarrow X=0\), then \(\ker \mathcal C_{\{ 0,1,2\} }=\{ 0\} \).
For \(X\in K\) with \(\mathcal C_{\{ 0,1,2\} }(X)=0\), apply the three implications in sequence:
Let \(V\) be a finite vertex set. Write \(\operatorname{inj}(R)\) for the assertion that the PEPS tensor blocked to the region \(R\subseteq V\) is injective. For two possibly overlapping regions \(A,B\subseteq V\), \(\operatorname{inj}(A)\wedge \operatorname{inj}(B)\Longrightarrow \operatorname{inj}(A\cup B)\). The union-injectivity proof in [ 220 , Section 4 ] blocks the network into four parts \(A\setminus B\), \(A\cap B\), \(B\setminus A\), and \((A\cup B)^c\), and applies the two available left inverses in sequence:
Taking a boundary tensor \(X\) on \((A\cup B)^c\) with \(\mathcal C_{\{ 0,1,2\} }(X)=0\), injectivity of \(A\) gives \(\mathcal C_{\{ 2\} }(X)=0\); reinserting \(A\cap B\) and applying injectivity of \(B\) then gives \(X=0\):
 \(=0\) \(\xrightarrow {A^{-1}}\)
 \(=0\) \(\xrightarrow {A\cap B}\)
 \(=0\) \(\xrightarrow {B^{-1}}\)
 \(=0\).
Put \(P_0=A\setminus B\), \(P_1=A\cap B\), \(P_2=B\setminus A\), and \(P_3=(A\cup B)^c\). Then \(P_0\cup P_1=A\), \(P_1\cup P_2=B\), and \(P_0\cup P_1\cup P_2=A\cup B\). Let \(\mathcal C_I\) denote contraction of the blocked tensor over the region \(\bigcup _{i\in I}P_i\). To prove injectivity of \(A\cup B\), take a boundary tensor \(X\) on \(P_3\) such that \(\mathcal C_{\{ 0,1,2\} }(X)=0\). Since \(P_0\cup P_1=A\) is injective, its left inverse gives \(\mathcal C_{\{ 0,1,2\} }(X)=0\Longrightarrow \mathcal C_{\{ 2\} }(X)=0\). The remaining two steps are \(\mathcal C_{\{ 2\} }(X)=0\Longrightarrow \mathcal C_{\{ 1,2\} }(X)=0\) and \(\mathcal C_{\{ 1,2\} }(X)=0\Longrightarrow X=0\). The first implication is obtained by contracting with the tensor on \(P_1\), and the second is the left inverse for the injective region \(P_1\cup P_2=B\). Thus \(\ker \mathcal C_{\{ 0,1,2\} }=\{ 0\} \), and therefore \(P_0\cup P_1\cup P_2=A\cup B\) is injective.
Fix an edge \(e\) and a partition of the vertex set into the three edge-centred blocks \(R\), \(B\), \(C\) (red, blue, complementary) of the normal PEPS proof, with the red block carrying one endpoint of \(e\) and the blue block the other. The injectivity of the blue and complementary blocks is part of the edge-centred blocking data; if every virtual bond dimension is positive, then their union \(B\cup C=V\setminus R\) is injective.
This is Lemma 24.5.7 for the edge-centred triple, where the two regions are the blue and complementary blocks and their union is the set complement of the red block. A coefficient family annihilating the blocked weights of \(V\setminus R\) is stripped of the blue block by its left inverse, leaving a complement-coupling combination that vanishes for every blue boundary configuration. The complementary block then carries each coupling coefficient, read as a function of the complementary physical leg, into a combination of its blocked weights whose coefficient at a boundary configuration is the host residual coefficient reconstructed from the blue and complementary boundary data; injectivity of the complementary block forces that coefficient to vanish wherever a global configuration realizes the two boundary labels. Since every host residual is realized once the bond dimensions are positive, the coefficient family is zero.
Let \(S,T\subseteq V\) be two disjoint regions. If the blocked tensors of \(S\) and of \(T\) are each injective and every virtual bond dimension is positive, then the blocked tensor of their union \(S\cup T\) is injective.
This is Lemma 24.5.7 in the case where the two regions are disjoint, so that the overlap \(S\cap T\) is empty and the four-region picture collapses to the three blocks \(S\), \(T\), and the set complement \((S\cup T)^c\). The argument places \(S\) and \(T\) as the blue and complementary blocks of a three-block decomposition whose third block is the set complement of their union, and applies the two-step inverse argument of the edge-centred Lemma 24.5.8 to that decomposition. No injectivity hypothesis on the set complement and no distinguished edge are needed.
Let \(A,B\subseteq V\) be two possibly overlapping regions. If the blocked tensors of \(A\) and of \(B\) are each injective and every virtual bond dimension is positive, then the blocked tensor of their union \(A\cup B\) is injective. This extends Lemma 24.5.7 to arbitrary overlapping regions when all virtual bond dimensions are positive.
Write the four parts \(P_0=A\setminus B\), \(P_1=A\cap B\), \(P_2=B\setminus A\). A coefficient family annihilating the blocked weights of \(A\cup B\) is stripped of \(A\) by its left inverse, leaving the coupling through \(P_2\) vanishing for every \(A\)-boundary configuration. The source then reinserts the overlap \(P_1\) and inverts \(B\). The legs running from \(P_0\) to the outside are the open legs of the final tensor; they stay uncontracted through the reinsertion. Carrying those legs as a separate label, fix it to a reference value and restrict the coefficient family to the matching fiber. The fiber-restricted first strip still vanishes, so reinserting \(P_1\) and inverting \(B\) forces the fiber row to vanish. The union boundary edges partition into the \(B\)-boundary edges and the \(P_0\)-outer edges, so fixing both the reference label and the \(B\)-boundary label of a configuration realizing a host label selects that single host term, forcing the coefficient to vanish at every realizable host label. Surjectivity of the union host boundary, available once the bond dimensions are positive, realizes every label, so the coefficient family is zero.
Let \((R_i)_{i\in s}\) be a nonempty finite family of pairwise-disjoint regions. If the blocked tensor of each \(R_i\) is injective and every virtual bond dimension is positive, then the blocked tensor of their union \(\bigcup _{i\in s} R_i\) is injective.
Induct on the nonempty family. The singleton case is the injectivity of the one block. For the inductive step, the next block is disjoint from the union of the remaining blocks, so Lemma 24.5.9 combines the two injective pieces.
Let \((R_i)_{i\in s}\) be a nonempty finite family of possibly overlapping regions. If the blocked tensor of each \(R_i\) is injective and every virtual bond dimension is positive, then the blocked tensor of their union \(\bigcup _{i\in s} R_i\) is injective. This is the finite iteration of the overlapping union lemma, with no disjointness assumption.
Induct on the nonempty family. The singleton case is the injectivity of the one block. For the inductive step, combine the next block with the union of the remaining blocks by Lemma 24.5.10; no disjointness is needed.
A region-injectivity hypothesis assigns to each finite vertex region the assertion that the tensor obtained by blocking that region is injective. This predicate is used for regions such as \(R\), \(S\), \(T\), and their complements in the normal PEPS proof. The union-closure hypothesis records the conclusion supplied by the source union-of-injective-regions lemma: the union of two injective regions is injective.
The region-injectivity predicate of a fixed PEPS tensor \(A\) sends a finite region \(R\) to the assertion that the blocked-region tensor of \(R\) is injective.
Let \(\widetilde B=\operatorname {Gauge}_X(B)\) be obtained from \(B\) by a gauge family \(X\). For a region \(R\), a boundary configuration \(\mu \), and a physical configuration \(\tau \) on \(R\), the blocked weight of \(\widetilde B\) is
where the sum ranges over global virtual configurations \(\zeta \), and \(G_f^X\) is the surviving gauge on the boundary edge \(f\).
In the contraction defining \(T_{\widetilde B,R}^{\mu }(\tau )\), the two half-edge gauge factors on every edge internal to \(R\) combine as
Thus every interior edge contributes the identity and its gauge cancels. The only remaining factors are the boundary gauges \(G_f^X(\mu _f,\zeta _f)\), giving (16).
With the same notation, set \(K_R^X(\mu ,\nu ):=\prod _{f\in \partial R}G_f^X(\mu _f,\nu _f)\). Then the gauged blocked weight is the original blocked weight multiplied by the boundary-coupling matrix:
This is the gauge absorption of the blocked tensor in [ 220 , Section 4, proof of Theorem 3 ] .
Start from Theorem 24.5.15 and group the global virtual configurations by their boundary label \(\nu \):
Let \(K_R^X(\mu ,\nu )=\prod _{f\in \partial R}G_f^X(\mu _f,\nu _f)\) and \((K_R^X)^{-1}(\nu ,\rho ) =\prod _{f\in \partial R}(G_f^X)^{-1}(\nu _f,\rho _f)\). Then, for boundary configurations \(\mu \) and \(\rho \),
Exchange the finite sum over \(\nu \) with the product over boundary edges:
Since
each factor reduces to the Kronecker symbol at \((\mu _f,\rho _f)\). The product of these one-edge Kronecker symbols is \(\delta _{\mu ,\rho }\).
Let \(\widetilde B=\operatorname {Gauge}_X(B)\). If the blocked tensor family \(\{ T_{B,R}^{\nu }\} _{\nu }\) is linearly independent, then the blocked tensor family \(\{ T_{\widetilde B,R}^{\mu }\} _{\mu }\) is linearly independent. Equivalently, \(\operatorname{inj}(T_{B,R})\Longrightarrow \operatorname{inj}(T_{\widetilde B,R})\).
By (17), \(T_{\widetilde B,R}^{\mu } =\sum _{\nu }K_R^X(\mu ,\nu )\, T_{B,R}^{\nu }\). Suppose \(\sum _\mu c_\mu T_{\widetilde B,R}^{\mu }=0\). Substituting (17) and using the linear independence of \(\{ T_{B,R}^{\nu }\} _{\nu }\) gives \(\sum _{\mu }c_\mu K_R^X(\mu ,\nu )=0\) for every \(\nu \). Contracting this equality with the right inverse of \(K_R^X\) yields, for every \(\rho \),
Thus all coefficients \(c_\rho \) vanish, proving the linear independence of \(\{ T_{\widetilde B,R}^{\mu }\} _{\mu }\).
Let \(A\) be vertex-injective, and assume that every virtual bond dimension is positive. Then every finite region \(R\) has an injective blocked tensor: \(\operatorname{inj}(R)\).
Let \((c_\rho )_\rho \) be a finitely supported coefficient family on the boundary configurations of \(R\), and assume that, for every physical configuration \(\tau \), \(\sum _{\rho } c_\rho \, T_{A,R}^{\rho }(\tau )=0\). The kernel descent removes the vertices of \(R\) one at a time and preserves the vanishing contraction. After all vertices have been removed, the terminal contraction gives \(c_\rho =0\) for every boundary configuration \(\rho \). Hence the family \(\{ T_{A,R}^{\rho }\} _\rho \) is linearly independent, which is \(\operatorname{inj}(R)\).
Let \(A\) be vertex-injective with every bond dimension positive. Then the concrete region-injectivity predicate of \(A\) satisfies union closure: for any two finite regions \(R\) and \(S\), \(\operatorname{inj}(R)\wedge \operatorname{inj}(S)\Longrightarrow \operatorname{inj}(R\cup S)\).
The kernel descent theorem gives \(\operatorname{inj}(Q)\) for every finite region \(Q\). Taking \(Q=R\cup S\) gives \(\operatorname{inj}(R\cup S)\), so the union-closure implication holds independently of the injectivity of \(R\) and \(S\).
Let \(A\) be a PEPS tensor with every bond dimension positive. Then the concrete region-injectivity predicate of \(A\) satisfies union closure: for any two finite regions \(R\) and \(S\), \(\operatorname{inj}(R)\wedge \operatorname{inj}(S)\Longrightarrow \operatorname{inj}(R\cup S)\). Thus injectivity of the two regions implies injectivity of their union; no single-vertex injectivity hypothesis is needed.
The union-closure implication is the overlapping union lemma (Lemma 24.5.10): injectivity of \(R\) and of \(S\), together with the positive bond dimensions, gives injectivity of \(R\cup S\).
Under the union-closure hypothesis for region injectivity, any nonempty finite union of injective finite regions is injective.
Induct on the nonempty finite indexing set. The singleton case is the given injectivity hypothesis, and the induction step is one application of binary union closure.
Under the union-closure hypothesis for region injectivity, if the indexed subfamilies \(\{ 0,1\} \) and \(\{ 1,2\} \) in the four-region decomposition are injective, then the inside subfamily \(\{ 0,1,2\} \) is injective. Equivalently, injectivity of the two source-paper regions \((A\setminus B)\cup (A\cap B)\) and \((A\cap B)\cup (B\setminus A)\) gives injectivity of \((A\setminus B)\cup (A\cap B)\cup (B\setminus A)=A\cup B\).
Rewrite the three selected indexed unions as \(A\), \(B\), and \(A\cup B\), then apply binary union closure.
24.6 Square-Lattice Normal PEPS
On the square lattice, the injective regions are built from \(2\times 3\) and \(3\times 2\) coordinate rectangles. We specify the underlying geometry: the nested regions \(R\subseteq S\) with \(S\setminus R\) a single site, which realize the one-site-different injective regions required at each vertex, together with the local window \(T\) around an edge. The union closure of Section 24.5 builds these regions from injective rectangles, so rectangular injectivity guarantees their injectivity.
For a finite vertex region \(R\subseteq V\), its complement is \(V\setminus R\). Equivalently, a vertex lies in the complement exactly when it does not lie in \(R\).
The finite \(n\times m\) square lattice is represented by pairs of coordinates. The corresponding square-lattice graph has horizontal and vertical nearest-neighbor edges; the two elementary adjacency lemmas record the right-neighbor and upper-neighbor cases used for translated edge blockings, and the corresponding coordinate edges name those two nearest-neighbor edges as elements of the edge set. These named right and upward edges have the expected horizontal and vertical orientations. Every edge of this graph is horizontal or vertical, but not both. Since edges are represented by ordered endpoint pairs, a horizontal edge is oriented from left to right and is exactly the coordinate right edge from its left endpoint; similarly, a vertical edge is oriented from bottom to top and is exactly the coordinate upward edge from its lower endpoint. A coordinate rectangle is a product of a horizontal coordinate set and a vertical coordinate set. The \(2\times 3\) and \(3\times 2\) coordinate-product predicates assert only that these two coordinate sets have cardinalities \(2,3\) and \(3,2\), respectively. Contiguous coordinate rectangles are products of contiguous coordinate intervals, and the contiguous \(2\times 3\) and \(3\times 2\) predicates name the rectangular blocks used in the normal square-lattice theorem. The displayed region \(R\) is the union of a \(2\times 3\) contiguous rectangle with the \(3\times 2\) contiguous rectangle occupying its upper two rows and extending one column to the right. The displayed region \(S\) is the union of two \(2\times 3\) contiguous rectangles shifted by one horizontal coordinate, hence the full \(3\times 3\) square spanned by them. The displayed local-window model for \(T\) is the complement, inside a local \(5\times 6\) coordinate window, of the vertical \(2\times 3\) edge block and the horizontal \(3\times 2\) edge block shown in the source picture. The finite-lattice complementary block is the whole finite square lattice with those two edge blocks removed; this is the block denoted \(A_3\) in the proof of [ 220 , Theorem 3 ] . The source shapes are:
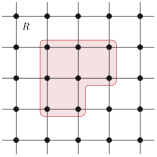 \(\qquad \text{and}\qquad \)
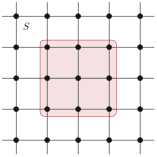
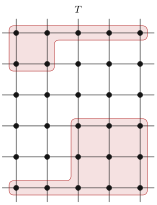
Membership in a coordinate rectangle is coordinatewise membership, the contiguous coordinate interval has the expected coordinate inequalities, membership in a contiguous coordinate rectangle is the conjunction of the four bounding inequalities, and membership in \(R\) is the disjunction of membership in the \(2\times 3\) lower-left piece or in the shifted \(3\times 2\) upper piece. Membership in \(S\) is the disjunction of membership in the left \(2\times 3\) piece or in the horizontally shifted \(2\times 3\) piece. Membership in the local-window \(T\) region is membership in the local \(5\times 6\) window together with nonmembership in the union of the two displayed edge blocks. Bounded contiguous coordinate rectangles of sizes \(2\times 3\) and \(3\times 2\) satisfy, respectively, the predicates for contiguous \(2\times 3\) and contiguous \(3\times 2\) square-lattice rectangles. The cardinality of a coordinate rectangle is the product of the two coordinate cardinalities, and the full coordinate rectangle is the whole finite vertex set.
The coordinate-rectangle statements follow from membership and cardinality identities for Cartesian products of finite coordinate sets. The contiguous-rectangle statement then unfolds the two coordinate intervals. The membership statements for \(R\), \(S\), and the two edge blocks removed from \(T\) additionally unfold membership in a union of two such rectangles, while membership in \(T\) also unfolds the set difference from the local \(5\times 6\) window. The shape predicates follow by using the displayed lower-left corners as witnesses.
If the displayed \(3\times 3\) window containing \(R\) and \(S\) lies in the finite square lattice, then \(R\) is the union of a contiguous \(2\times 3\) rectangle and a contiguous \(3\times 2\) rectangle, while \(S\) is the union of two contiguous \(2\times 3\) rectangles.
This is the defining description of \(R\) and \(S\), together with the coordinate bounds which make the displayed rectangles contiguous \(2\times 3\) and \(3\times 2\) rectangles.
If the two edge blocks cut out of the displayed \(T\)-region lie in the finite square lattice, then they are respectively a contiguous \(2\times 3\) rectangle and a contiguous \(3\times 2\) rectangle.
This is the defining description of the two removed edge blocks, together with the coordinate bounds which make them valid contiguous rectangles.
The two edge blocks removed from the displayed local \(T\)-region lie inside the local \(5\times 6\) coordinate window. They are disjoint from each other and from this local \(T\) region, and their union with it is exactly that local window.
This follows by unfolding the definition of \(T\) as the set-theoretic complement of the two displayed edge blocks inside the local window.
The finite-lattice complementary block around the edge is disjoint from the two displayed edge blocks, and its union with them is the full finite square lattice. The local-window \(T\) region is contained in this finite-lattice complementary block.
This is the set-theoretic complement of the two displayed edge blocks in the full finite square lattice. The containment of the local-window \(T\) region follows because its points also avoid the two removed edge blocks.
A rectangular cover of a square-lattice region is a nonempty finite family of regions whose union is exactly the given region, and each member is a contiguous \(2\times 3\) or \(3\times 2\) rectangle. The two cases used in the proof would be a cover of the local displayed \(T\)-region and a cover of the finite-lattice complementary block \(A_3\). The panel below illustrates the two permitted shapes of a cover member.
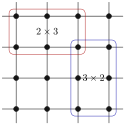
The present origin-based local-window model for the displayed \(T\)-region admits no nonempty finite cover by contained contiguous \(2\times 3\) and \(3\times 2\) rectangles whenever the ambient lattice contains the \(5\times 6\) window. The origin-based rotated local-window model used for vertical edges has the analogous obstruction whenever the ambient lattice contains the \(6\times 5\) window. The normalized \(5\times 6\) and \(6\times 5\) cases are recorded as corollaries. The present origin-based horizontal edge-complement model has the analogous obstruction whenever the ambient lattice contains the \(5\times 7\) frame; the normalized \(5\times 7\) case is again recorded as a corollary. The present origin-based vertical edge-complement model has the corresponding obstruction whenever the ambient lattice contains the \(7\times 5\) frame; the normalized \(7\times 5\) case is recorded as a corollary.
The lower-left point of the local window belongs to the present \(T\) model. Any contiguous \(2\times 3\) rectangle containing it also contains a point of the removed vertical edge block, while any contiguous \(3\times 2\) rectangle containing it also contains a point of the removed horizontal edge block. The rotated statement is the same coordinate argument with the two shapes interchanged. The horizontal edge-complement statement uses the same lower-left point, and so does the normalized vertical edge-complement statement. These cases are all instances of the same point-forcing obstruction to an exact rectangular cover.
If a square-lattice region has a nonempty finite cover by contiguous \(2\times 3\) and \(3\times 2\) rectangles, then rectangular injectivity and finite union closure imply that the region is injective.
Apply rectangular injectivity to every rectangle in the cover, then apply finite union closure to the nonempty family.
For the displayed regions \(R\) and \(S\) with the same lower-left corner, \(R\) is contained in \(S\). The difference \(S\setminus R\) is exactly the lower-right site of the \(3\times 3\) square: in coordinates, the site one obtains by shifting two steps horizontally and zero steps vertically from the lower-left corner.
Expand the two displayed unions. The only point of the second \(2\times 3\) piece of \(S\) which is not already in the union defining \(R\) is its lower-right point.
In the square-lattice normal theorem, every \(2\times 3\) and \(3\times 2\) rectangular region is assumed injective. The corresponding abstract hypotheses specify which finite regions have these two shapes and assert injectivity for all of them. In the coordinate square-lattice specialization, these two families are the contiguous coordinate \(2\times 3\) and \(3\times 2\) rectangles.
A PEPS tensor on the open square lattice is normal with injective rectangles when its family of injective regions satisfies the coordinate rectangular injectivity hypotheses and every virtual bond space is nonzero. This is the hypothesis on each tensor in [ 220 , Theorem 3 ] , read on the open lattice. The nonzero bond spaces are the standing convention of that section; region injectivity does not imply them, and the convention is recorded in [ 67 ] .
The coordinate square-lattice rectangular injectivity hypotheses determine abstract rectangular injectivity hypotheses, with the two abstract rectangular families taken to be the contiguous coordinate \(2\times 3\) and \(3\times 2\) rectangles.
This is the direct specialization of the abstract rectangular families to the two contiguous coordinate-rectangle predicates.
Under the coordinate square-lattice rectangular injectivity hypotheses, every bounded contiguous \(2\times 3\) rectangle and every bounded contiguous \(3\times 2\) rectangle is injective.
This is the defining rectangular injectivity hypothesis applied to the coordinate witnesses for the two rectangle shapes.
For the displayed local \(T\)-region inside its \(5\times 6\) coordinate window, if the smaller edge-block bounds \(x_0 + 5 \leq n\) and \(y_0 + 5 \leq m\) hold in the finite \(n\times m\) square lattice, then the coordinate square-lattice rectangular injectivity hypotheses imply that the vertical \(2\times 3\) block and horizontal \(3\times 2\) block removed from the window are injective. If, in addition, region injectivity is closed under unions, then the union of these two removed edge blocks is injective.
Apply the rectangular injectivity hypotheses to the already identified contiguous rectangle shapes of the two edge blocks. The final assertion is one application of union closure to these two injective blocks.
If the displayed local \(T\)-region has a nonempty finite cover by contiguous \(2\times 3\) and \(3\times 2\) rectangles, then rectangular injectivity and finite union closure imply that \(T\) is injective. The rotated vertical local \(T\)-region has the same conditional injectivity criterion.
Apply rectangular injectivity to every rectangle in the cover, then apply finite union closure to the nonempty family.
If the finite-lattice complementary block \(A_3\) has a nonempty finite cover by contiguous \(2\times 3\) and \(3\times 2\) rectangles, then rectangular injectivity and finite union closure imply that \(A_3\) is injective. The same criterion applies to every vertical edge-complementary block: a nonempty finite cover of that block by contiguous \(2\times 3\) and \(3\times 2\) rectangles implies injectivity of the vertical edge-complementary block. In the normalized horizontal-edge \(5\times 7\) frame, it is enough to give such a cover of the local \(T\)-region, since adjoining the two top-collar \(3\times 2\) rectangles gives a cover of \(A_3\).
Apply rectangular injectivity to every rectangle in the cover, then apply finite union closure to the nonempty family. For the normalized \(5\times 7\) edge complement, first extend the local \(T\)-cover by the two top-collar rectangles.
In the normalized horizontal-edge \(5\times 7\) frame with lower-left corner \((0,0)\), any rectangular cover of the local \(T\)-region extends to a rectangular cover of the edge-complementary block \(A_3\) by adjoining the two top-collar contiguous \(3\times 2\) rectangles. In the normalized vertical-edge \(7\times 5\) frame with lower-left corner \((0,0)\), any rectangular cover of the rotated local \(T\)-region extends to a rectangular cover of the vertical edge-complementary block by adjoining the two right-collar contiguous \(2\times 3\) rectangles.
Index the new cover by the old cover indices together with two extra indices for the collar rectangles. For the horizontal block, the decomposition is
For the vertical block, the decomposition is
In the normalized horizontal-edge \(5\times 7\) frame, the finite-lattice complementary block \(A_3\) is the local-window \(T\)-region together with two top-collar contiguous \(3\times 2\) rectangles. Consequently, if the local \(T\)-region is injective, then rectangular injectivity and union closure imply that \(A_3\) is injective. There is also a transposed \(7\times 5\) horizontal-frame collar identity with two contiguous \(2\times 3\) right-collar rectangles. For the rotated vertical edge-blocking regions, the corresponding complement is the rotated local \(T\)-region together with the same two right-collar rectangles; hence rotated \(T\)-injectivity, and hence a rectangular cover of rotated \(T\), implies injectivity of the vertical complementary block.
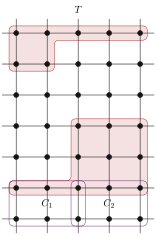 \( = \)
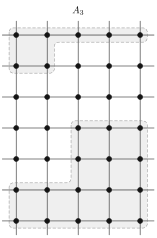
The two set identities follow by expanding the coordinate inequalities. The injectivity statements apply union closure first to the local \(T\)-region and the first collar rectangle, and then to the second collar rectangle.
A contiguous rectangle whose width is at least two and whose height is at least three is the union of the source \(2\times 3\) rectangles sliding over it, so rectangular injectivity and union closure prove it injective. The transposed statement holds for a contiguous rectangle of width at least three and height at least two.
Each cell of the rectangle lies in one of the contained source windows, so the rectangle equals the finite union of those windows; union closure then gives injectivity.
Let the two edge blocks be removed at an interior position of a sufficiently large lattice, with one row and column of room below and to the left and further room above and to the right. Then the complementary block \(A_3\) is the union of four full-length bands around the removed blocks — below, above, left, and right — together with two filler rectangles inside the bounding box of the removed blocks. Each band is a large contiguous rectangle and each filler is a source rectangle, all avoiding the removed blocks, so rectangular injectivity and union closure prove \(A_3\) injective with no rectangular-cover hypothesis. The transposed statement holds for the rotated vertical complementary block.
Scope restriction (open-boundary interior edges): These edge-blocking constructions apply only to edges with interior margins in the open rectangular model, whereas [ 220 , Theorem 3 ] obtains every edge via periodic translations on the torus; documented in [ 78 ] .
The six pieces cover the complement of the removed blocks, by expanding the coordinate inequalities. Each band is injective by the large-rectangle lemma and each filler by rectangular injectivity, so union closure gives injectivity of the union.
For an interior horizontal or vertical edge with the corresponding interior margins, the translated edge-blocking datum is built with no rectangular cover: its complementary-block injectivity is the interior \(A_3\) injectivity. A family of these cover-free interior data over all edges establishes the normal edge-blocking hypotheses, with the injective chain, endpoint membership, pairwise disjointness, and coverage at every edge.
This establishes the edge-blocking hypotheses for edges with interior margins [ 78 ] .
Each interior edge is horizontal or vertical; the corresponding interior blocking datum discharges its complementary-block injectivity through the interior \(A_3\) injectivity. Combining these per-edge data over all edges gives the edge-blocking hypotheses.
In the normalized \(5\times 7\) horizontal-edge frame, the red block is the vertical \(2\times 3\) block, the blue block is the horizontal \(3\times 2\) block, and the complementary block is the finite-lattice edge complement \(A_3\). The distinguished edge is a horizontal edge of the square-lattice graph. The left endpoint of the distinguished edge lies in the red block, the right endpoint lies in the blue block, the three regions are pairwise disjoint, and their union is the whole finite square lattice. If the local \(T\)-region is injective, rectangular injectivity and union closure give injectivity of all three blocks; in particular a rectangular cover of \(T\) suffices. The normalized \(7\times 5\) vertical-edge frame has the analogous red and blue rectangular blocks, a distinguished vertical edge, and the same set-theoretic blocking data; at this stage its complementary-block injectivity is either kept as an explicit hypothesis or obtained from rotated \(T\)-injectivity, and therefore from a rectangular cover of rotated \(T\), by the vertical collar lemma. In both cases the named blocking datum supplies the corresponding three injective regions for the edge-blocked chain.
The endpoint memberships are coordinate checks. Rectangular injectivity gives the rectangular red and blue blocks. For the horizontal edge, the collar lemma gives the complement, and the rectangular cover criterion removes the direct \(T\)-injectivity input when such a cover is supplied. For the vertical edge, complement injectivity is an explicit input or is obtained from the rotated \(T\)-cover. The disjointness and cover statements are finite-set complement identities.
For any coordinate origin whose horizontal blocking window lies in the finite square lattice, there is a distinguished horizontal edge with the same relative position as in the normalized picture. The translated red region is the \(2\times 3\) block, the translated blue region is the \(3\times 2\) block, and the complementary region is the finite-lattice complement of their union. If this complementary region is injective, these three regions form the one-edge blocking datum; if it has a rectangular cover, rectangular injectivity and union closure supply that complementary injectivity; and two rows and columns of margin below and to the left together with eight rows and columns of total room around the frame supply the same datum directly. In each form the datum supplies the three injective regions used in the edge-blocked chain, and the distinguished edge is the only edge crossing between the red and blue regions. The distinguished edge is the corresponding coordinate right edge. At coordinate origin \(0,0\), the translated edge and the three translated regions specialize to the normalized horizontal picture.
The endpoint memberships and horizontal orientation are coordinate checks. Rectangular injectivity gives the red and blue blocks. The complementary block is supplied either as an input or from a rectangular cover, and the disjointness and covering identities follow from the finite-set complement formulas.
For any coordinate origin whose vertical blocking window lies in the finite square lattice, there is a distinguished vertical edge with the same relative position as in the normalized vertical picture. The translated red region is the \(3\times 2\) block, the translated blue region is the \(2\times 3\) block, and the complementary region is the finite-lattice complement of their union. If this complementary region is injective, these three regions form the one-edge blocking datum; if it has a rectangular cover, rectangular injectivity and union closure supply that complementary injectivity; and two rows and columns of margin below and to the left together with eight rows and columns of total room around the frame supply the same datum directly. In each form the datum supplies the three injective regions used in the edge-blocked chain, and the distinguished edge is the only edge crossing between the red and blue regions. The distinguished edge is the corresponding coordinate upward edge. At coordinate origin \(0,0\), the translated edge and the three translated regions specialize to the normalized vertical picture.
The endpoint memberships and vertical orientation are coordinate checks. Rectangular injectivity gives the red and blue blocks. The complementary block is supplied either as an input or from a rectangular cover, and the disjointness and covering identities follow from the finite-set complement formulas.
Let \(A\) and \(B\) be PEPS tensors on the \(n\times m\) square lattice with positive physical dimension \(d{\gt}0\) and positive bond dimensions at every edge, generating the same state. Suppose both tensors satisfy the coordinate rectangular injectivity hypotheses (every contiguous \(2\times 3\) and \(3\times 2\) rectangle is injective) and the associated region-injectivity predicates are closed under finite unions. Then the bond dimensions of \(A\) and \(B\) agree at every edge with interior margins: for every edge \(e\) with a margin of at least one row and column of room below and to the left, and at least three rows and columns above and to the right (avoiding the lattice boundary),
The equality is derived from the one-edge blocking data built from the rectangular injectivity — the source’s Lemma inj_isomorph ( [ 220 , Section 3, lines 560–583 and 1407–1500 ] ) — together with the same-state and positive-bond assumptions; the bond dimension at the edge is not assumed.
Suppose \(e\) is horizontal; the vertical case is the rotated argument. Place the translated frame at \((x_0,y_0)=(x_e-1,y_e-2)\), so the interior margins give \(2\le x_0\), \(2\le y_0\), \(x_0+8\le n\), and \(y_0+8\le m\). The margin form of the translated blocking datum (Lemma 24.6.25) supplies, for each of \(A\) and \(B\), the injective red and blue blocks and the injective complement at that frame; the two data share the same regions, and the distinguished translated edge \(e'\) is the only edge crossing between the red and blue regions:
The one-edge comparison of Theorem 24.8.6 applied to the two data then gives
A coordinate check identifies \(e'\) with the coordinate right edge at \((x_e,y_e)\), hence with \(e\), and \(D_A(e)=D_B(e)\) follows.
A translated edge window records that a chosen edge is one of the translated horizontal or vertical edge pictures, together with a rectangular cover of the complementary block. Such a window gives the one-edge blocking datum for that edge, hence the three injective regions used in the edge-blocked chain. The coordinate right and upward edges obtain such windows directly from the corresponding translated picture. Equivalently, an actual coordinate right or upward edge obtains such a window when it has the necessary room around it for the translated \(5\times 7\) or \(7\times 5\) frame and the complementary cover is supplied. The same criterion applies to an arbitrary horizontal or vertical square-lattice edge after identifying it with its coordinate right or upward representative. The oriented margin-and-cover datum is the same criterion written as per-edge data in the rectangular coordinate model; it directly supplies the one-edge blocking datum, its three injective regions, and the identities \(u_e\in R_e\), \(v_e\in B_e\), \(R_e\cap B_e=R_e\cap C_e=B_e\cap C_e=\varnothing \), and \(R_e\cup B_e\cup C_e=V\). The boundary obstruction lemmas show that these translated-window and margin-cover criteria are interior criteria, not the final every-edge construction in the open square-lattice model.
Given rectangular injectivity hypotheses, finite union closure, and a translated edge window at every edge of the finite square lattice, the corresponding one-edge blockings determine the normal edge-blocking hypotheses. This is the conditional construction; constructing such windows for all edges of the \(7\times 7\) lattice remains separate; the current open rectangular translated-window criterion does not by itself supply such a family. The one-edge datum recovered from the resulting hypotheses is the datum supplied by the corresponding translated window, and the resulting hypotheses give the three injective regions at every edge, together with \(u_e\in R_e\), \(v_e\in B_e\), \(R_e\cap B_e=R_e\cap C_e=B_e\cap C_e=\varnothing \), and \(R_e\cup B_e\cup C_e=V\). Equivalently, it is enough to supply the oriented margin-and-cover data at every edge; the resulting hypotheses recover the corresponding datum, give the same three injectivity conclusions, and give the same endpoint, disjointness, and covering conclusions. The obstruction theorem records that this interior margin-cover criterion does not by itself supply data at every edge of the open \(7\times 7\) lattice.
Apply the general construction for one-edge blocking data to the datum supplied by the chosen translated window at each edge.
If region injectivity is closed under unions, then the coordinate square-lattice rectangular injectivity hypotheses imply that the displayed regions \(R\) and \(S\) are injective.
Region \(R\) is the union of one injective \(2\times 3\) rectangle and one injective \(3\times 2\) rectangle. Region \(S\) is the union of two injective \(2\times 3\) rectangles. Apply union closure in each case.
Fix a square-lattice PEPS tensor with every bond dimension positive whose blocked tensor is injective on every contiguous \(2\times 3\) and \(3\times 2\) rectangle. Then the displayed regions \(R\) and \(S\) are injective. If moreover the displayed region \(T\) has a cover by such rectangles, then \(T\) is injective too. The union closure used here is supplied by the overlapping union lemma, so no single-vertex injectivity is assumed.
At a coordinate offset \((a,b)\) the comparison square is the \(3\times 3\) contiguous coordinate rectangle with lower-left corner \((a,b)\). The comparison region is this square with its lower-left corner \((a,b)\) removed, presented as the union of the \(2\times 3\) contiguous rectangle at \((a+1,b)\) and the \(3\times 2\) contiguous rectangle at \((a,b+1)\). This is an auxiliary one-site comparison pair carrying its omitted site at the lower-left corner; it is the reflected counterpart of the displayed regions \(R\) and \(S\), whose omitted site \(S\setminus R\) sits at the lower-right corner, placed at an arbitrary offset rather than at a fixed origin. The interior window at \((a,b)\) for a finite \(n\times m\) lattice is the placement margin \(4\le a\), \(a+9\le n\), \(4\le b\), \(b+9\le m\), under which every boundary edge of the comparison square and of the comparison region carries the interior margins of the open edge-blocking geometry.
For any offset \((a,b)\) a vertex with coordinates \((x,y)\) lies in the comparison region at \((a,b)\) if and only if
Let \(v\) be a lattice vertex and place the comparison region at \(v\)’s own coordinates. Then \(v\) lies outside that region, and inserting \(v\) back in recovers the full \(3\times 3\) comparison square placed at \(v\)’s coordinates.
Membership unfolds the union of the two contiguous rectangles into (21). Place the region at \(v\)’s own coordinates, so \((a,b)=(x,y)=(v_1,v_2)\). The corner offset \((v_1,v_2)\) fails the first disjunct because \(v_1+1\le v_1\) is false, and fails the second because \(v_2+1\le v_2\) is false:
Thus \(v\) lies outside the region. Inserting \(v\) therefore yields the region together with \(\{ (v_1,v_2)\} \), and a vertex lies in this set exactly when it equals \(v\) or already lies in the region. That is the membership condition of the \(3\times 3\) square, the corner being the one cell of the square that both pieces omit.
On a finite \(n\times m\) lattice, if \(a+3\le n\) and \(b+3\le m\) then the complement of the comparison square at \((a,b)\) is the union of the four coordinate bands
A vertex \((x,y)\) lies in the comparison square exactly when \(a\le x{\lt}a+3\) and \(b\le y{\lt}b+3\). With \(0\le x{\lt}n\) and \(0\le y{\lt}m\) on the lattice, the negation of that conjunction is membership in (22):
On a finite \(n\times m\) lattice, if \(2\le a\), \(1\le b\), \(a+3\le n\), and \(b+3\le m\) then the complement of the comparison region at \((a,b)\) is the union of the same four bands of Lemma 24.6.34 together with the \(3\times 2\) corner rectangle \(\{ (x,y):a-2\le x{\lt}a+1,\ b-1\le y{\lt}b+1\} \), which contains the omitted corner \((a,b)\).
By (21), a vertex \((x,y)\) lies in the complement exactly when both disjuncts fail:
Together with \(0\le x{\lt}n\) and \(0\le y{\lt}m\), this places the vertex either in one of the four bands of (22) or in the \(3\times 2\) corner rectangle. Writing \(R\) for the comparison region and \(S\) for the comparison square,
since the comparison region is the comparison square with the corner \((a,b)\) removed, and that corner lies in the displayed \(3\times 2\) rectangle. The hypotheses \(2\le a\) and \(1\le b\) keep the corner rectangle’s lower-left coordinates \((a-2,b-1)\) within the lattice.
Assume rectangular injectivity and union closure. On a finite \(n\times m\) lattice, if \(a+3\le n\) and \(b+3\le m\) then the comparison region at \((a,b)\) is injective, being the union of a \(2\times 3\) and a \(3\times 2\) rectangle, and the comparison square at \((a,b)\) is injective, being a \(3\times 3\) rectangle.
Apply union closure to the rectangular injectivity of the contained \(2\times 3\) and \(3\times 2\) rectangles for the region, the square being a single large rectangle.
Assume rectangular injectivity and union closure. On a finite \(n\times m\) lattice, if \(2\le a\), \(2\le b\), \(a+5\le n\), and \(b+5\le m\) then the complement of the comparison square at \((a,b)\) is injective, being the union of its four surrounding bands, and the complement of the comparison region at \((a,b)\) is injective, being that union together with one further corner rectangle.
Rewrite each complement by its band decomposition and apply union closure to the bands, each a large contiguous rectangle, and to the corner rectangle.
Around one edge, the normal proof uses a blocking into three injective regions: a red region containing one endpoint, a blue region containing the other endpoint, and an injective complementary region. The three regions are pairwise disjoint and cover the whole vertex set. The edge-blocking hypotheses are precisely this one-edge datum at every edge; the red, blue, and complementary regions are read off from it. The local blocking picture used in the proof of [ 220 , Theorem 3 ] :
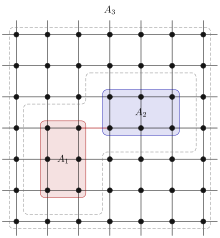
In the open \(7\times 7\) rectangle, let \(u=(0,2)\) and \(v=(1,2)\) be the endpoints of a left-boundary horizontal edge. Define a region relation by
The relation \(\operatorname{inj}_{\partial }\) is closed under unions.
If \(u\in A\cup B\), then \(u\) belongs to one of the two regions. The defining implication for that region places \(v\) in the same region, hence in \(A\cup B\).
Every contiguous \(2\times 3\) and \(3\times 2\) rectangle satisfies \(\operatorname{inj}_{\partial }\). Indeed, a rectangle of either shape that contains \(u\) necessarily contains its right neighbor \(v\).
This follows directly from the horizontal coordinates of the two endpoints.
The relation \(\operatorname{inj}_{\partial }\) admits no three-partite injective MPS blocking around the edge \(u\)–\(v\).
The red region must contain \(u\), so its injectivity places \(v\) in the red region. The blocking requires \(v\) to lie in the disjoint blue region, which is impossible.
There is a union-closed region relation on the open \(7\times 7\) rectangle that satisfies all contiguous \(2\times 3\) and \(3\times 2\) rectangle conditions, but admits no three-partite injective MPS blocking around the edge \(u\)–\(v\).
This counterexample for abstract region relations shows only that the rectangular and union hypotheses do not entail a boundary blocking on an open rectangle. It neither gives a PEPS tensor nor concerns the periodic translationally invariant statement of [ 220 , Theorem 3 ] . The later general theorem in the source takes the every-edge three-partite injective MPS blocking as a hypothesis.
Use the relation \(\operatorname{inj}_{\partial }\) and the three preceding theorems.
A family of one-edge blocking data is precisely the normal edge-blocking hypotheses. If \(H\) is formed from the family \(d_e\), then the one-edge datum that \(H\) associates with \(e\) is \(d_e\). Write the endpoints of \(e\) as \(u_e{\lt}v_e\) in the canonical vertex ordering. If the three regions are \(R_e\), \(B_e\), and \(C_e\), then
and the underlying PEPS tensor is injective on \(R_e\), \(B_e\), and \(C_e\).
By construction, the one-edge datum at each edge \(e\) is \(d_e\). The endpoint, disjointness, and coverage statements in (23), together with the injectivity statements, are exactly the corresponding assumptions of that one-edge datum.
For each site, the normal theorem assumes two injective regions with injective complements that differ exactly at that site. This is the one-site comparison used after the edge gauges have been obtained. Diagrammatically, in the square-lattice proof this is the comparison between the source regions \(R\) and \(S=R\cup \{ v\} \):
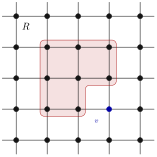 \(\qquad \)
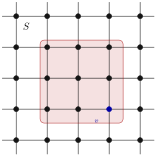 \(\qquad R\subset S=R\cup \{ v\} \)
For the two regions associated to a site \(v\), a vertex \(w\) belongs to the region containing \(v\) if and only if either \(w=v\), or \(w\) belongs to the comparison region omitting \(v\).
If \(w=v\), use the distinguished-site membership and nonmembership assumptions. If \(w\neq v\), use the equality of the two regions away from the distinguished site.
In the translationally invariant square-lattice proof, the source paper assumes that every \(2\times 3\) and \(3\times 2\) region is injective. The statement here specifies the corresponding abstract hypothesis: it records the rectangular injectivity assumptions, the size bound \(n,m\geq 7\) with \(|V|=nm\), and three finite regions \(R\), \(S\), and \(T\) whose injectivity is assumed directly. It does not by itself assert that these regions are the displayed square-lattice unions, nor that their translated variants give the edge-centred blocking around every edge. Conversely, for the coordinate square lattice with \(n,m\geq 7\), the rectangular hypotheses, union closure, and a rectangular cover of the displayed \(T\)-region yield this abstract \(R,S,T\) structure, with \(R\) and \(S\) obtained from their rectangular decompositions and \(T\) obtained from the supplied cover. The source regions are:
\(\qquad \text{and}\qquad \) Under the square-lattice normality hypotheses of [ 220 , Theorem 3 ] , the regions \(R\), \(S\), and \(T\), together with their translated variants, give an edge-centred blocking into red, blue, and complementary injective regions. These are the regions on which the three-site injective-chain insertion argument is applied. Here the translations are those of the periodic square lattice; the cited proof does not give separate boundary blockings for an open rectangle:
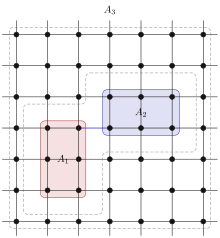 \(\quad \Rightarrow \quad \)
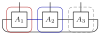
In the translationally invariant normal square-lattice case, the edge gauges obtained after blocking are represented by one horizontal matrix \(X\) and one vertical matrix \(Y\), unique up to scalar. Absorbing these matrices into \(B\) gives a tensor \(\widetilde B\), equivalently the final local gauge formula of [ 220 , Theorem 3 ] :
 \( = \lambda \)
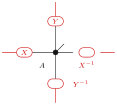
The torus form of this absorption, with the gauge family carried onto every edge by the translations from one matrix per orientation class, is part of Theorem 24.7.1.10. This is the geometry used in the source. An analogous assertion for an open rectangle would require additional boundary data and is not an unproved case of the cited theorem.
Let \(A\) and \(B\) be translationally invariant normal square-lattice PEPS tensors such that every \(2\times 3\) and \(3\times 2\) region is injective. If they generate the same state on an \(n\times m\) region with \(n,m\geq 7\), then they are related by horizontal and vertical gauges \(X,Y\), up to a scalar \(\lambda \) satisfying \(\lambda ^{nm}=1\). This is [ 220 , Theorem 3 ] . Theorem 24.6.51 proves a related interior-window theorem on an open rectangle, without translation invariance and with per-vertex scalars in place of the single \(\lambda \); the gauge-equivalence conclusion on a general connected graph, from region injectivity alone, is Theorem 24.8.7. The periodic statement of the source is established in Theorem 24.7.1.10. Extending the open-rectangle theorem to its boundary is a separate question.
Let \(A\) and \(B\) be PEPS tensors on the open \(n\times m\) square lattice with the same positive physical dimension and equal bond dimensions, generating the same state, and both normal with injective rectangles (Definition 24.6.13): every contiguous \(2\times 3\) and \(3\times 2\) coordinate rectangle of either tensor is injective, and every virtual bond space is nonzero. Then there is a family of invertible matrices, one on each edge, such that:
at every edge with interior margins (for a horizontal edge with left endpoint \((x,y)\): \(3\le x\), \(x+7\le n\), \(4\le y\), \(y+6\le m\); for a vertical edge the mirrored margins), inserting any matrix on the edge of \(A\) gives the same coefficient as inserting it on the corresponding edge of the gauge-absorbed \(B\), for every physical configuration; and
every vertex \(v=(x,y)\) of the interior comparison window \(4\le x\le n-9\), \(4\le y\le m-9\) carries a nonzero scalar \(\lambda _v\) such that \(A_v\) equals \(\lambda _v\) times the gauge action of the family on \(B\) at \(v\), on every virtual configuration of the incident edges and every physical index.
This is the open-lattice form of [ 220 , Theorem 3 ] , restricted in two ways. First, the conclusion reaches only the interior: the absorbed equality holds at the edges with interior margins and the per-vertex relation at the window vertices, while vertices near the lattice boundary are not reached, the blocking frames of the open lattice requiring interior margins. Second, the scalars of distinct vertices are not asserted equal, and no condition \(\lambda ^{nm}=1\) is asserted: the single \(\lambda \) of the source comes from translation invariance, which is not assumed here, and without it a single scalar is false — rescaling the components of \(A\) at two interior vertices by \(\mu \) and \(\mu ^{-1}\) preserves the state and the rectangular injectivity but separates the two scalars. No lower bound on \(n\) or \(m\) is assumed; both conclusions are empty when the lattice is too small to contain interior edges or window vertices.
The union closure of injective regions follows from the nonzero bond spaces and Lemma 24.5.10. The translated blocking frames at the edges with interior margins produce per-edge gauges, whose absorption into \(B\) gives the absorbed inserted-coefficient equality at every such edge. A gauge preserves blocked-region linear independence, so at every window vertex the region comparison applies to the gauge-absorbed tensor: comparing the \(3\times 3\) square at the vertex minus its corner with its one-site completion yields two proportionality scalars \(c_R\) and \(c_S\), every boundary edge of either region carrying interior margins, and the inserted-site extraction gives the per-vertex relation with the ratio \(\lambda _v = c_S/c_R\).
24.7 Torus Normal PEPS
A translationally invariant PEPS lives on a torus: a finite square lattice whose opposite boundaries are identified, so that the two coordinates are read modulo the periods \(n\) and \(m\).
Translations act on the vertices and edges. Transporting a tensor along a graph isomorphism \(\phi \) relabels its coefficients by \(\operatorname{Coeff}_{A^\phi }(\sigma )=\operatorname{Coeff}_A(\sigma \circ \phi )\), so two tensors generating the same state still do after transport. This is the setting in which the normal Fundamental Theorem specializes to a single site-independent tensor and produces the global phase of [ 220 , Theorem 3 ] .
For \(n,m{\gt}1\), the discrete \(n\times m\) torus has vertex set \(\mathbb {Z}/n\mathbb {Z}\times \mathbb {Z}/m\mathbb {Z}\). Its graph joins \((x,y)\) to \((x+1,y)\) and to \((x,y+1)\), with the coordinates read cyclically; every edge is of one of these two forms, so every edge is horizontal or vertical. Translation by \((a,b)\) is the graph automorphism \(\tau _{a,b}(x,y)=(x+a,y+b)\). The induced action on edges sends an edge with unordered endpoint pair \(\{ u,v\} \) to the edge with unordered endpoint pair \(\{ \tau _{a,b}(u),\tau _{a,b}(v)\} \); in particular it preserves the horizontal and vertical orientation classes. For a general graph isomorphism \(\phi :G\simeq G'\), the same endpoint action gives a bijection on edges and a bijection from the edges incident to \(v\) to the edges incident to \(\phi (v)\).
Let \(\phi :G\simeq G'\) be a graph isomorphism. The transported tensor \(A^\phi \) on \(G'\) has bond dimension \(D^\phi _{e'}=D_{\phi ^{-1}(e')}\) at every edge \(e'\) of \(G'\). Its local tensor at \(w\in G'\) is the local tensor of \(A\) at \(\phi ^{-1}(w)\), with virtual indices moved through the incident-edge bijection induced by \(\phi \).
For every graph isomorphism \(\phi :G\simeq G'\) and every physical configuration \(\sigma \) on the vertices of \(G'\), \(\operatorname{Coeff}_{A^\phi }(\sigma )=\operatorname{Coeff}_A(\sigma \circ \phi )\).
The edge bijection induced by \(\phi \) identifies virtual configurations of \(A^\phi \) with virtual configurations of \(A\). After this change of summation variables, the local factor at \(w\in G'\) becomes the local factor of \(A\) at \(\phi ^{-1}(w)\). Reindexing the finite product over vertices by \(\phi \) gives the coefficient equality.
If two PEPS tensors on \(G\) have equal state coefficients for every physical configuration, then their transports along any graph isomorphism \(\phi :G\simeq G'\) have equal state coefficients for every physical configuration on \(G'\).
By Theorem 24.7.3,
where the middle equality is the assumed equality of state coefficients.
A PEPS tensor \(A\) on the discrete torus is translation invariant if \(A^{\tau _{a,b}}=A\) for every translation \(\tau _{a,b}\). This is the setting of [ 220 , Theorem 3 ] , where one tensor is repeated at every site of a periodic lattice.
If \(A\) is translation invariant on the discrete torus, then \(\operatorname{Coeff}_A(\sigma \circ \tau _{a,b})=\operatorname{Coeff}_A(\sigma )\) for every translation \(\tau _{a,b}\) and every physical configuration \(\sigma \).
Theorem 24.7.3 gives
using \(A^{\tau _{a,b}}=A\) from translation invariance.
A PEPS tensor \(A\) on the discrete torus represents a translation-invariant state if
for every lattice translation \(\tau _{a,b}\) and every physical configuration \(\sigma \). This condition concerns the contracted state; the local tensor family itself may depend on the lattice site.
A translation-invariant torus tensor \(A\) represents a translation-invariant state: for every lattice translation \(\tau _{a,b}\) and physical configuration \(\sigma \),
This is Theorem 24.7.6 for every translation and physical configuration.
If \(A\) represents a translation-invariant state, then \(A\) and \(A^{\tau _{a,b}}\) represent the same state for every translation:
Transport gives \(\operatorname{Coeff}_{A^{\tau _{a,b}}}(\sigma ) =\operatorname{Coeff}_A(\sigma \circ \tau _{a,b})\), and state translation invariance identifies the right-hand side with \(\operatorname{Coeff}_A(\sigma )\).
A bond-dimension function on the torus is orientation-uniform with horizontal dimension \(D_h\) and vertical dimension \(D_v\) if \(D_{e_h}=D_h\) for every horizontal edge \(e_h\) and \(D_{e_v}=D_v\) for every vertical edge \(e_v\). The reference horizontal edge is the right edge at the origin, and the reference vertical edge is the up edge at the origin.
If \(A\) is translation invariant on the discrete torus, then its bond dimensions are orientation-uniform. Explicitly, with \(D_h=D_{e_h}\) at the reference right edge \(e_h\) and \(D_v=D_{e_v}\) at the reference up edge \(e_v\), one has \(D_{f_h}=D_h\) for every horizontal edge \(f_h\) and \(D_{f_v}=D_v\) for every vertical edge \(f_v\).
Translation invariance gives \(A^{\tau _{a,b}}=A\), hence \(D_A(\tau _{a,b}(e))=D_A(e)\) for every edge \(e\). Every horizontal edge \(f_h\) has the form \(f_h=\tau _{a,b}(e_h)\) for a translate of the reference right edge, so
The same argument with the reference up edge gives \(D_{f_v}=D_v\).
Failure of the row-and-column reduction.
A matrix \(M\in M_{4}(\mathbb {C})\) is a per-edge product on two collected vertical bonds if, under the identification \((r,s)\longmapsto 2r+s\) between \(\{ 0,1\} \times \{ 0,1\} \) and \(\{ 0,1,2,3\} \), there are matrices \(Y_0,Y_1\in M_{2}(\mathbb {C})\) such that, for all \(r,s,r',s'\in \{ 0,1\} \),
The row-cut factorization assertion is the following statement. Let \(A\) and \(B\) be MPS tensors with physical alphabet \(\{ 0,\ldots ,15\} \) and bond space \(\mathbb {C}^4\). If \(A\) and \(B\) are \(1\)-block injective and generate the same MPV family, then there exist \(Z\in \mathrm{GL}_4(\mathbb {C})\) and \(\lambda \in \mathbb {C}\) such that \(Z\) is a per-edge product matrix and \(B^i=\lambda Z^{-1}A^iZ\) for all physical indices \(i\in \{ 0,\ldots ,15\} \). This is the additional product conclusion needed by a row-wise one-dimensional reduction before it could imply the per-edge conclusion of [ 220 , Theorem 3 ] .
The row-cut factorization assertion is false. Explicitly, let \(E_{ab}\in M_{4}(\mathbb {C})\) be the matrix units and set
Then \(A\) and \(B\) are \(1\)-block injective and generate the same MPV family, but there are no \(Z\in \mathrm{GL}_4(\mathbb {C})\) and \(\lambda \in \mathbb {C}\) with \(Z\) a per-edge product matrix and \(B^{(a,b)}=\lambda Z^{-1}E_{ab}Z\) for all \(a,b\in \{ 0,\ldots ,3\} \).
The matrix units span \(M_{4}(\mathbb {C})\), hence \(A\) is \(1\)-block injective; conjugation by \(G\) preserves this property for \(B\). For every word \(w=((a_1,b_1),\ldots ,(a_N,b_N))\), one has \(B^w=G^{-1}A^wG\) and \(\operatorname{tr}(B^w)=\operatorname{tr}(A^w)\), so the two MPV families are equal.
Suppose that \(Z\) and \(\lambda \) satisfy \(B^{(a,b)}=\lambda Z^{-1}E_{ab}Z\) for every \(a,b\in \{ 0,\ldots ,3\} \). With \(W=ZG^{-1}\), multiplication by \(Z\) on the left and by \(G^{-1}\) on the right gives \(WE_{ab}=\lambda E_{ab}W\) for every matrix unit \(E_{ab}\). Taking the \((x,y)\) entry gives \(W_{x,a}\delta _{b,y}=\lambda \delta _{x,a}W_{b,y}\) for all \(x,y,a,b\in \{ 0,\ldots ,3\} \). With \(y=b\), this gives \(x\ne a\Rightarrow W_{x,a}=0\) and \(W_{a,a}=\lambda W_{b,b}\).
Since \(Z\) and \(G\) are invertible, so is \(W\). Thus the diagonal entries cannot all vanish; the case \(a=b\) gives \(\lambda =1\), and then \(W_{a,a}=W_{b,b}\) for all \(a,b\). Hence \(W=c\mathbb {1}_4\) and \(\lambda =1\) for some \(c\ne 0\), so \(Z=cG\).
For a matrix \(M\in M_{4}(\mathbb {C})\), write \(M_{rr'}\in M_{2}(\mathbb {C})\) for the block whose \((s,s')\) entry is \(M_{(r,s),(r',s')}\). If \(Z\) were a per-edge product, then \(Z_{rr'}=(Y_0)_{r,r'}Y_1\) for some \(Y_0,Y_1\in M_{2}(\mathbb {C})\). In particular, \((Z_{00})_{s,s'}(Z_{01})_{1,1} =(Z_{01})_{s,s'}(Z_{00})_{1,1}\). Since \(Z=cG\) and \(c\ne 0\), scaling cancels from this block proportionality condition. The corresponding blocks of \(G\) are
Substitution into \((G_{00})_{00}(G_{01})_{11} =(G_{01})_{00}(G_{00})_{11}\) gives \(0=1\). Hence no per-edge product conjugator can exist.
Staircase-window geometry for a reference edge.
Let \(L,K{\gt}0\), let \(s=(a,b)\) be a staircase corner on the torus, and assume \(a+2L\le n\) and \(2K\le m\). Let \(e\) be the horizontal reference edge from \((a+L-1,b+K-1)\) to \((a+L,b+K-1)\), and let \(W_j\) be the \(j\)th staircase window based at \(s\). Then the left endpoint \(u=(a+L-1,b+K-1)\) lies in \(W_j\) if and only if \(1\le j\).
The endpoint formula gives the two coordinate distances from the corner: the column distance is \(L-1\) and the row distance is \(K-1\). Substituting these distances into the staircase-window membership criterion gives exactly \(1\le j\).
In the same notation, the right endpoint \(w=(a+L,b+K-1)\) lies in \(W_j\) if and only if \(j{\lt}L\).
The right endpoint has column distance \(L\) and row distance \(K-1\) from \(s\). The row condition is automatic, while the column band contains this distance precisely for \(j{\lt}L\).
If \(j=0\) or \(L\le j\), then the reference edge \(e\) is a boundary edge of \(W_j\): exactly one of its two endpoints lies in the window.
If \(1\le j{\lt}L\), then both endpoints of \(e\) lie in \(W_j\).
The left-endpoint criterion gives \(u\in W_j\) from \(1\le j\), and the right-endpoint criterion gives \(w\in W_j\) from \(j{\lt}L\).
If \(1\le j{\lt}L\), then \(e\) is not a boundary edge of \(W_j\).
By Lemma 24.7.18, both endpoints of \(e\) lie in \(W_j\). The definition of a boundary edge requires exactly one endpoint in the region, so \(e\) is not a boundary edge of \(W_j\).
24.7.1 Staircase patch geometry
Fix a horizontal reference edge and write the staircase corner as \(s=(a,b)\). For coordinate intervals write \(I(u,v)=\{ t\mid u\le t{\lt}v\} \). The two end windows of the overlapping-window chain are
Their end pair is \(S=W_{\mathrm{left}}\cup W_{\mathrm{right}}\). The staircase patch is the union
and the corner cut out by the two end windows is \(C=I(a,a+L)\times I(b+K,b+2K-1)\). Completing \(C\) by one row gives the \(L\times K\) rectangle \(\widehat C=I(a,a+L)\times I(b+K,b+2K)\). These cyclic rectangles are the regions used in the staircase chaining and corner-stripping step of [ 220 , proof sketch, lines 2320–2445 ] .
If \(2L\le W\), then the two end windows of the horizontal staircase are disjoint: \(W_{\mathrm{left}}\cap W_{\mathrm{right}}=\varnothing \).
Their horizontal coordinate intervals are \(I(a,a+L)\) and \(I(a+L,a+2L)\). The bound \(2L\le W\) prevents wraparound overlap.
Under the one-orientation \(L\times K\) torus-window injectivity hypotheses, the three regions \(W_{\mathrm{left}}\), \(W_{\mathrm{right}}\), and \(\widehat C\) are injective.
Each of the three regions is an \(L\times K\) cyclic rectangle, so the window-injectivity hypothesis applies directly.
If \(L,K{\gt}0\), \(2L\le W\), and \(2K\le H\), then the corner is disjoint from the end pair and the patch decomposes as \(P=S\cup C\), with \(P\setminus S=C\).
In the no-wraparound rectangle, the rows and columns of the two end windows and the corner are the displayed intervals above. The interval calculation gives the disjointness and identifies every point of \(P\) with either an end-window point or a corner point.
On the discrete torus, the rectangular injectivity hypotheses assert that every contiguous \(2\times 3\) and every contiguous \(3\times 2\) coordinate rectangle is injective for the given region-injectivity assignment. This is the torus counterpart of the square-lattice rectangular injectivity hypotheses.
A PEPS tensor on the discrete torus is normal with injective rectangles when its family of injective regions satisfies the torus rectangular injectivity hypotheses and every virtual bond space is nonzero. This is the hypothesis on each tensor in [ 220 , Theorem 3 ] . The nonzero bond spaces are the standing convention of that section; region injectivity does not imply them, and the convention is recorded in [ 67 ] .
At a frame origin \((x_0,y_0)\) with at least two columns and one row of margin below and to the left (one column and two rows in the rotated case), and with the removed blocks either touching the seam (\(x_0+5=n\), \(y_0+5=m\)) or keeping a further margin of at least two, the horizontal reference edge \(e_h\) is the right edge leaving \((x_0+1,y_0+2)\), and the vertical reference edge \(e_v\) is the up edge leaving \((x_0+2,y_0+1)\). Around each reference edge the rectangular injectivity hypotheses and union closure supply the one-edge blocking datum: the red block, the blue block, and the complement are injective, and the reference edge is the only edge crossing between the red and blue blocks,
and similarly with \(e_v\) at the rotated frame.
The red and blue blocks are the removed edge blocks of the frame, so rectangular injectivity covers them; union closure then gives the injectivity of the remaining complement. The crossing-edge identity enumerates the edges joining the two blocks.
Let \(A\) and \(B\) be translationally invariant PEPS tensors on the \(n\times m\) torus with \(n,m\geq 7\) and positive physical dimension \(d{\gt}0\), generating the same state. Suppose both tensors are normal with injective rectangles (Definition 24.7.1.6): every contiguous \(2\times 3\) and \(3\times 2\) torus rectangle is injective, and every virtual bond space is nonzero. Then the bond dimensions of \(A\) and \(B\) agree on every edge:
The equality is derived from the one-edge blocking data built from the rectangular injectivity — the source’s Lemma inj_isomorph ( [ 220 , Section 3, lines 560–583 and 1407–1500 ] ) — together with the translation invariance and same-state assumptions; the bond dimension is not assumed as a hypothesis.
The nonzero bond spaces give union closure of injective regions for each tensor (Lemma 24.5.10). Place the frame at \((x_0,y_0)=(n-5,m-5)\); since \(n,m\geq 7\) the margins hold with the touching-seam alternative. Let \(e_h\) and \(e_v\) be the horizontal and vertical reference edges of Lemma 24.7.1.7 at this frame. The blocking data built from \(A\) and from \(B\) around \(e_h\) share the same red and blue blocks, so the one-edge comparison of Theorem 24.8.6 applies at the unique crossing edge and gives
and the rotated datum at \(e_v\) gives
Every torus edge \(e\) is horizontal or vertical. A horizontal \(e\) is the right edge leaving some vertex \(p\), and with the translation \(\tau \) carrying the reference vertex to \(p\), translation invariance (Theorem 24.7.11) gives
and the same for \(B\); hence \(D_A(e)=D_B(e)\). A vertical \(e\) is treated through \(e_v\), and the equality \(D_A=D_B\) follows.
Let \(A\) and \(B\) be translationally invariant normal PEPS on the discrete torus such that every \(2\times 3\) and \(3\times 2\) region is injective. If they generate the same state on an \(n\times m\) region with \(n,m\geq 7\), then they are related by horizontal and vertical gauges \(X,Y\), up to a scalar \(\lambda \) satisfying \(\lambda ^{nm}=1\), and \(X\) and \(Y\) are unique up to a multiplicative constant. This is [ 220 , Theorem 3 ] on the torus geometry, where every edge is interior and translation acts freely. Theorem 24.7.1.10 proves this at the source’s sizes \(n,m\geq 7\) with the gauge family described by its translation covariance, and the uniqueness of \(X\) and \(Y\) up to a multiplicative constant is proved at the same sizes in Theorem 24.7.1.12 per edge, Theorem 24.7.1.13 on the two orientation classes, and Theorem 24.7.1.14 against the per-vertex relation. In the torus edge convention the two class matrices \(X\) and \(Y\) are read through this translation-covariant family: seam edges carry the transposed inverse of the corresponding class matrix, so this is the orientation-faithful form of the source’s horizontal and vertical gauges.
Let \(A\) and \(B\) be translationally invariant PEPS tensors on the discrete \(n\times m\) torus with \(n,m\geq 7\), with positive physical dimension, generating the same state, and both normal with injective rectangles (Definition 24.7.1.6). Then the bond dimensions of \(A\) and \(B\) agree on every edge, and there are a family of invertible matrices, one on each edge, carried onto each edge by the torus translations from a single matrix on a reference horizontal edge and a single matrix on a reference vertical edge, and a single scalar \(\lambda \) with \(\lambda ^{nm}=1\), such that at every site the tensor \(A\) equals \(\lambda \) times the gauge action of the family on \(B\). The family also realizes the absorbed inserted-coefficient equality at every edge: inserting any matrix on an edge of \(A\) gives the same coefficient as inserting it on the corresponding edge of the gauge-absorbed \(B\). This is [ 220 , Theorem 3 ] on the torus at the source’s sizes \(n,m\geq 7\), with the horizontal and vertical gauges \(X\), \(Y\) described by translation covariance: the stored orientation of a wraparound edge is reversed, so on the seam the family carries the transposed inverse of the class matrix, and a family that is literally one matrix per orientation class cannot realize the absorbed equality there. The translation covariance of the family, with the scalar \(\lambda \) kept separate rather than absorbed, realizes the remark of [ 220 ] following the general normal theorem: for a translationally invariant system the gauges are also translationally invariant, provided the proportionality constants are not absorbed into the gauges. The uniqueness of \(X\) and \(Y\) up to a multiplicative constant is not part of this statement; the uniqueness clause is Theorem 24.7.1.12 (per edge, against the absorbed equality), Theorem 24.7.1.13 (one constant per orientation class), and Theorem 24.7.1.14 (against the per-vertex relation itself).
The union closure of injective regions follows from the nonzero bond spaces and Lemma 24.5.10, and the bond-dimension equality \(D_A=D_B\) is derived from the rectangular injectivity hypotheses and the same-state hypothesis by Theorem 24.7.1.8; neither is assumed. The reference blockings are anchored against the far seam: the removed blocks keep a margin of at least two rows and columns below and to the left and end exactly at the seam above and to the right, so the complementary region decomposes into wraparound-free rectangular bands on every torus with \(n,m\geq 7\). The coherent blocking frames at every edge produce per-edge gauges, whose absorption into \(B\) gives the absorbed inserted-coefficient equality at every edge; the absorbing family is built by transporting one reference gauge per orientation class, so it commutes with the torus translations. A gauge preserves blocked-region linear independence, so the region comparison applies to the gauge-absorbed tensor: comparing the corner region with its one-site completion yields proportionality scalars \(c_R\) and \(c_S\) such that, with \(\lambda =c_S/c_R\),
Translation covariance carries the same scalars to every site. Taking the product over all vertices and using the invariance of the closed state coefficient gives \(\lambda ^{nm}=1\).
Let \(A\) and \(B\) be PEPS tensors on the discrete \(n\times m\) torus with \(n,m{\gt}1\), with equal bond dimensions and positive bond dimensions, generating the same state, and let \(X\) be a family of invertible matrices, one on each edge. Suppose that at every site \(v\) a region \(R_v\) not containing \(v\) is supplied together with the two two-block scalar proportionalities of the blocked weights of \(A\) and of the gauge-absorbed second tensor over \(R_v\) and over \(R_v\cup \{ v\} \), with ratios \(c_R(v)\) and \(c_S(v)\) satisfying \(c_R(v)\ne 0\) and whose quotient \(c_S(v)/c_R(v)\) is a single scalar \(\lambda \) independent of \(v\), and with the gauge-absorbed region block linearly independent. If, in addition, a single comparison region whose block and complement block are both blocked-tensor injective is supplied, then \(\lambda \) raised to the number of torus sites is one: \(\lambda ^{nm}=1\).
At each of the \(nm\) sites \(v\) the inserted-site scalar extraction of Corollary 24.11.1.3 turns the two two-block proportionalities into the per-vertex gauge relation
where \(\widetilde B_v\) is the gauge action of \(X\) on \(B\) at \(v\). Contracting both sides over the whole torus pulls one factor of \(\lambda \) out of each of the \(nm\) sites, so the closed torus contractions of \(A\) and of \(\widetilde B\) satisfy
The single comparison region and its complement being injective makes this common torus contraction nonzero; by hypothesis the quotient \(c_S(v)/c_R(v)\) is the same scalar \(\lambda \) at every site, so \(\lambda ^{nm}=1\).
Let \(A\) and \(B\) be translationally invariant PEPS tensors on the discrete \(n\times m\) torus with \(n,m\geq 7\), both normal with injective rectangles (Definition 24.7.1.6), with positive physical dimension and equal bond dimensions, generating the same state. Let \(X\) and \(X'\) be two families of invertible matrices, one on each edge of the torus, and let \(e\) be an edge at which both families realize the absorbed inserted-coefficient equality: inserting any matrix on the edge \(e\) of \(A\) gives the same coefficient as inserting it on the edge \(e\) of the gauge-absorbed \(B\), for every physical configuration. Then the two families are proportional at \(e\): \(X'_e=c\cdot X_e\) for a nonzero scalar \(c\). This is the uniqueness clause of [ 220 , Theorem 3 ] read at one edge, at the source’s sizes \(n,m\geq 7\) as in Theorem 24.7.1.10; the source proves it through the determinacy of the conjugator in the isomorphism lemma, whose realizing matrix is unique up to a multiplicative constant.
The rectangle hypotheses produce, along the orientation class of \(e\), a comparison region having \(e\) as its single boundary edge on which the second tensor and its complement are injective; the union closure of injective regions follows from the nonzero bond spaces and Lemma 24.5.10. The bare-edge absorbed equality of each family lifts to the region inserted-coefficient identity over this region, with the inserted matrix conjugated by the orientation-adapted absorption of the family’s matrix at \(e\). The region-insertion transfer map is determined by this identity, so both orientation-adapted absorbing matrices induce the same conjugation on every bond matrix. Thus, for every bond matrix \(N\),
A matrix commuting with the full bond matrix algebra is a scalar multiple of the identity, so \(X'_{\mathrm{abs}}=c\, X_{\mathrm{abs}}\) for some \(c\ne 0\). Unwinding the orientation adaptation gives \(X'_e=c\cdot X_e\).
Let \(A\), \(B\), \(X\), \(X'\) be as in Theorem 24.7.1.12, with both families realizing the absorbed inserted-coefficient equality at every edge, and suppose moreover that both families are translation covariant: the matrix at any translate of an edge is the matrix at the edge, transposed-inverted exactly when the translation swaps the stored endpoint order. Then there are nonzero scalars \(c_h\) and \(c_v\) such that on every horizontal edge stored in the natural cyclic order (the stored second endpoint is the cyclic right neighbour of the first) \(X'_e=c_h\cdot X_e\), on every horizontal edge wrapping the seam (stored with swapped endpoints) \(X'_e=c_h^{-1}\cdot X_e\), and likewise on the vertical class with \(c_v\). The inversion on the seam is forced by the ordered-edge convention: the covariance carries the transposed inverse of the class matrix onto a seam edge, and the transposed inverse of a proportionality inverts its constant. A single constant on the whole class is therefore not the true statement in this convention; this is the class form of the uniqueness clause of [ 220 , Theorem 3 ] .
The constants are the per-edge scalars of Theorem 24.7.1.12 at the two reference edges. Every edge of a class is the translate of its reference edge by a unique translation \(\tau \). At an interior edge, covariance gives \(X_e=\tau \cdot X_{\mathrm{ref}}\), hence
At a seam edge, covariance gives \(X_e=(X_{\mathrm{ref}})^{-\top }\), hence
The marker \(e_{1,x}+1=e_{2,x}\) distinguishes the two branches, and the vertical class is identical with \(c_v\) in place of \(c_h\).
Let \(A\) and \(B\) be translationally invariant PEPS tensors on the discrete \(n\times m\) torus with \(n,m\geq 7\), both normal with injective rectangles (Definition 24.7.1.6), with positive physical dimension and equal bond dimensions, generating the same state. Suppose the families \(X\) and \(X'\) of invertible matrices, one on each edge, each realize the per-vertex relation of Theorem 24.7.1.10: at every site the tensor \(A\) equals \(\lambda \) (respectively \(\lambda '\)) times the gauge action of the family on \(B\), with \(\lambda ^{nm}=1\) (respectively \(\lambda '^{nm}=1\)). Then the two families are proportional at every edge: \(X'_e=c\cdot X_e\) for a nonzero scalar \(c\) depending on the edge. This is the uniqueness clause of [ 220 , Theorem 3 ] read against the displayed relation \(B=\lambda \cdot (X,Y)A\) itself, at the source’s sizes \(n,m\geq 7\).
The inserted-edge coefficient is multilinear in the site tensors, one factor per site, so the per-vertex relation scales every inserted coefficient by \(\lambda ^{nm}=1\): each family realizes the absorbed inserted-coefficient equality at every edge. Theorem 24.7.1.12 then gives the proportionality at each edge.
24.7.2 Overlapping-window corner cancellation
Let \(R\subseteq S\) be regions in a finite graph, and let \(C\) be a region insert on \(R\). Write \(\Phi _{R,S}\) for the coefficient obtained by contracting the added block \(S\setminus R\) between the boundary of \(R\) and the boundary of \(S\). The bare corner extension is
The normalized corner extension of \(C\) from \(R\) to \(S\) is the region insert
where \(P_{V\setminus S}\) is the product of bond dimensions over the edges not crossing the boundary of \(V\setminus S\). This is the open-boundary form of the extension used in the overlapping-window proof sketch of [ 220 , Section 4, proof of Theorem 3 ] .
If all bond dimensions are positive, then corner extension from \(R\subseteq S\) preserves the deformed region state: \(\Psi _{A,R,C}=\Psi _{A,S,\operatorname{Ext}_{R\subseteq S}(C)}\).
Expanding the deformed state on \(S\) separates the added block \(S\setminus R\) from the complement \(V\setminus S\). The corner-extension sum contracts the added block first, giving the pointwise identity
Assume the one-orientation \(L\times K\) window-injectivity hypotheses, union closure for injective regions, positive bond dimensions, and the bounds \(2\le L\), \(2\le K\), \(2L+1\le W\), and \(2K+1\le H\). Suppose two horizontally consecutive \(L\times K\) windows carry inserts \(C_1\) and \(C_2\) whose deformed states agree. Let \(U\) be their \((L+1)\times K\) union. Then their extensions to \(U\) agree:
Theorem 24.7.2.2 rewrites each single-window deformed state as the deformed state on \(U\) with the corresponding extended insert:
Since \(U\) is injective, equality of the two \(U\)-states implies equality of the two inserts:
Uniform interior-bond products for staircase windows.
For a PEPS tensor \(A\) and a region \(R\), write \(P_A(R)=\prod _{e\notin \partial R} D_A(e)\) for the product of bond dimensions over the non-boundary edges of \(R\).
Let \(\phi :G\simeq G'\) be an isomorphism of finite graphs, and let \(R\) be a region of \(G\). If \(A'\) is a PEPS tensor on \(G'\), then \(P_{A'}(\phi (R)) =\prod _{e\notin \partial R} D_{A'}(\phi (e))\).
An edge of \(\phi (R)\) is non-boundary exactly when its preimage is non-boundary for \(R\): \(e'\notin \partial \phi (R)\) if and only if \(\phi ^{-1}(e')\notin \partial R\). Reindexing the product over non-boundary edges by the edge bijection \(e\mapsto \phi (e)\) gives the stated equality.
Let \(A\) be translation invariant on a torus whose periods \(W,H\) satisfy \(1{\lt}W\) and \(1{\lt}H\). For every translation \(\tau _{a,b}\) and every region \(R\), one has \(P_A(\tau _{a,b}(R))=P_A(R)\).
Theorem 24.7.2.4 gives \(P_A(\tau _{a,b}(R)) =\prod _{e\notin \partial R}D_A(\tau _{a,b}(e))\). Translation invariance gives \(D_A(\tau _{a,b}(e))=D_A(e)\) for every edge \(e\), so the product is \(P_A(R)\).
Let \(A\) be translation invariant on a torus whose periods \(W,H\) satisfy \(1{\lt}W\) and \(1{\lt}H\). If \(Q(s;x,y)\) denotes the cyclic \(x\times y\) rectangle starting at \(s\), then for any starts \(s,s'\), \(P_A(Q(s;x,y))=P_A(Q(s';x,y))\).
If \(s=(s_x,s_y)\) and \(s'=(s'_x,s'_y)\), then the translation by \((s_x-s'_x,s_y-s'_y)\) carries one rectangle to the other: \(\tau _{s_x-s'_x,s_y-s'_y}(Q(s';x,y))=Q(s;x,y)\). Apply Theorem 24.7.2.5.
Let \(A\) be translation invariant on a torus whose periods \(W,H\) satisfy \(1{\lt}W\) and \(1{\lt}H\). If \(W_j\) and \(W_{j'}\) are two windows of the staircase based at the same corner \(s\) with window dimensions \(L\times K\), then \(P_A(W_j)=P_A(W_{j'})\).
Each staircase window is an \(L\times K\) cyclic rectangle: \(W_j=Q(s_j;L,K)\) and \(W_{j'}=Q(s_{j'};L,K)\). Theorem 24.7.2.6 gives \(P_A(Q(s_j;L,K))=P_A(Q(s_{j'};L,K))\).
Let \(B\) be translation invariant on a torus whose periods \(W,H\) satisfy \(1{\lt}W\) and \(1{\lt}H\). Assume the one-orientation \(L\times K\) window-injectivity hypotheses, union closure for injective regions, positive bond dimensions, and the bounds \(2\le L\), \(2\le K\), \(2L+1\le W\), and \(2K+1\le H\). Let \(j{\lt}L\), let \(U_j=W_j\cup W_{j+1}\) be the horizontal consecutive-window union, and let \(g\) be a boundary edge of both \(W_j\) and \(W_{j+1}\). If the matrices obtained from \(M_1\) and \(M_2\) by the orientation convention at \(g\) agree, then, with \(P_j=P_B(W_j)\),
The consecutive-window transport gives the cross-rescaled equality
By Theorem 24.7.2.7, \(P_B(W_{j+1})=P_B(W_j)=P_j\). Substituting this equality into (25) gives (24).
Let \(B\) be translation invariant on a torus whose periods \(W,H\) satisfy \(1{\lt}W\) and \(1{\lt}H\). Assume the one-orientation \(L\times K\) window-injectivity hypotheses, union closure for injective regions, positive bond dimensions, and the bounds \(2\le L\), \(2\le K\), \(2L+1\le W\), and \(2K+1\le H\). Let \(L\le j\) and \(j+1{\lt}L+K\), let \(U_j=W_j\cup W_{j+1}\) be the vertical consecutive-window union, and let \(g\) be a boundary edge of both \(W_j\) and \(W_{j+1}\). If the matrices obtained from \(M_1\) and \(M_2\) by the orientation convention at \(g\) agree, then, with \(P_j=P_B(W_j)\),
The descending-arm transport gives the same cross-rescaled equality as in the horizontal case, with \(U_j\) now the \(L\times (K+1)\) union:
The uniformity theorem gives \(P_B(W_{j+1})=P_B(W_j)=P_j\). Substituting this equality into (27) gives (26).
Assume positive bond dimensions and the bounds \(0{\lt}L\), \(0{\lt}K\), \(2L\le W\), and \(2K\le H\). If the deformed states of the two end-window inserts agree, then their extensions to the staircase patch \(P\) have equal deformed states:
Applying Theorem 24.7.2.2 to each end window gives
where the middle equality is the hypothesis.
Let \(B_1,K_1\subseteq V\setminus T\) and \(B_2,H_2\subseteq T\). Fix boundary data \(c_1\) on \(V\setminus K_1\) and \(c_2\) on \(H_2\), and physical labels \(\sigma _1\) on \(B_1\) and \(\sigma _2\) on \(B_2\). Set
Then the boundary-compatible double sum collapses to the multiplicity of the interior bonds of \(T\) times the single merged sum:
Each merged configuration has exactly \(P_T\) preimages, indexed by the virtual bonds strictly inside \(T\). Since \(B_1\) and \(K_1\) lie outside \(T\), while \(B_2\) and \(H_2\) lie inside \(T\), the two products and the two boundary conditions are unchanged under the merge.
For nested regions \(R\subseteq S\subseteq P\), the coefficient kernels satisfy
This is the two-block merge collapse in the proof of [ 220 , Section 4, proof of Theorem 3 ] .
The corner extension is linear in the inserted boundary coefficients. For nested regions \(R\subseteq S\subseteq P\), the bare extension satisfies
without a positivity assumption. If all bond dimensions are positive, the normalized corner extension is transitive:
The scalar and additive laws follow from the defining sum. For transitivity, substitute Theorem 24.7.2.12 into the defining sum. This gives the bare formula, and the factors \(P_{V\setminus S}\) cancel in the normalized extension.
If \(R\subseteq S\), a physical configuration on \(R\) and a physical configuration on \(S\setminus R\) combine into a physical configuration on \(S\):
The two restrictions recover the original configurations: \(\operatorname {As}_{R,S}(\sigma _R,\sigma _Q)|_R=\sigma _R\) and \(\operatorname {As}_{R,S}(\sigma _R,\sigma _Q)|_{S\setminus R}=\sigma _Q\).
Let \(R\subseteq S\) be finite regions. Suppose that all bond dimensions are positive and that the added block \(Q=S\setminus R\) is blocked-tensor injective. If a region insert \(C\) on \(R\) has zero corner extension, \(\operatorname{Ext}_{R\subseteq S}(C)=0\), then \(C=0\).
Since all bond dimensions are positive, \(P_{V\setminus S}\ne 0\). Thus \(\operatorname{Ext}_{R\subseteq S}(C)=0\) is equivalent to \(\overline{\operatorname{Ext}}_{R\subseteq S}(C)=0\). Fix the physical configuration \(\sigma _R\) on \(R\). Let \(\rho :\partial R \simeq \partial (V\setminus R)\) and \(\tau :\partial S \simeq \partial (V\setminus S)\) be the complement-boundary bijections, and define \(c_\eta =C_{\rho ^{-1}(\eta ),\sigma _R}\) for \(\eta \in \partial (V\setminus R)\). Evaluating the bare zero extension at \(\operatorname {As}_{R,S}(\sigma _R,\sigma _Q)\) gives, for every added-block configuration \(\sigma _Q\) and every boundary value \(\omega \in \partial (V\setminus S)\),
For each outer boundary value \(\omega \) and each boundary value \(\beta \) of \(Q\), define
Let \(\Gamma \) be the product of bond dimensions on the crossing edges separated when the \(Q\)-block is read first. Unfolding \(\Phi _{R,S}\) as a sum over the blocked weights of \(Q\) gives, for every \(\sigma _Q\),
Hence \(T_Q(f_\omega )=0\). Injectivity of the blocked tensor of \(Q\) gives \(T_Q(f_\omega )=0\Longrightarrow f_\omega =0\). Now fix \(\mu \in \partial R\). Positivity of bond dimensions gives a global virtual configuration \(q\) whose residual boundary on \(V\setminus R\) is \(\rho (\mu )\). Set \(\omega =\partial _{V\setminus S}q\) and \(\beta =\partial _Q q\). Evaluating \(f_\omega =0\) at \(\beta \), the residual-boundary uniqueness identity leaves only the term \(\eta =\rho (\mu )\):
Since \(\sigma _R\) and \(\mu \) were arbitrary, \(C=0\).
Let \(R\subseteq S\), and suppose that all bond dimensions are positive and that \(S\setminus R\) is blocked-tensor injective. If two inserts on \(R\) have the same corner extension to \(S\), \(\operatorname{Ext}_{R\subseteq S}(C_1)=\operatorname{Ext}_{R\subseteq S}(C_2)\), then \(C_1=C_2\).
By linearity, \(\operatorname{Ext}_{R\subseteq S}(C_1-C_2)=0\). Theorem 24.7.2.16 applied to the added block \(S\setminus R\) gives \(C_1-C_2=0\), hence \(C_1=C_2\).
Let the torus have width \(W\) and height \(H\), with \(1{\lt}W\) and \(1{\lt}H\). Let \(S\) be the staircase end pair around a horizontal edge, with seam dimensions \(L\) and \(K\), and let \(Q\) be the completed corner rectangle. Assume the size bounds \(2L\le W\) and \(2K\le H\), that \(Q\) is blocked-tensor injective, and that all bond dimensions are positive. If two inserts \(X\) and \(Y\) on \(S\) have equal extensions to \(S\cup Q\), \(\operatorname{Ext}_{S\subseteq S\cup Q}(X)=\operatorname{Ext}_{S\subseteq S\cup Q}(Y)\), then \(X=Y\). Thus the injective completed corner can be cancelled from an open-boundary equality, without assuming injectivity of the torus complement of \(S\).
The size bounds imply that the staircase end pair is disjoint from the completed corner, and therefore \((S\cup Q)\setminus S=Q\). The claimed equality is exactly Theorem 24.7.2.17 applied to the inclusion \(S\subseteq S\cup Q\).
24.7.3 Single-bond peeling and the window witness
In the staircase coordinates \(s=(a,b)\), the reference edge is the horizontal edge joining \((a+L-1,b+K-1)\) to \((a+L,b+K-1)\). It is the edge between the left and right end windows.
Assume \(1{\lt}W\), \(1{\lt}H\), \(0{\lt}L\), \(0{\lt}K\), \(1\le a\), \(a+2L\le W\), and \(b+2K-1\le H\). Then an edge crosses from the left end window to the right end window if and only if it is the reference edge \(e\):
Thus \(e\) is a boundary edge of each end window, but both endpoints of \(e\) lie in the end pair \(S\), so \(e\notin \partial S\).
The endpoint calculation identifies \(e\) with the unique horizontal edge joining the two displayed rectangles. Since one endpoint lies in \(W_{\mathrm{left}}\) and the other lies in \(W_{\mathrm{right}}\), the same edge is internal to their union \(S\).
Under the bounds \(1{\lt}W\), \(1{\lt}H\), \(0{\lt}L\), \(0{\lt}K\), \(1\le a\), \(a+2L\le W\), and \(b+2K-1\le H\), a boundary edge of the end pair is a boundary edge of one of the two end windows, and it is not the reference edge. Conversely, any boundary edge of one end window other than \(e\) is a boundary edge of \(S\).
A boundary edge of \(S\) has one endpoint in \(S\); that endpoint lies in one of the two end windows. The other endpoint is outside \(S\), hence outside that window. Conversely, a boundary edge of one window which is not \(e\) cannot enter the other window, because \(e\) is the unique crossing edge.
Under the bounds \(1{\lt}W\), \(1{\lt}H\), \(0{\lt}L\), \(0{\lt}K\), \(1\le a\), \(a+2L\le W\), and \(b+2K-1\le H\), an edge is a boundary edge of the staircase end pair \(S\) if and only if it is a boundary edge of one of the two end windows and is not the reference edge:
Moreover each edge in \(\partial S\) lies on exactly one of the two window boundaries.
Lemma 24.7.3.3 gives both implications. If an edge lay on both end-window boundaries, the unique-crossing theorem would identify it with \(e\), which is not a boundary edge of \(S\).
Under the same geometric bounds, write \(\partial _{\mathrm{left}}S\) and \(\partial _{\mathrm{right}}S\) for the boundary edges of \(S\) which lie on the corresponding end-window boundary. Then the boundary-configuration spaces have canonical factorizations
These equivalences preserve every underlying lattice-edge label. Thus the reference edge is the only contracted virtual index shared by the two highlighted end windows; every other virtual index remains on the corresponding open boundary of \(S\). The constructions split each end-window configuration at the reference edge and reindex the remaining dependent products along the corresponding boundary-edge identifications.
If \(2L\le W\), the complement of either end window splits as the opposite end window and the complement of the end pair:
Since the two end windows are disjoint and \(S=W_{\mathrm{left}}\cup W_{\mathrm{right}}\), removing one window from \(S\) leaves the other. Splitting \(V\setminus W\) through the inclusion \(W\subseteq S\) gives the displayed decompositions.
Let the torus have width \(W\) and height \(H\), with \(1{\lt}H\). Let \(e\) be the horizontal reference edge of a staircase window family with dimensions \(L,K\) and lower-left coordinate \((a,b)\). Suppose \(0{\lt}L\), \(0{\lt}K\), \(1\le a\), \(a+2L\le W\), and \(b+2K-1\le H\). Then \(e\) is a boundary edge of the first staircase window \(W_0\) and of the last staircase window \(W_{L+K-1}\):
The first staircase window is the right end window, and the last staircase window is the left end window:
The reference edge is a boundary edge of these two end windows by their defining geometry.
Let \(S=W_0\cup W_{L+K-1}\) be the staircase end pair. Suppose that the one-orientation \(L\times K\) window injectivity hypotheses hold for a tensor \(B\), unions of injective regions are injective, all bond dimensions of \(B\) are positive, and \(0{\lt}L\), \(0{\lt}K\), \(2L+1\le W\), and \(2K+1\le H\). If \(C_j\) are inserts on the staircase windows whose deformed states all equal one common state, then the two end-window inserts have equal corner extensions to \(S\):
The consecutive-window equalities are composed across the staircase patch. Both sides are then extended through the completed corner, and transitivity of corner extension rewrites the two extension chains. The completed corner is an injective \(L\times K\) window, so Theorem 24.7.2.18 cancels it and leaves the equality on the end pair \(S\).
Let \(K\) be the basis of the virtual space on the bond between two injective blocks, and let \(\{ A_{1,\mu }\} _{\mu \in K}\) and \(\{ A_{2,\mu }\} _{\mu \in K}\) be linearly independent families. Suppose that the two end physical operations \(O_1\) and \(O_3\) produce families \(C_1\) and \(C_2\) satisfying the open contraction identity
Then there is a unique matrix \(X\in M_{|K|}(\mathbb {C})\) such that
Thus the two end operations are obtained by inserting the same virtual operation \(X\) on their common bond. No injectivity is required of the modified families \(C_1\) and \(C_2\). This is the “compare the two ends” step in Lemma 5 of [ 220 ] .
Apply a dual functional to the linearly independent family \(\{ A_{2,\mu }\} \) in (31) to express \(C_{1,\nu }\) as a linear combination of the \(A_{1,\mu }\) with a coefficient matrix \(X\), yielding (32). Substitution into (31) and linear independence of \(\{ A_{1,\mu }\} \) yields (33) with the same matrix. Linear independence of \(\{ A_{1,\mu }\} \) also makes \(X\) unique.
Let \(\{ A_{1,\mu }\} _{\mu \in K}\) and \(\{ A_{3,\mu }\} _{\mu \in K}\) be two end families. The left physical operation \(O_1\) realizes a virtual matrix \(X\) when
The right physical operation \(O_3\), read in the transposed orientation \(O_3^{\mathsf T}\) of Lemma 5, realizes the same matrix when
This convention records the orientation of the displayed tensor relation; it does not choose a transpose on the abstract space of physical operations.
Suppose that the two genuine end families are linearly independent and that the open contraction identity for \(O_1\) and \(O_3\) holds. Then there is a unique matrix \(X\) simultaneously realized by \(O_1\) and by \(O_3^{\mathsf T}\).
If \(O_1\) and \(P_1\) realize \(X\) and \(Y\), respectively, then \(O_1\circ P_1\) realizes \(XY\). If \(O_3^{\mathsf T}\) and \(P_3^{\mathsf T}\) realize \(X\) and \(Y\), then their product realizes \(XY\); in terms of the underlying right operations this product is \(P_3\circ O_3\). Uniqueness identifies the virtual matrix of either composite with \(XY\). This is precisely the composition step in the final sentence of Lemma 5 of [ 220 ] ; it does not by itself identify operations belonging to two different PEPS tensors.
The two-end comparison gives existence and uniqueness of \(X\). Applying the first operation to the expansion furnished by the second and interchanging the two finite sums gives matrix multiplication. On the right, transposition reverses the order of the underlying physical operations.
Write the boundary coordinates of the two end windows and their union as
where \(k\) is the coordinate on the reference edge. In the extension of a left-window insert to the end pair, the normalized coupling to the right window vanishes unless \(\eta _{\mathrm L}=\eta '_{\mathrm L}\). On that fibre it is
where \(A_{\mathrm R}\) is the genuine blocked tensor of the right window and \(\Lambda _{\mathrm L}\) is the product of the exterior interior-bond factor and the bond dimensions on the external legs of the left window. The analogous statement holds after interchanging left and right. If the tensor is translation invariant and every bond dimension is positive, then \(\Lambda _{\mathrm L}=\Lambda _{\mathrm R}\).
The crossing edges are precisely the boundary edges of the host window other than the reference edge. Compatible host and end-pair boundary labels therefore determine one boundary label on the opposite window; the blue coupling reduces to its genuine blocked tensor. Incompatible external labels cannot arise from a global virtual configuration and give zero. Finally, the two end windows are translates. Translation invariance equates their full boundary products, and cancellation of the common positive reference-edge factor equates the two normalizations.
Let \(C_{\mathrm L}\) and \(C_{\mathrm R}\) be arbitrary inserts on the two end windows. In the boundary coordinates above, their extensions to the end pair are
Hence, for a translation-invariant tensor with positive bond dimensions, equality of the two extensions implies the single-bond identity
Reindex each extension sum by the reference-edge coordinate and the external boundary data. The normalized-coupling theorem kills every incompatible fibre and identifies the unique surviving fibre with the genuine opposite-window tensor. The common nonzero normalization then cancels from the equality of extensions.
Suppose the tensor is translation invariant, all bond dimensions are positive, and the two genuine highlighted end-window blocked tensors are injective. If arbitrary inserts \(C_{\mathrm L}\) and \(C_{\mathrm R}\) on those windows have equal extensions to the open end pair, then there is a unique matrix \(X\) on the reference edge such that
No injectivity is assumed for either modified insert, a single vertex, the end pair, or its complement. In particular, when the two inserts are obtained by applying the physical end operations \(O_1\) and \(O_3\), these relations say that \(O_1\) and \(O_3^{\mathsf T}\) realize the same unique matrix \(X\).
The preceding theorem turns the open end-pair equality into the exact one-bond contraction identity. Injectivity of each genuine end window implies linear independence after keeping its external boundary and physical coordinates together. The two-end comparison theorem then gives the displayed relations and uniqueness of \(X\).
Let the torus have width \(W\) and height \(H\). Suppose that the one-orientation \(L\times K\) window injectivity hypotheses hold for a tensor \(B\), unions of injective regions are injective, and all bond dimensions of \(B\) are positive. Assume
Let \(C_j\) be inserts on the staircase windows \(W_j\) whose deformed states all equal one common state. Suppose that \(C_0=I_{B,W_0,e,M}\) and \(C_{L+K-1}=I_{B,W_{L+K-1},e,M'}\). Then for every global physical configuration \(\sigma \),
Theorem 24.4.10 rewrites the two coefficients as the deformed states on the staircase end pair of the two corner-extended inserts:
The open-boundary equality on the staircase end pair gives \(\operatorname{Ext}_{W_0\subseteq S}(C_0) =\operatorname{Ext}_{W_{L+K-1}\subseteq S}(C_{L+K-1})\), and hence the two coefficients are equal.
Window-independence of the bond insertion.
Let \(\omega \) be a physical configuration on the full vertex set. If \(\omega _R\) and \(\omega _{V\setminus R}\) are its restrictions to \(R\) and to the complement, then \(\operatorname {Assemble}_R(\omega _R,\omega _{V\setminus R})=\omega \).
At a vertex in \(R\) the combined configuration reads \(\omega _R\), and at a vertex outside \(R\) it reads \(\omega _{V\setminus R}\). These restrictions are both inherited from \(\omega \), so the two configurations agree at every vertex.
Let \(R\) be a region, let \(f\) be a boundary edge of \(R\), let \(M\in M_{D_B(f)}(\mathbb {C})\), and let \(\omega \) be a physical configuration on the full vertex set. Then the assembled deformed state of the bond-inserted region insert is the non-boundary bond product times the corresponding edge-inserted coefficient:
Here \(p_B(R)=\prod _{g\notin \partial R}D_B(g)\), and \(\mathcal O_{R,f}\) is the boundary-edge orientation.
Theorem 24.4.8 rewrites the assembled deformed state as \(C_B(R,f,M;\omega _R,\omega _{V\setminus R})\). Theorem 24.4.9 gives
Lemma 24.7.3.16 identifies the combined configuration with \(\omega \).
Let \(R_1\) and \(R_2\) be two regions for which the same edge \(e\) is a boundary edge. Let \(M_1,M_2\in M_{D_B(e)}(\mathbb {C})\), and suppose that the two oriented insertions agree, \(\mathcal O_{R_1,e}(M_1)=\mathcal O_{R_2,e}(M_2)\). Then for every physical configuration \(\omega \) on the full vertex set,
Applying Theorem 24.7.3.17 to each of the two regions gives, for \(i=1,2\),
The oriented insertions are equal by hypothesis, so both sides of the claimed identity are \(p_B(R_1)p_B(R_2)\, E_B(e,\omega ,\mathcal O_{R_1,e}(M_1))\).
One virtual operation on every staircase window.
The construction below gives the forward virtual/physical-operation correspondence in the proof sketch of the two-dimensional corollary [ 220 , corollary after Lemma 5, lines 2297–2444 ] .
For a region \(R\) and a physical configuration \(\tau \) on its complement, define the partial state \(\psi ^\tau _{A,R}\) on the physical space of \(R\) by
If \(A\) and \(B\) generate the same closed state, then, for every region \(R\) and every complement configuration \(\tau \), \(\psi ^\tau _{A,R}=\psi ^\tau _{B,R}\).
Evaluate both functions at a physical configuration \(\sigma \) on \(R\) and apply the equality of the two closed-state coefficients at \(\omega _{R,\sigma ,\tau }\).
Let \(P_A(R)=\prod _{e\notin \partial R}D_A(e)\) be the product of the dimensions of all non-boundary bonds, both within \(R\) and within \(V\setminus R\). For every complement configuration \(\tau \),
Split the closed contraction across \(R\). If \(\mu \) and \(\nu \) are boundary labels on \(R\), the complement-boundary identification satisfies
Hence the double boundary sum collapses to its diagonal, which gives the sum in (34); each non-boundary bond contributes its dimension to the factor \(P_A(R)\).
Let \(R\) be an injective region and let \(C=\{ C(\mu )\} _{\mu \in \partial R}\) be any family in its physical space, indexed by the virtual boundary configurations. If \(L_{A,R}\) is a left inverse of the blocked tensor map, define
For every virtual boundary configuration \(\mu \),
Thus the insert is obtained from the genuine region block by one physical operator before the region is contracted with its complement.
The left inverse sends \(T_{A,R}(\mu )\) to the standard basis vector indexed by \(\mu \), and the displayed linear combination sends that basis vector to \(C(\mu )\).
Let \(O\) be a physical operator on the physical space of a region \(R\). Its action on the genuine open-boundary blocks defines the insert
For a complement physical configuration \(\tau \), let \(\psi ^\tau _{A,R}\) be the partial state across the cut. Then
If \(A\) and \(B\) generate the same closed state, then
The two virtual boundary spaces need not be identified.
Equality of the closed states gives \(\psi ^\tau _{A,R}=\psi ^\tau _{B,R}\). Apply (35) to both tensors and cross-multiply the two interior-bond products.
Let \(e=\{ u,w\} \) be an ordered edge whose two endpoints lie in a region \(R\), with \(u\) its ordered left endpoint, and let \(X\in M_{D_A(e)}(\mathbb {C})\). Write \(U=\{ u\} \) and let \(I_{A,U,e,X}\) be the boundary-bond insert on \(U\). The interior-bond insert on \(R\) is
Thus the genuine tensors at the vertices of \(R\setminus U\) are adjoined to a boundary insertion of \(X\) on \(e\), with the normalization changed from the non-boundary bond product of \(U\) to that of \(R\).
Suppose all bond dimensions are positive. For every global physical configuration \(\omega \),
Corner extension preserves the closed state. On the singleton \(U\), the boundary orientation is the identity because \(U\) contains the ordered left endpoint of \(e\). Hence its boundary insert has assembled state \(P_A(U)E_A(e,\omega ,X)\). The factor \(P_A(R)/P_A(U)\) cancels \(P_A(U)\) and gives (37).
Let \(e\) be the horizontal reference edge and let \(X\in M_{D_B(e)}(\mathbb {C})\). Define an insert \(C_j(X)\) on each staircase window \(W_j\), for \(0\le j{\lt}L+K\), by
The first window contains only the ordered right endpoint of \(e\), the middle windows contain both endpoints, and the remaining windows contain only the ordered left endpoint. The transpose in the first case makes all three boundary orientations represent the same matrix \(X\).
Suppose every \(L\times K\) window is injective. For every \(0\leq j{\lt}L+K\), there is a physical operator \(O_j(X)\) on the physical space of \(W_j\) such that
Hence the virtual operation is realized locally on each window, before any contraction with the complementary tensor network.
Each staircase window is an \(L\times K\) translate and is therefore injective. Apply the open-boundary realization theorem to \(C_j(X)\).
The end members of the family are
Let \(B\) be translation invariant and suppose all its bond dimensions are positive. Then for \(0\le j{\lt}L+K\) and every global physical configuration \(\omega \),
In particular, all \(L+K\) inserts have one common deformed state.
On \(W_0\), the boundary orientation sends \(X^{\mathsf T}\) to \(X\). On \(W_1,\ldots ,W_{L-1}\), apply the interior-bond identity. On the remaining windows the ordered left endpoint lies in the window, so the boundary orientation fixes \(X\). Each case gives \(P_B(W_j)E_B(e,\omega ,X)\). Translation invariance identifies \(P_B(W_j)\) with \(P_B(W_0)\).
Let \(L,K{\gt}0\), and choose staircase coordinates \((a,b)\) with \(a+2L\leq \mathrm{width}\) and \(2K\leq \mathrm{height}\). Let \(A\) and \(B\) be translation invariant tensors with the same physical dimension and the same closed state. Suppose every cyclic \(L\times K\) window of \(A\) is injective and \(D_A(g){\gt}0\) for every edge \(g\). For \(X\in M_{D_A(e)}(\mathbb {C})\), let \(O_j^A(X)\) be the physical operators obtained from the staircase insert family of \(A\), and define inserts on the windows of \(B\) by
Then, for all \(j,j'\in \mathbb {N}\),
The source family has \(0\leq j{\lt}L+K\). In the definition used here the truncated offsets stabilize at \(W_{L+K-1}\) for \(j\geq L+K-1\); the indices are not read modulo \(L+K\). No equality between the edge-dependent bond dimensions of \(A\) and \(B\), and no positivity assumption on those of \(B\), is required.
For each \(j\), (36) and the open-boundary realization of \(O_j^A(X)\) give
The staircase family of \(A\) has one common deformed state. Translation invariance gives \(P_A(W_j)=P_A(W_0)\) and \(P_B(W_j)=P_B(W_0)\). Hence the right-hand side is independent of \(j\). Positivity of the bond dimensions makes \(P_A(W_0)\) nonzero, so it may be cancelled.
For \(X\in M_{D_A(e)}(\mathbb {C})\), define \(O_1^A(X)=O_{L+K-1}^A(X)\) after identifying the last staircase window with the left end window.
For \(X\in M_{D_A(e)}(\mathbb {C})\), define \(O_3^A(X)=O_0^A(X)\) after identifying the first staircase window with the right end window. The relation (44) has the paper’s transposed \(O_3^{\mathsf T}\) orientation; no transpose is chosen on the abstract physical endomorphism space.
Let \(L,K{\gt}0\), and choose the displayed non-wrapping horizontal staircase coordinates \((a,b)\) with
Suppose that \(A\) and \(B\) are translation invariant, generate the same closed state, every cyclic \(L\times K\) window of either tensor is injective, and every bond dimension of either tensor is positive. For \(X\in M_{D_A(e)}(\mathbb {C})\), there is a unique \(Y\in M_{D_B(e)}(\mathbb {C})\) such that, for every external boundary configuration \(\eta _{\mathrm L}\) and \(\eta _{\mathrm R}\), and every reference-edge index \(k\),
Thus the relation (44) has the paper’s \(O_3^{\mathsf T}\) orientation. No equality between \(D_A(e)\) and \(D_B(e)\) is assumed or concluded, and this statement contains no multiplication or gauge assertion.
The transferred physical inserts form one common \(B\)-state. The overlapping-union lemma supplies the union closure needed to compare consecutive staircase windows, and corner completion gives equality of the two end inserts with open boundary. At the two ends these inserts are precisely the actions of \(O_3^A(X)\) and \(O_1^A(X)\) on the genuine \(B\)-window tensors. Injectivity of those two windows and the two-end comparison give the displayed relations and the uniqueness of \(Y\).
Let \(L,K{\gt}0\), and choose staircase coordinates \((a,b)\) with \(a+2L\leq \mathrm{width}\) and \(2K\leq \mathrm{height}\). Suppose every cyclic \(L\times K\) window of \(A\) is injective. For matrices \(X,Y\in M_{D_A(e)}(\mathbb {C})\), the canonical end operations satisfy
Thus the right relation preserves multiplication in ordinary order after passing to the orientation \((O_3^A)^{\mathsf T}\) used in Lemma 5.
Split the virtual boundary of either end window into the reference-edge coordinate and the remaining external coordinates. Let \(E\) be this splitting map, and write \(C_M\) for insertion of \(M\) on the reference edge. On every fixed external fibre,
The chosen left inverse of the injective blocked tensor is a left inverse on the whole boundary-coordinate space, so this identity gives \(O_W(M)O_W(N)=O_W(MN)\). The first window carries \(X^{\mathsf T}\); hence \((XY)^{\mathsf T}=Y^{\mathsf T}X^{\mathsf T}\) reverses the order of the underlying right operations.
Under the hypotheses of Theorem 24.7.3.36, in the paper’s notation the input and uniquely recovered matrices are called \(X\) and \(Y\). Writing \(Y_{A\to B}(X)\) only to distinguish the two tensor families, define
to be the unique matrix satisfying (43) and (44) for every left and right external boundary configuration. This definition makes no choice of an external boundary configuration.
Under the hypotheses of Theorem 24.7.3.36, for all \(X_1,X_2\in M_{D_A(e)}(\mathbb {C})\),
Set \(Y_r=Y_{A\to B}(X_r)\) for \(r=1,2\). For every left external boundary configuration, the two \(O_1\) relations compose in ordinary order:
For every right external boundary configuration, the underlying \(O_3\) operations compose in reverse order:
This is ordinary multiplication in the \(O_3^{\mathsf T}\) orientation. The preceding theorem identifies the left sides with the canonical operations for \(X_1X_2\). Both end relations therefore realize \(Y_1Y_2\), and global uniqueness identifies this product with \(Y_{A\to B}(X_1X_2)\).
Suppose the tensor is translation invariant and the staircase satisfies the stated size bounds. Then for every \(X\in M_{D_B(e)}(\mathbb {C})\) and every global physical configuration \(\omega \),
The region-to-edge identity sends both sides to the edge coefficient with \(X\) on the same reference edge: the first boundary orientation transposes \(X^{\mathsf T}\), while the last fixes \(X\). Translation invariance identifies the two non-boundary bond products.
The algebra isomorphism on the displayed staircase edge.
For \(f\in \partial R\), identify a boundary configuration \(\mu \) with \((\mu _f,\mu |_{\partial R\setminus \{ f\} })\). Denote the resulting bijection by \(E_f\).
For every exterior configuration \(\eta \) and every bond index \(j\),
In the defining sum, configurations agreeing away from \(f\) have the same exterior coordinate. The sum over that coordinate therefore reduces to \(\eta \).
An equality \(R=S\) identifies their physical and boundary spaces. Write \(O|_S\) and \(C|_S\) for a physical operation and a boundary-indexed physical tensor under these identifications.
If \(R=S\), then \(C^O_{A,R}|_S=C^{O|_S}_{A,S}\).
Identify \(R\) with \(S\) and evaluate both sides at a boundary configuration.
The image of the blocked tensor map on \(R\) is \(\operatorname {span}\{ T_{A,R}(\mu ):\mu \text{ a boundary configuration}\} \). If \(A\) and \(B\) generate the same closed state, both tensors are injective on \(V\setminus R\), and their bond dimensions are positive, these two images coincide.
The blocked tensor map sends a coefficient vector to the corresponding linear combination of the tensors \(T_{A,R}(\mu )\). Inverting the blocked tensor on the complementary region identifies this image with the span of the partial states of the closed state. Equality of the closed states then identifies the two images.
Under the equal-state, complement-injectivity, and positive-dimension hypotheses of Theorem 24.7.3.45, if \(OT_{A,R}(\mu )=PT_{A,R}(\mu )\) for every \(\mu \), then \(OT_{B,R}(\nu )=PT_{B,R}(\nu )\) for every \(\nu \).
By linearity, \(O\) and \(P\) agree on the span of the \(A\)-blocks. Every \(B\)-block belongs to the same span.
For every \(c\in \mathbb C\) and every boundary configuration \(\mu \), \(I_{A,R,f,M+N}=I_{A,R,f,M}+I_{A,R,f,N}\), \(I_{A,R,f,cM}=cI_{A,R,f,M}\), and \(I_{A,R,f,1}(\mu )=T_{A,R}(\mu )\).
Distribute the finite insertion sum over addition and scalar multiplication. For the identity matrix, the sum in (45) reduces to its \(i=j\) term.
If \(A\) is injective on \(R\) and \(V\setminus R\), and its bond dimensions are positive, then \(I_{A,R,f,M}=I_{A,R,f,N}\) implies \(M=N\).
Contract the two equal boundary-indexed tensors with the complementary blocked tensor. Their inserted coefficients coincide, so the inserted matrices coincide.
Let \(L,K{\gt}0\) and choose the non-wrapping staircase coordinates with \(1\leq a\), \(a+2L\leq \mathrm{width}\), \(b+2K-1\leq \mathrm{height}\), and \(2K\leq \mathrm{height}\). Suppose every \(L\times K\) window of \(A\) is injective. Then \(O_1^A(X)T_{A,W_{\mathrm L}}(\mu )=I_{A,W_{\mathrm L},e,X}(\mu )\) for every boundary configuration \(\mu \), and \(O_1^A(X+Y)=O_1^A(X)+O_1^A(Y)\), \(O_1^A(cX)=cO_1^A(X)\) for every \(c\in \mathbb C\).
Identify the last staircase window with \(W_{\mathrm L}\) and use its prescribed boundary insertion. The physical operator is the linear combination of that insertion followed by a fixed left inverse, so it preserves addition and scalar multiplication.
Let \(L,K{\gt}0\), \(1\leq a\), \(a+2L\leq \mathrm{width}\), and \(b+2K-1\leq \mathrm{height}\). Suppose that \(OT_{A,W_{\mathrm L}}(j,\eta )=\sum _i M_{ij}T_{A,W_{\mathrm L}}(i,\eta )\) for every \(j\) and every exterior boundary configuration \(\eta \). Then \(C^O_{A,W_{\mathrm L}}=I_{A,W_{\mathrm L},e,M}\). Injectivity of \(A\) is not required for this identity.
The staircase boundary bijection differs from \(E_e\) only by a bijection on the exterior coordinates. At the coordinates of any fixed boundary configuration, cancel that bijection and apply (45).
Under the hypotheses of Theorem 24.7.3.36, write \(F_{AB}(X)=Y_{A\to B}(X)\). For every boundary configuration \(\nu \), \(O_1^A(X)T_{B,W_{\mathrm L}}(\nu )=I_{B,W_{\mathrm L},e,F_{AB}(X)}(\nu )\). Moreover, for every pair of physical configurations \(\sigma ,\tau \),
The globally quantified left end relation gives the boundary insertion. Apply the same-state physical-operator identity to \(O_1^A(X)\) and substitute its two insertion realizations.
Let \(L,K{\gt}0\), \(2L+1\leq \mathrm{width}\), and \(2K+1\leq \mathrm{height}\). Suppose every cyclic \(L\times K\) window is injective and injectivity is closed under unions of two regions. The complement of any cyclic \(L\times K\) window is then injective.
The complement is the union of a full-height band of \(\mathrm{width}-L\geq L+1\) columns and an \(L\)-column band of \(\mathrm{height}-K\geq K+1\) rows. Each band is a union of translates of injective \(L\times K\) windows; union closure gives the result.
Under the hypotheses of Theorem 24.7.3.36, the assignment \(F_{AB}\) preserves addition, complex scalar multiplication, and the identity. It also satisfies \(F_{BA}(F_{AB}(X))=X\) for every \(X\in M_{D_A(e)}(\mathbb {C})\).
The realization identities and insertion injectivity give addition and scalar multiplication. The operation \(O_1^A(1)\) fixes every \(A\)-block, hence every \(B\)-block in their common image; insertion injectivity gives \(F_{AB}(1)=1\). For \(Y=F_{AB}(X)\), the operations \(O_1^B(Y)\) and \(O_1^A(X)\) agree on every \(B\)-block. They therefore agree on every \(A\)-block. Their two insertion realizations give \(F_{BA}(Y)=X\).
Under the hypotheses of Theorem 24.7.3.36, the algebra isomorphism \(M_{D_A(e)}(\mathbb {C})\to M_{D_B(e)}(\mathbb {C})\) is \(F_{AB}\), and its inverse is \(F_{BA}\).
Under the hypotheses of Theorem 24.7.3.36, the displayed horizontal bond satisfies \(D_A(e)=D_B(e)\).
The algebra isomorphism identifies the complex dimensions \(D_A(e)^2\) and \(D_B(e)^2\). The two nonnegative matrix sizes are therefore equal.
Under the hypotheses of Theorem 24.7.3.36, there are an identification \(h:D_A(e)=D_B(e)\) and an invertible matrix \(Z\in \mathrm{GL}(D_B(e),\mathbb C)\) such that, for every \(X\in M_{D_A(e)}(\mathbb {C})\) and every pair of physical configurations \(\sigma ,\tau \),
Here \(\iota _h\) identifies the two matrix algebras by \(h\), and \(P_A(W_{\mathrm L})\) is the product of the dimensions of all bonds outside the window boundary. These products are retained on both sides.
Skolem–Noether expresses \(F_{AB}(X)\) as \(Z\iota _h(X)Z^{-1}\). Substitute this expression into (46).
Let \(W\) be the left end window of a horizontal staircase with parameters \((L,K)\) and lower-left coordinate \((a,b)\), and let \(e\) be its reference edge. Suppose that
Then \(e\in \partial W\). Suppose also that the blocked tensors of \(B\) on \(W\) and \(V\setminus W\) are injective, that all bond dimensions of \(B\) are positive, and that the bond dimensions of \(A\) and \(B\) at \(e\) are identified by \(\iota _e:M_{D_A(e)}(\mathbb {C})\simeq M_{D_B(e)}(\mathbb {C})\). If \(Z\in \mathrm{GL}(D_B(e))\) satisfies, for every matrix \(M\) and physical configurations \(\sigma ,\tau \),
then these objects form the coefficient-identity witness at \(e\) with witness region \(W\) and with both gauge entries equal to \(Z\).
Let \(W\) be the left end window around the reference edge \(e\), placed with lower-left coordinate \((a,b)\). Suppose that every cyclic \(L\times K\) window of \(B\) is blocked-tensor injective, unions of injective regions are injective, all bond dimensions of \(B\) are positive, and
Suppose also that the bond dimensions of \(A\) and \(B\) at \(e\) are identified by \(\iota _e:M_{D_A(e)}(\mathbb {C})\simeq M_{D_B(e)}(\mathbb {C})\), and let \(Z\in \mathrm{GL}(D_B(e))\). If the conjugation identity
holds for every \(M,\sigma ,\tau \), then the coefficient-identity witness of Definition 24.7.3.57 is obtained for the region \(W\). The hypotheses supply the injectivity of both \(W\) and its complement at the minimal torus size.
Window realization and witness read-off.
Let \(B\) be a PEPS tensor on a torus whose periods \(W,H\) satisfy \(1{\lt}W\) and \(1{\lt}H\). Assume the one-orientation \(L\times K\) window-injectivity hypotheses for \(B\), union closure for injective regions, positive bond dimensions, and
Suppose also that
Let \(W_{\mathrm L}\) be the left end window and let \(e\) be the reference edge. If \(M,M'\in M_{D_B(e)}(\mathbb {C})\) satisfy
for every physical configuration \(\sigma \) on \(W_{\mathrm L}\) and \(\tau \) on \(V\setminus W_{\mathrm L}\), then \(M=M'\).
Let \(A\) and \(B\) be PEPS tensors on a torus whose periods \(W,H\) satisfy \(1{\lt}W\) and \(1{\lt}H\). Assume the one-orientation \(L\times K\) window-injectivity hypotheses for both tensors, union closure for injective regions for both tensors, positive bond dimensions, and \(2\le L\), \(2\le K\), \(1\le a\), \(a+2L\le W\), and \(b+2K-1\le H\), together with \(2L+1\le W\) and \(2K+1\le H\). Let \(W_{\mathrm L}\) be the left end window and let \(e\) be the reference edge. If \(T_e:M_{D_A(e)}(\mathbb {C})\to M_{D_B(e)}(\mathbb {C})\) is a region insertion transfer on \(W_{\mathrm L}\) at \(e\), then there exist \(Z,Z_{\mathrm{ref}}\in \mathrm{GL}(D_B(e))\) and a bond-dimension identification \(\iota _e:M_{D_A(e)}(\mathbb {C})\simeq M_{D_B(e)}(\mathbb {C})\) such that the coefficient-identity witness at \(e\) is nonempty. The coefficient identity has the form
The transfer determines a gauge \(Z\) by the region insertion algebra: \(T_e(M)=Z\, \iota _e(M)\, Z^{-1}\). Its coefficient-matching property gives (50). The window and complement injectivity hypotheses are those required by Definition 24.7.3.58, which yields the witness with \(Z_{\mathrm{ref}}=Z\).
Let \(A\) and \(B\) be PEPS tensors on a torus whose periods \(W,H\) satisfy \(1{\lt}W\) and \(1{\lt}H\). Assume the one-orientation \(L\times K\) window-injectivity hypotheses for both tensors, union closure for injective regions for both tensors, matched bond dimensions, equality of the PEPS state, positive bond dimensions, and \(2\le L\), \(2\le K\), \(1\le a\), \(a+2L\le W\), and \(b+2K-1\le H\), together with \(2L+1\le W\) and \(2K+1\le H\). Let \(W_{\mathrm L}\) be the left end window and let \(e\) be the reference edge. Suppose the endpoint tensor of each family at the in-region endpoint of \(e\) has linearly independent columns, and suppose the boundary matrix transfer is realized on \(W_{\mathrm L}\) in both directions. Then there exist \(Z,Z_{\mathrm{ref}}\in \mathrm{GL}(D_B(e))\) and a bond-dimension identification \(\iota _e:M_{D_A(e)}(\mathbb {C})\simeq M_{D_B(e)}(\mathbb {C})\) such that the coefficient-identity witness at \(e\) is nonempty.
The two realized boundary transfers determine a region insertion transfer:
Theorem 24.7.3.60 then gives the two gauges and the nonempty coefficient-identity witness.
Window witness from bond locality.
Let \(A\) and \(B\) be PEPS tensors on a torus whose periods \(W_{\mathrm{torus}},H_{\mathrm{torus}}\) satisfy \(1{\lt}W_{\mathrm{torus}}\) and \(1{\lt}H_{\mathrm{torus}}\). Assume the one-orientation \(L\times K\) window-injectivity hypotheses and union closure for both tensors, equality of the PEPS state, matched bond dimensions, positive bond dimensions, and \(2\le L\), \(2\le K\), \(1\le a\), \(a+2L\le W_{\mathrm{torus}}\), and \(b+2K-1\le H_{\mathrm{torus}}\), together with \(2L+1\le W_{\mathrm{torus}}\) and \(2K+1\le H_{\mathrm{torus}}\). Let \(W_{\mathrm L}\) be the left end window and let \(e\) be the reference edge. Suppose the \(A\)-to-\(B\) transfer kernel on \(W_{\mathrm L}\) at \(e\) is incident along the boundary leg \(e\). Then for every \(M\in M_{D_A(e)}(\mathbb {C})\) there is a matrix \(N\in M_{D_B(e)}(\mathbb {C})\) such that \(C_A(W_{\mathrm L},e,M;\sigma ,\tau ) =C_B(W_{\mathrm L},e,N;\sigma ,\tau )\) for every physical configuration \(\sigma \) on \(W_{\mathrm L}\) and \(\tau \) on \(V\setminus W_{\mathrm L}\).
The window hypotheses give injectivity of the blocked tensor maps on \(W_{\mathrm L}\) for \(A\) and \(B\), while union closure gives injectivity on the complements. For fixed \(M\), let \(K_M\) be the transfer kernel read from the \(B\)-blocked left inverses. The double-factorization theorem gives
The bond-local incident form supplies a matrix \(N\) such that
Substituting this form and summing over the matching residual boundary labels gives \(C_A(W_{\mathrm L},e,M;\sigma ,\tau ) =C_B(W_{\mathrm L},e,N;\sigma ,\tau )\).
Under the hypotheses of Theorem 24.7.3.62, suppose instead that the \(B\)-to-\(A\) transfer kernel on \(W_{\mathrm L}\) at \(e\) is incident along the boundary leg \(e\). Then for every \(N\in M_{D_B(e)}(\mathbb {C})\) there is a matrix \(M\in M_{D_A(e)}(\mathbb {C})\) such that \(C_B(W_{\mathrm L},e,N;\sigma ,\tau ) =C_A(W_{\mathrm L},e,M;\sigma ,\tau )\) for every physical configuration \(\sigma \) on \(W_{\mathrm L}\) and \(\tau \) on \(V\setminus W_{\mathrm L}\).
Apply the same coefficient-transfer lemma for bond-local kernels to the ordered pair \((B,A)\). Equivalently, the double-factorization theorem gives
while the \(B\)-to-\(A\) incident form gives a matrix \(M\) with
Substitution gives \(C_B(W_{\mathrm L},e,N;\sigma ,\tau ) =C_A(W_{\mathrm L},e,M;\sigma ,\tau )\).
Assume the hypotheses of Theorem 24.7.3.62 and its backward analog Theorem 24.7.3.63. Let \(T_e:M_{D_A(e)}(\mathbb {C})\to M_{D_B(e)}(\mathbb {C})\) be the coefficient transfer chosen from the forward theorem. If \(T_e(MM')=T_e(M)T_e(M')\) for all \(M,M'\in M_{D_A(e)}(\mathbb {C})\), then there exist \(Z,Z_{\mathrm{ref}}\in \mathrm{GL}(D_B(e))\) and a bond-dimension identification \(\iota _e:M_{D_A(e)}(\mathbb {C})\simeq M_{D_B(e)}(\mathbb {C})\) such that a coefficient-identity witness at \(e\) is nonempty. Thus the witness contains a region \(R\) with \(e\in \partial R\), and for every \(M\in M_{D_A(e)}(\mathbb {C})\) and every physical configuration \(\sigma \) on \(R\) and \(\tau \) on \(V\setminus R\), the coefficient identity has the form
The two bond-locality hypotheses give the forward and backward coefficient transfers by Theorems 24.7.3.62 and 24.7.3.63. With this multiplicativity, Theorem 24.4.34 gives a conjugating gauge \(Z\) for the forward transfer. The window and complement injectivity hypotheses then yield a nonempty coefficient-identity witness with \(Z_{\mathrm{ref}}=Z\).
24.7.4 Both edge directions and reference witnesses
The coordinate exchange \(S(x,y)=(y,x)\) is a graph isomorphism from the \(w\times h\) torus to the \(h\times w\) torus. Its inverse is the coordinate exchange in the opposite direction.
Coordinate exchange sends the cyclic \(L\times K\) rectangle starting at \((x,y)\) to the cyclic \(K\times L\) rectangle starting at \((y,x)\), and sends the right edge at \((x,y)\) to the up edge at \((y,x)\). It intertwines translation by \((a,b)\) with translation by \((b,a)\). Consequently, translation invariance and injectivity of every cyclic \(L\times K\) window are preserved, with the side lengths exchanged.
Membership in the two coordinate arcs is exchanged. Graph transport preserves regional injectivity. The identity \(S\circ t_{a,b}=t_{b,a}\circ S\) and composition of graph transports give translation invariance of the transported tensor.
Let \(A\) and \(B\) be translation-invariant PEPS tensors on the \(w\times h\) torus with the same contracted state, both normal at window size \(L\times K\) (Definition 24.7.5.2), where \(L,K{\gt}0\), \(2L+1\leq w\), and \(2K+1\leq h\). Then \(D_A(e)=D_B(e)\) at every edge \(e\).
Apply the staircase bond-dimension comparison to a horizontal reference edge. Apply it again after coordinate exchange, with the side lengths \(K,L\), to obtain equality at a vertical reference edge. Translation invariance makes the bond dimension constant within each orientation, so these two comparisons determine every edge dimension. No equality of non-boundary bond products is assumed.
Let \(A,B\) be translation-invariant tensors on a torus with \(w,h{\gt}2\), matched bond dimensions, and positive bond dimensions for \(A\). Let \(e_{\mathrm h}\) and \(e_{\mathrm v}\) be distinguished horizontal and vertical edges. Suppose that at each of these edges there is a coefficient-identity witness: its region and complement are injective for \(B\), all bond dimensions of \(B\) are positive, and its two invertible matrices \(Z,Z_{\mathrm{ref}}\) satisfy \(C_A(R,e,M;\sigma ,\tau )=C_B(R,e,Z M Z^{-1};\sigma ,\tau )\) for both choices \(Z\) and \(Z_{\mathrm{ref}}\), all matrices, and all physical configurations, after identifying the matched matrix sizes. Require that the first stored endpoint of each distinguished edge belongs to its witnessing region. Then there is a translation-covariant family of invertible edge matrices \(X_e\) such that, for every edge \(e\), global physical configuration \(\sigma \), and matrix \(M\),
Here \(X\cdot B\) denotes the tensor obtained by the edge gauges, and the matrix on the right is identified by the matched bond dimensions. The witnessing regions need not be rectangles.
Translate the horizontal witness to each horizontal edge and the vertical witness to each vertical edge. Absorb the gauge on each witnessing boundary into the tensor \(B\). The translation reaching an edge is unique when \(w,h{\gt}2\); composition of translations therefore gives covariance of the resulting family. If the stored endpoint order is reversed, the absorbed matrix is replaced by its transposed inverse. The translated coefficient identity gives the displayed bare-edge identity at each edge.
24.7.5 Unscaled coefficients and the normal-window gauge
For a family \(\mathcal I\) of regions in the \(w\times h\) torus, the \(L\times K\) cyclic-window hypothesis means that \(\mathcal R(s;L,K)\in \mathcal I\) for every starting vertex \(s\). Here \(\mathcal R(s;a,b)\) is the cyclic rectangle of side lengths \(a,b\) starting at \(s\). For a tensor, \(\mathcal I\) is its family of injective regions. This is the window hypothesis in the normal TI PEPS corollary of [ 220 ] .
A PEPS tensor on the \(w\times h\) torus is normal at window size \(L\times K\) when its family of injective regions satisfies the \(L\times K\) cyclic-window hypothesis. As throughout, its virtual bond spaces are nonzero. Injectivity does not force this: with suitably placed zero-dimensional bonds every relevant local domain is empty, so the regions are injective and every state is zero. This is the hypothesis on each tensor in the normal TI PEPS corollary of [ 220 ] .
Under the displayed horizontal staircase hypotheses of Theorem 24.7.3.36, let \(W\) be the left end window and \(e\) its highlighted boundary edge. For every \(X\in M_{D_A(e)}(\mathbb {C})\) and physical configurations \(\sigma ,\tau \),
Equality of all edge dimensions identifies \(P_A(W)=\prod _{g\notin \partial W}D_A(g)\) with \(P_B(W)\). The normalized comparison is \(P_B(W)C_A(W,e,X)=P_A(W)C_B(W,e,F_{AB}(X))\). Positivity of every bond dimension makes their common product nonzero; cancellation gives (52).
Under the same hypotheses, the region-insertion transfer on \((W,e)\) has forward map \(F_{AB}\) and reverse map \(F_{BA}\). Its coefficient identities are (52) and the corresponding identity with \(A,B\) exchanged; the forward map preserves products and the identity.
Use the canonical assignments in both directions. Their coefficient identities follow from the preceding theorem and their algebraic laws follow from the staircase algebra isomorphism.
Under the same hypotheses, any assignment \(T\) satisfying \(C_A(W,e,X;\sigma ,\tau )=C_B(W,e,T(X);\sigma ,\tau )\) for every matrix and physical configuration is \(T=F_{AB}\).
Both assignments have the same inserted coefficients for \(B\). Injectivity of \(B\) on \(W\) and \(W^c\), with positive bond dimensions, makes the inserted-coefficient map injective. Hence \(T(X)=F_{AB}(X)\) for each \(X\).
Under the same hypotheses, \(D_A(e)=D_B(e)\) and there is an invertible matrix \(Z\) on this bond such that for every matrix and physical configuration,
Equal dimensions identify the matrix coordinates on the two sides.
Skolem–Noether gives \(F_{AB}(X)=ZXZ^{-1}\). Substitute this identity into (52).
Under the displayed horizontal staircase hypotheses, the highlighted edge has a coefficient-identity witness whose region is the left end window and contains the first stored endpoint of the edge.
The unscaled conjugating gauge and the normal-window injectivity give the witness. The non-wrapping right-edge endpoint formula identifies its first endpoint with the vertex in the left window.
Let \(A,B\) be translation-invariant PEPS tensors on a \(w\times h\) torus with the same state, both normal at window size \(L\times K\), where \(L,K{\gt}0\), \(2L+1\leq w\) and \(2K+1\leq h\). Then their bond dimensions agree and there are a translation-covariant invertible edge gauge family \(X\) and \(\lambda \in \mathbb C\) such that
The first identity holds at every vertex, after identifying equal bond dimensions. This is the existence and normalization part of the normal translation-invariant PEPS corollary of [ 220 ] .
First identify the bond dimensions. Place the horizontal staircase at \((1,0)\) and use coordinate exchange to obtain a vertical witness. Translating these two witnesses gives the covariant gauge family with equal absorbed edge coefficients. The corner-region scalar comparison then proves (54) and (55).
Let \(A,B\) be translation-invariant PEPS tensors generating the same state on an \(n\times m\) torus, both normal at window size \(L\times K\), where \(L,K{\gt}0\), \(n\geq 2L+1\) and \(m\geq 2K+1\). Then their bond dimensions agree and there are invertible horizontal and vertical gauges \(X,Y\) and a scalar \(\lambda \) such that
The matrices \(X,Y\) are unique up to nonzero scalar factors. This is the normal translation-invariant PEPS corollary of [ 220 ] . The displayed relation abbreviates the horizontal and vertical virtual-leg contractions. In the chosen torus edge orientations, the corresponding edge gauge family is translation covariant; seam reversals replace a matrix by its transposed inverse.
The existence theorem gives the covariant edge family and the site scalar. Its values at a horizontal and vertical reference edge are \(X,Y\). Any competing local gauge relation has site scalar \(\lambda '\); injectivity on a corner region and its complement makes the torus state nonzero, so equality of states forces \((\lambda ')^{nm}=1\). The minimal-window uniqueness theorem then makes the competing matrices proportional at every edge, in particular at the two reference edges.
24.7.6 Transport and the vertical reference edge
Let \(\phi :G\simeq G'\) and \(\psi :G'\simeq G''\) be graph isomorphisms between graphs with linearly ordered vertex sets. For every edge \(e\) of \(G\), one has \(\psi (\phi (e))=(\psi \circ \phi )(e)\). For every tensor \(A\) on \(G\), one also has \((A^\phi )^\psi =A^{\psi \circ \phi }\).
Both edge maps send the endpoint pair of \(e\) to the same pair. At a vertex \(z\), both transported tensors read the component of \(A\) at \(\phi ^{-1}(\psi ^{-1}(z))\). The incident-edge bijections compose, and the identifications of equal bond spaces compose with them. Thus the local components agree at every physical and virtual index.
Let \(\phi \) be a graph isomorphism between two tori whose side lengths exceed one, and let \(A'=A^\phi \) and \(B'=B^\phi \). Let \(e\) be an edge of the original torus and put \(f=\phi (e)\). Write \(e_-\) and \(f_-\) for their first endpoints in the chosen edge ordering, and assume \(\phi (e_-)=f_-\). Suppose \(f\in \partial R'\), \(f_-\in R'\), all bond dimensions of \(B'\) are positive, and \(B'\) is injective on \(R'\) and \((R')^c\). Suppose also \(D_{A'}(f)=D_{B'}(f)\) and there is an invertible matrix \(Z\) such that
for every inserted matrix \(M\) and every physical configuration on \(R'\) and its complement, after identifying the equal bond spaces. Then \(R=\phi ^{-1}(R')\) has \(e\in \partial R\) and \(e_-\in R\); all bond dimensions of \(B\) are positive, \(B\) is injective on \(R\) and \(R^c\), and \(D_A(e)=D_B(e)\). There is an invertible matrix \(Y\) such that
for every inserted matrix \(N\) and every physical configuration on \(R\) and its complement, with the equal bond spaces identified.
Transport the configurations in (58) to \(R'\) and apply (57). Carrying \(Z\) back to the bond of \(e\) gives \(Y\); this identification preserves multiplication and inversion, so it carries conjugation by \(Z\) to conjugation by \(Y\). Injectivity of both regions and positivity of every bond dimension are preserved by the inverse graph isomorphism. Finally, \(\phi (e_-)=f_-\in R'\) implies \(e_-\in \phi ^{-1}(R')\).
Let \(A,B\) be translation-invariant tensors on the \(w\times h\) torus, with positive bond dimensions and the same contracted state. Suppose every cyclic \(L\times K\) window is injective for each tensor, where \(L,K{\gt}0\), \(2L+1\leq w\) and \(2K+1\leq h\). Then there exist a vertical edge \(e\), a region \(R\), and an invertible matrix \(Y\) such that \(D_A(e)=D_B(e)\), \(e\in \partial R\), \(e_-\in R\), and \(B\) is injective on \(R\) and \(R^c\). They satisfy (58) for every inserted matrix and every physical configuration on the two regions. This is the vertical reference construction in the two-dimensional argument of [ 220 ] .
Exchange the coordinates and apply the horizontal construction with window lengths \(K,L\), at placement \((1,0)\). The size bounds give \(1+2K\leq h\) and \(2L-1\leq w\), so this placement satisfies the required inequalities. The distinguished right edge is based at \((K,L-1)\) in the exchanged torus. Its inverse image is the upward edge based at \((L-1,K)\) in the original torus. Since \(K+1{\lt}h\), neither edge crosses a coordinate seam, and coordinate exchange preserves the first endpoint in the chosen edge ordering. Pull the horizontal identity and its injective regions back by Theorem 24.7.6.2.
24.7.7 Corner comparison at the minimal torus sizes
Let \(\mathcal I\) be closed under finite nonempty unions and satisfy the \(L\times K\) cyclic-window hypothesis, where \(L,K{\gt}0\). If \(L\leq a\leq w\) and \(K\leq b\leq h\), then \(\mathcal R(s;a,b)\in \mathcal I\) for every \(s\).
The enlarged rectangle is the union of its \(L\times K\) windows whose starting displacements range over \(\{ 0,\ldots ,a-L\} \times \{ 0,\ldots ,b-K\} \). This index set is nonempty. Apply closure under finite unions.
For \(a{\lt}w\) and \(b{\lt}h\), the complement of \(\mathcal R(s;a,b)\) is
A vertex outside the rectangle either has its first coordinate outside the cyclic interval of length \(a\), or has its first coordinate inside that interval and its second coordinate outside the interval of length \(b\). These are precisely the two rectangles in (59).
Write \({\lbrack a,b)}\) for the vertices whose chosen coordinate values lie between \(a\) and \(b-1\). Define
These are the one-site comparison regions in the final argument of [ 220 , proof of Theorem 3 ] , with arbitrary positive window lengths.
Membership in \(R\) is given by the two coordinate conditions in (60). If \(2L+1\leq w\) and \(2K+1\leq h\), then a vertex is \(v_0\) exactly when its coordinate values are \((L,K)\); furthermore \(v_0\notin R\) and \(R\cup \{ v_0\} =S\). For \(L,K{\gt}0\), the complement identity is
The coordinate inequalities defining \(R\) leave out exactly \((L,K)\) from \(S\). The rectangle added in (61) intersects \(S\) only at this corner; every other point of that rectangle lies in \(S^c\). Expanding the coordinate inequalities proves all assertions.
Let \(\mathcal I\) be closed under finite nonempty unions and satisfy the \(L\times K\) cyclic-window hypothesis. If \(L,K{\gt}0\), \(2L+1\leq w\) and \(2K+1\leq h\), then \(R,S,R^c,S^c\in \mathcal I\).
The two rectangles defining \(R\) have side lengths \(L\times (K+1)\) and \((L+1)\times K\); \(S\) has side lengths \((L+1)\times (K+1)\). Each contains a full window. Formula (59) writes \(S^c\) as two cyclic rectangles of side lengths \((w-L-1)\times h\) and \((L+1)\times (h-K-1)\). The size bounds give \(w-L-1\geq L\) and \(h-K-1\geq K\), so these rectangles also contain full windows. Finally apply (61) and union closure to \(R^c\).
If \(w,h{\gt}1\), \(K{\gt}0\), \(2L+1\leq w\) and \(2K+1\leq h\), the upward edge from \((L,K)\) crosses \(R\), and the upward edge from \((L,K-1)\) crosses \(S\).
The first edge starts outside \(R\) and ends at \((L,K+1)\in R\). The second starts below \(S\) and ends at \((L,K)\in S\). The size bounds ensure that neither edge crosses a coordinate seam.
If \(\phi \) is a graph isomorphism, the transported tensor is injective on \(\phi (R)\) exactly when the original tensor is injective on \(R\). Replacing bond dimensions by equal dimensions also preserves injectivity on \(R\). For a translation-invariant tensor, every translated region has the same injectivity property.
The boundary and physical configurations are identified by bijections. The corresponding blocked tensor families therefore differ by invertible linear changes of coordinates, which preserve linear independence.
Let \(A,B\) be tensors on a finite graph with matched bond dimensions, and put \(C=X\cdot B\) for an invertible edge gauge family \(X\). Suppose \(A\) and \(C\) are injective on both \(Q\) and \(Q^c\), the boundary of \(Q\) is nonempty, and \(C_A(e,M;\sigma )=C_C(e,M;\sigma )\) for every edge, inserted matrix and global physical configuration. Then \(A_Q=c_Q C_Q\) for some \(c_Q\ne 0\).
The bare-edge equality gives equality of the region-inserted coefficients on each boundary edge of \(Q\). The injective two-block comparison gives reciprocal nonzero proportionalities on \(Q\) and \(Q^c\); retain the first.
Let \(w,h{\gt}1\), let \(A,B\) be translation invariant on the torus with matched bond dimensions, and let \(X\) be a translation-covariant invertible edge gauge family. Put \(C=X\cdot B\). If \(A_Q=c C_Q\), then \(A_{tQ}=c C_{tQ}\) for every translation \(t\).
Translation gives bijections of the boundary and physical configurations. Translation invariance of \(A,B\) and covariance of \(X\) identify their blocked weights under these bijections, retaining the same factor \(c\).
Under the translation and gauge hypotheses of Theorem 24.7.7.9, assume positive bond dimensions of \(A\), injectivity of \(B\) on \(Q\), and \(v_0\notin Q\). If \(A_Q=c_Q C_Q\) and \(A_{Q\cup \{ v_0\} }=c_S C_{Q\cup \{ v_0\} }\), where \(c_Q\ne 0\), then \(A_v=(c_S/c_Q)C_v\) at every vertex \(v\).
Choose the translation \(t(v_0)=v\). The two block proportionalities transfer to \(tQ\) and \(tQ\cup \{ v\} \) with the same \(c_Q,c_S\). Injectivity of \(B\) transfers to \(tQ\) and is preserved by the gauge and the identification of bond dimensions. The inserted-site scalar comparison therefore gives \(A_v=(c_S/c_Q)C_v\).
Let \(w,h{\gt}1\), and suppose \(A,B\) generate the same torus state, have matched bond dimensions, and have positive bond dimensions for \(A\). Suppose \(A\) is injective on \(Q\) and \(Q^c\) for some \(Q\). If an invertible edge gauge family \(X\) satisfies \(A_v=\lambda (X\cdot B)_v\) at every vertex, then \(\lambda ^{wh}=1\).
Injectivity on \(Q\) and \(Q^c\) gives a nonzero state coefficient. Gauge cancellation preserves the closed state, while multiplying each site tensor by \(\lambda \) multiplies it by \(\lambda ^{wh}\). Equality of the states therefore gives \(\lambda ^{wh}=1\).
Let \(A,B\) be translation-invariant tensors on a \(w\times h\) torus, with positive matched bond dimensions, generating the same state. Suppose every cyclic \(L\times K\) window is injective for each tensor, where \(L,K{\gt}0\), \(2L+1\leq w\) and \(2K+1\leq h\). Let \(X\) be an invertible translation-covariant edge gauge family for which \(C_A(e,M;\sigma )=C_{X\cdot B}(e,M;\sigma )\) for all edges, matrices and global physical configurations. Then there is \(\lambda \in \mathbb C\) such that
Positive bonds give union closure of injectivity for both tensors. Thus \(R,S,R^c,S^c\) from (60) are injective. Gauge transformation and identification of bond dimensions preserve these facts for \(X\cdot B\). Both comparison regions have boundary edges, so the absorbed identities give \(A_R=c_R(X\cdot B)_R\) and \(A_S=c_S(X\cdot B)_S\) with \(c_R\ne 0\). Since \(S=R\cup \{ v_0\} \), translation of this comparison yields the same ratio \(\lambda =c_S/c_R\) at every site. The volume-power theorem gives \(\lambda ^{wh}=1\).
24.7.8 Gauge uniqueness from injective windows
Let \(w,h{\gt}1\), let \(A,B\) have matched bond dimensions on the torus, and let \(X\) be an invertible edge gauge family. If \(A_v=\lambda (X\cdot B)_v\) at every vertex and \(\lambda ^{wh}=1\), then \(C_A(e,M;\sigma )=C_{X\cdot B}(e,M;\sigma )\) for every edge, inserted matrix and global physical configuration, after identifying the equal bond dimensions.
The product of the local tensor weights in an inserted-edge coefficient acquires one factor of \(\lambda \) at each vertex. Thus \(C_A(e,M;\sigma )=\lambda ^{wh}C_{X\cdot B}(e,M;\sigma )\), and the volume-power hypothesis removes this factor.
Let \(w,h{\gt}1\), and let \(A,B\) have matched bond dimensions, positive for \(B\). Let \(Q\) and \(Q^c\) be injective for \(B\), and let \(e\in \partial Q\). Suppose two invertible edge gauge families \(X,X'\) both satisfy \(C_A(e,M;\sigma )=C_{X\cdot B}(e,M;\sigma )\) at this edge, with the second family substituted for the first as well, for every \(M,\sigma \). Then \(X'_e=cX_e\) for some \(c\in \mathbb C^\times \).
Each absorbed identity determines a conjugation-form region-insertion identity on \(Q\). Injectivity on \(Q\) and \(Q^c\) identifies the two inner automorphisms. Their conjugating matrices differ by a nonzero scalar, since the commutant of the full matrix algebra consists of scalar matrices. Restoring the stored endpoint convention transposes or inverts both matrices; the resulting proportionality constant is \(c\) or \(c^{-1}\).
Let \(w,h{\gt}1\), and let \(B\) be a translation-invariant tensor on the torus that is normal at window size \(L\times K\) (Definition 24.7.5.2). Assume \(L,K{\gt}0\), \(2L+1\leq w\) and \(2K+1\leq h\). Let \(A\) have the same bond dimensions as \(B\), and suppose two invertible edge gauge families \(X,X'\) satisfy
Then for every edge \(e\) there is a nonzero scalar \(c_e\) such that \(X'_e=c_eX_e\). This gives the uniqueness of the two directional matrices in [ 220 , normal TI PEPS corollary ] by taking one horizontal and one vertical reference edge. For covariant families, these reference comparisons determine all translates, with inverse scalar on edges whose stored endpoint order is reversed.
Use the punctured rectangle \(R\) and omitted vertex \(v_0=(L,K)\) from (60). Both \(R\) and \(R^c\) are injective. The rightward and upward edges from \(v_0\) cross \(R\): their other endpoints are \((L+1,K)\) and \((L,K+1)\), respectively, both belonging to \(R\). Every horizontal or vertical edge is a translate of the corresponding reference edge. Translate \(R\) to place the chosen edge on its boundary; translation invariance of \(B\) preserves the two injectivity statements. Formula (63) gives both absorbed insertion identities. The injective-region uniqueness theorem then gives the required scalar \(c_e\).
24.7.9 Complements and staircase comparisons for positive windows
Let \(\mathcal I\) be a family of torus regions closed under unions, containing every cyclic \(L\times K\) window. Assume \(L,K{\gt}0\), \(2L+1\leq w\) and \(2K+1\leq h\). Then \(\mathcal R(s;L+1,K)^c\in \mathcal I\) for every starting vertex \(s\). In particular, this conclusion applies to blocked-tensor injectivity.
The complement is the union of a full-height band with \(w-L-1\geq L\) columns and an \((L+1)\)-column band with \(h-K\geq K\) rows. Each band is a union of cyclic \(L\times K\) windows, so each belongs to \(\mathcal I\). Apply union closure.
Under the same hypotheses, \(\mathcal R(s;L,K+1)^c\in \mathcal I\) for every \(s\). In particular, this conclusion applies to blocked-tensor injectivity.
The complement is the union of a full-height band with \(w-L\geq L\) columns and an \(L\)-column band with \(h-K-1\geq K\) rows. Both bands are unions of injective windows.
Let \(B\) have positive bond dimensions and injective cyclic \(L\times K\) windows, with union closure for injective regions. Assume \(L,K{\gt}0\), \(2L+1\leq w\) and \(2K+1\leq h\). Write \(W_j\) for the staircase windows and \(U_j=W_j\cup W_{j+1}\). If \(j{\lt}L\) and inserts \(C_j,C_{j+1}\) have the same deformed state, then
The equality of deformed states is an equality at every physical configuration on the torus.
The union \(U_j\) is a cyclic \((L+1)\times K\) rectangle, so its complement is injective. Corner extension preserves the deformed state, giving equal states for the two extended inserts on \(U_j\). Injectivity of \(U_j^c\) makes contraction against the complement injective and hence gives (64).
Under the same tensor and size hypotheses, if \(L\leq j\) and \(j+1{\lt}L+K\), equality of the deformed states of \(C_j,C_{j+1}\) again implies (64).
Here \(U_j\) is a cyclic \(L\times (K+1)\) rectangle. Its complement is injective, and the same contraction argument applies.
Under the same hypotheses, let \(P\) be the staircase patch. For \(j+1{\lt}L+K\), equality of the deformed states of two consecutive inserts implies
Under the same hypotheses, suppose inserts \(C_j\) on the staircase windows have one common deformed state for \(0\leq j{\lt}L+K\). Then for each \(n{\lt}L+K\),
In particular, the extensions of the two end-window inserts agree, by taking \(n=L+K-1\). These comparisons implement the overlapping-window argument of [ 220 ] for every positive pair \(L,K\).
Induct on \(n\). The case \(n=0\) is immediate. At the induction step, the common-state hypothesis gives equality of the states on \(W_n\) and \(W_{n+1}\). Apply (65) and compose it with the induction hypothesis.
24.8 Normal PEPS Fundamental Theorem
For a normal PEPS, the tensors become injective after blocking around every edge, and each site separates two injective regions whose complements are also injective. With union closure in hand, these hypotheses yield the Fundamental Theorem for normal PEPS (Theorem 24.8.7) on a connected graph [ 220 , Section 4 ] , with gauges unique modulo balanced edge scalars. Corollaries specialize the result to closed chains, translation-invariant matrix product states, and the square lattice.
The general normal theorem assumes both the edge-centred blockings into three injective regions and the one-site comparison regions with injective complements. These two assumptions are collected as the normal PEPS blocking hypotheses; the same hypotheses give the corresponding edge and one-site consequences without restating the separate edge and one-site assumptions. The following two panels show their square-lattice source realization; they do not restrict the abstract definition to this lattice.
\(\qquad \text{edge blocking}\) 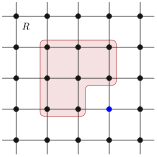 \(\qquad \subset \qquad \)
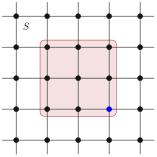 \(\qquad S=R\cup \{ v\} \)
Given rectangular injectivity hypotheses, finite union closure, oriented margin-and-cover hypotheses at every edge, and one-site separation, the finite square lattice satisfies the general normal blocking hypotheses. The edge-blocking hypotheses are exactly the margin-cover construction, the one-edge datum at an edge is the datum supplied there, and the one-site separation is exactly the supplied one-site separation. Hence these hypotheses give the three injective regions, the endpoint-disjoint-cover facts at each edge, and the one-site membership formula as consequences of the same normal blocking hypotheses.
Combine the edge-blocking hypotheses constructed from the margin-cover hypotheses with the given one-site separation hypotheses.
Suppose two normal PEPS generate the same state, can be blocked into three-site injective chains around every edge, and for every site admit two injective regions with injective complements that differ exactly at that site. Then their defining tensors are related by a local gauge, and the gauges are unique up to the scalar freedom allowed by the graph. This is the general normal-PEPS theorem in [ 220 , Section 4 ] , following its Theorem 3. A connected-graph form, with the blocking hypothesis stated as the source’s proof uses it (one blocking shared by the two states, each distinguished edge the entire bond of its chain), is Theorem 24.8.7; its per-edge uniqueness clause is Theorem 24.8.8. The source’s remark following the theorem, that for a translationally invariant system the gauges are also translationally invariant when the proportionality constants are not absorbed into them, is realized on the torus by Theorem 24.7.1.10: its gauge family is carried onto every edge by the translations from one reference matrix per orientation class, and its scalar \(\lambda \) is kept separate rather than absorbed.
For two region-injectivity assignments on the same vertex set, a region is doubly injective when it is injective for each of the two. The general normal theorem blocks two states by one shared geometry, and its final comparison contracts both tensors over the same regions, so its blocking hypotheses are instantiated at the doubly injective assignment of the two tensors.
Two PEPS tensors \(A\) and \(B\) on a finite simple graph are a pair of normal PEPS tensors if they satisfy the normal blocking hypotheses at the doubly injective assignment of the two tensors and every virtual bond space of each tensor is nonzero, that is, \(D_A(e){\gt}0\) and \(D_B(e){\gt}0\) for every edge \(e\). Normality is blockability into injective regions, as defined in [ 220 , Section 3 ] . The nonzero bond spaces are the standing convention of that section. Region injectivity does not imply them: a zero-dimensional boundary bond leaves a region with no boundary configurations, so its injectivity holds vacuously. The convention is recorded in [ 67 ] .
Let \(A\) and \(B\) be a pair of normal PEPS tensors on a finite simple graph with the same positive physical dimension, generating the same state, with each distinguished edge the only edge of the graph joining its two adjacent blocks. Then the bond dimensions of \(A\) and \(B\) agree on every edge. The one-edge form assumes only the blocking datum at a single edge, and takes the positive bond dimensions as explicit hypotheses. In the source the equality is part of the isomorphism lemma of [ 220 , Section 3 ] : the insertion correspondence \(X\mapsto Y\) on the chosen bond is an algebra isomorphism between the two full bond matrix algebras, so the bond dimensions on the two sides agree; the normal case inherits the argument through the blocked three-site chains. The single-crossing condition is the source’s blocking around an edge made explicit: the chosen edge is the entire bond between the first two parties of the blocked chain.
Fix an edge. Blocking both networks into the shared three regions around it produces two three-site chains on the three-vertex complete graph whose super-sites carry the blocked-region weight families, injective by hypothesis. Each coarse state coefficient is a positive merge-collapse constant, a product of bond dimensions over the edges not incident to each region, times the corresponding original state coefficient, so the two coarse states are proportional with ratio the two constants. Multiplying one super-site of each chain by the other chain’s constant yields chains with equal states, unchanged bond dimensions, and the super-site injectivities preserved. The matched matrix insertions on the distinguished coarse bond of the two scaled chains form an algebra isomorphism between the two full bond matrix algebras (Theorem 24.3.17), and an isomorphism of full matrix algebras forces equal matrix sizes. Under the single-crossing hypothesis the coarse bond carries the original bond dimension of the distinguished edge for each tensor, so the two original bond dimensions agree.
Let \(A\) and \(B\) be a pair of normal PEPS tensors on a connected finite simple graph with the same positive physical dimension, generating the same state. Thus the normal blocking hypotheses hold at the doubly injective assignment of the two tensors: around every edge the network blocks into three doubly injective regions with the edge endpoints in the first two, and every site admits two doubly injective regions, with doubly injective complements, differing exactly at that site. Suppose moreover that at every edge the distinguished edge is the only edge of the graph joining its two adjacent blocks. Then the defining tensors are related by a local gauge: there are invertible matrices, one on each edge, whose endpoint actions transform \(A_v\) into \(B_v\) at every vertex, with no leftover scalar. The shared blocking gives a common tripartition for the two tensors, with all three regions injective for both. For an edge \(e\) between the first two regions, the coefficient transfer \(T_e\) supplied by the three-site isomorphism argument satisfies
for an invertible \(Z_e\) and every virtual insertion \(X\) on \(e\). The single-crossing hypothesis identifies \(e\) with the entire bond between \(R_1\) and \(R_2\), so \(Z_e\) acts on the original edge. The equality of the bond dimensions is not assumed; it follows from the blocking hypotheses by Theorem 24.8.6. The nonzero bond spaces of the pair are used in the injectivity argument, while connectivity permits the per-vertex constants to be absorbed into the edge gauges; see Theorem 24.4.1.24. This is the blocking argument of [ 220 , Section 4 ] .
The bond dimensions of the two tensors agree on every edge by Theorem 24.8.6. The union closure of injective regions for either tensor follows from the positive bond dimensions and Lemma 24.5.10. At every edge the shared blocking datum restricts to a datum for each tensor over the same three regions, so the per-edge gauge of the region insertion transfer (Theorem 24.4.34) and its orientation-adapted absorption give a family of invertible matrices realizing the absorbed inserted-coefficient equality at every edge. A gauge preserves blocked-region linear independence, so at every site the one-site comparison applies to the gauge-absorbed tensor: comparing the smaller region with its one-site completion yields two proportionality scalars whose ratio is a nonzero scalar \(\lambda _v\) with \(A_v\) equal to \(\lambda _v\) times the gauge action on \(B\) at \(v\). When the smaller region is empty its block is the count of global virtual configurations, and when the completion is the full vertex set its block is the closed state coefficient; in these degenerate cases the proportionality holds with scalar one, and every other comparison region has a boundary edge by connectivity. The per-vertex relations against the nonzero closed state force \(\prod _v \lambda _v = 1\), so on the connected graph a spanning-tree construction realizes the reciprocals of the scalars as oriented incidence products of edge scalars, which fold into the gauges as in the absorption step of the injective Fundamental Theorem (Theorem 24.3.32).
Let \(A\) and \(B\) be a pair of normal PEPS tensors on a finite simple graph with equal bond dimensions. Suppose two families of invertible matrices, one on each edge, each realize the scalar-free gauge relation of Theorem 24.8.7: at every vertex the endpoint actions of the family transform \(A_v\) into \(B_v\). Then the two families are proportional at every edge: \(X'_e = c\cdot X_e\) for a nonzero scalar \(c\) depending on the edge. This is the uniqueness clause of the general normal-PEPS theorem in [ 220 , Section 4 ] , following its Theorem 3, read against the scalar-free relation; neither equality of the two states nor connectivity is needed.
The inserted-edge coefficient is multilinear in the site tensors, one factor per site, so each scalar-free per-vertex relation makes every inserted coefficient of \(B\) equal the corresponding inserted coefficient of the gauge-absorbed \(A\): each family realizes the absorbed inserted-coefficient equality at every edge, with the roles of the two tensors exchanged. On the first block of the edge’s frame, whose blocked map and complement blocked map are injective for \(A\) by the blocking hypotheses and union closure (Lemma 24.5.10), the region insertion transfer is determined by the absorbed equality (Theorem 24.4.36), so the two orientation-adapted absorbing gauges induce the same conjugation and differ by a nonzero scalar; unwinding the orientation adaptation gives the proportionality of the gauges themselves.
24.9 Fundamental Theorem for normal matrix product states
The closed chain is the one-dimensional PEPS: the cycle graph on \(n\) vertices carrying one tensor of \(D \times D\) matrices per site, so that a physical configuration \(\sigma = (i_1, \ldots , i_n)\) receives the amplitude \(\operatorname{tr}(A^{i_1} \cdots A^{i_n})\). The Fundamental Theorem for normal PEPS therefore specializes to matrix product states once its blocking hypotheses are read off the chain, yielding the matrix-product-state corollaries of [ 220 , Section 4 ] and the sharper system-size bound in its closing part Normal MPS: alternative proof.
The development proceeds in four steps. The closed chain is first identified with a cycle of tensors, and the normal blocking hypotheses are obtained from the injectivity of every arc of \(L\) consecutive sites, giving the Fundamental Theorem for normal matrix product states on a ring of \(n \ge 3L\) sites with one invertible gauge per bond. The translation-invariant case then collapses the per-bond gauges to one gauge \(Z\) and one scalar \(\lambda \), with the length-\(n\) trace identity forcing \(\lambda ^n = 1\).
For the sharper bound, the matrix-product-state form of [ 220 , Lemma 5 ] compares the \(L + 1\) overlapping windows around a fixed bond. If \(C_j\) is the deformation of the \(j\)-th window, then for length-\(L\) words \(a\) and \(b\) the family of consecutive-window trace identities strips to \(C_0(a)\, B^b = B^a\, C_L(b)\), and hence to \(C_0(a) = B^a X\) and \(C_L(b) = X B^b\). This is the step that lowers the system size from \(n \ge 3L\) to \(n \ge 2L + 1\). Finally the same argument is run for site-dependent chains, one tensor per site, which is the setting of [ 220 , Lemma 5 ] .
24.9.1 Matrix product states on the closed chain
A closed chain of \(n\) sites is the cycle graph on \(n\) vertices, and a block of consecutive sites is an arc: the vertices reached clockwise from a starting site. Suppose \(0 {\lt} L\), \(3L \le n\), every arc of \(L\) consecutive sites is injective for a region-injectivity assignment, and injectivity is closed under unions. Then the chain satisfies the normal blocking hypotheses: around every edge it blocks into the \(L\) sites on one side, the \(L\) sites on the other, and the remaining \(n - 2L \ge L\) sites, all injective and covering the chain; and at every site the \(L + 1\) sites starting there and the \(L\) sites starting at its successor are injective regions with injective complements differing exactly at that site. Moreover the only nearest-neighbour pair joining the two blocks around an edge is the edge itself, since the far ends of the two blocks are separated by the remaining \(n - 2L \ge L\) sites.
Membership in an arc is a cyclic-distance inequality, so the disjointness, covering, and unique-crossing claims are modular arithmetic on the distances. Arcs of length between \(L\) and \(n\) are unions of arcs of length \(L\), hence injective by union closure; this covers the two complements at a site and the third block around an edge.
A tensor on the closed chain of \(n\) sites is a normal MPS with blocking length \(L\) when blocking any \(L\) consecutive sites gives an injective tensor and every virtual bond space is nonzero. This is the hypothesis on each of the two MPS in the first corollary following the general normal-PEPS theorem in [ 220 , Section 4 ] . The nonzero bond spaces are the standing convention of that section; injectivity of the blocks does not imply them, and the convention is recorded in [ 67 ] .
Let \(A\) and \(B\) be tensors on the closed chain of \(n\) sites (the cycle graph on \(n\) vertices, one tensor per site with two virtual legs), with the same positive physical dimension, and let \(0 {\lt} L\) with \(n \ge 3L\). Suppose \(A\) and \(B\) are normal MPS with blocking length \(L\) (Definition 24.9.1.2) and generate the same state. Then the defining tensors are related by a local gauge: there are invertible matrices, one on each bond, whose endpoint actions transform \(A_i\) into \(B_i\) at every site with no leftover scalar. This is the source’s family \(Z_i\) (\(i = 1, \ldots , n\), \(n + 1 \equiv 1\)) with \(B_i = Z_i^{-1} A_i Z_{i+1}\), the first corollary following the general normal-PEPS theorem in [ 220 , Section 4 ] , the statement for MPS without translation invariance at a fixed system size. The positive physical dimension is carried over from the general theorem, the nonzero bond spaces are part of the definition of a normal MPS, and \(0 {\lt} L\) is implicit in the source’s blocking of \(L\) consecutive sites; the equality of the bond dimensions is not assumed but derived, and the connectivity of the cycle is proved, not assumed.
The nonzero bond spaces give union closure of injective regions for each tensor (Lemma 24.5.10), hence for the doubly injective assignment. The arc-injectivity hypothesis then yields the normal blocking hypotheses on the cycle with the unique crossing property (Theorem 24.9.1.1), the cycle is connected, and the Fundamental Theorem for normal PEPS on a connected graph (Theorem 24.8.7) supplies the scalar-free local gauge.
In the setting of Corollary 24.9.1.3, for normal MPS \(A\) and \(B\) with blocking length \(L\) and equal bond dimensions, any two families of invertible bond matrices realizing the scalar-free gauge relation are proportional at every bond: \(Z'_i = c \cdot Z_i\) for a nonzero scalar \(c\) depending on the bond. This is the uniqueness clause of the first corollary following the general normal-PEPS theorem of [ 220 , Section 4 ] : the gauges \(Z_i\) are unique up to a multiplicative constant. Neither equality of the two states nor connectivity is needed, as in the general uniqueness clause.
Every edge of the cycle graph on \(n \ge 3\) vertices joins a site to its cyclic successor, so sites and bonds are in bijection, and every site has exactly two incident bonds: the bond shared with its cyclic predecessor and the bond shared with its cyclic successor. The cycle tensor of a tensor \(A = (A^i)_{i=0}^{d-1}\) of \(D \times D\) matrices places one copy of \(A\) at every site of the closed chain of \(n\) sites, every bond of dimension \(D\), with the row index of \(A^i\) read from the bond shared with the predecessor and the column index from the bond shared with the successor.
For \(n \ge 3\) and every configuration \(\sigma = (i_1, \ldots , i_n)\), the state coefficient of the cycle tensor of \(A\) at \(\sigma \) is the matrix product vector component \(V^{(n)}(A)_\sigma = \operatorname{tr}\! (A^{i_1} \cdots A^{i_n})\).
An entry of a word product is a sum over paths of bond indices pinned at the two ends of products of matrix entries read along the path, by induction on the word; closing the two pinned ends into a loop, the trace of a closed word product is the sum over all cyclic bond configurations of the products of entries around the loop. Contracting the cycle tensor sums the per-site entries over all assignments of bond indices, which is that cyclic sum after matching each bond with the site on its predecessor side.
Let \(0 {\lt} L {\lt} n\) with \(n \ge 3\), let the bond dimension be positive, and suppose \(A\) is \(L\)-block injective. Then for every arc of \(L\) consecutive sites of the closed chain, the blocked tensor of the arc of the cycle tensor of \(A\) is injective.
An arc of \(L {\lt} n\) consecutive sites has exactly two boundary-crossing bonds, the bond entering its first site and the bond leaving its last site, by cyclic-distance arithmetic. The blocked weight of the arc at a boundary assignment \((a, b)\) and a physical word \(x\) is \(D^{\, n - (L+1)}\, (A^{x_1} \cdots A^{x_L})_{a b}\): the bonds inside the arc contract to the matrix product, the two boundary bonds stay pinned, and each bond away from the arc contributes a free factor \(D\). A linear relation among the blocked components over the boundary pairs is a matrix \(C\) with \(\operatorname{tr}\! (C^{\mathsf T} A^{x_1} \cdots A^{x_L}) = 0\) for every word \(x\); the word products span the full matrix algebra by \(L\)-block injectivity, and the trace pairing is nondegenerate, so \(C = 0\).
24.9.2 Translation-invariant matrix product states
When the same tensor sits at every site, the closed chain ties the per-bond gauges together. If one gauge \(Z\) and one scalar \(\lambda \) satisfy \(B^i = \lambda \, Z^{-1}A^iZ\) for every physical index \(i\), then for a configuration \(\sigma =(i_1,\ldots ,i_n)\),
Equality of the matrix product states therefore forces \(\lambda ^n = 1\). Thus \(Z\) and \(\lambda \) capture precisely the freedom in the translation-invariant corollary of [ 220 , Section 4 ] .
Let \(n\) be positive, let \(0 {\lt} L\) with \(2L + 1 \le n\), and let \(A\) and \(B\) be tensors of \(D \times D\) matrices with \(D{\gt}0\), over physical dimension \(d\), each \(L\)-block injective, whose matrix product vectors agree at system size \(n\): \(V^{(n)}(A)_\sigma = V^{(n)}(B)_\sigma \) for every configuration \(\sigma \). Then there are invertible matrices \(Z_v\), one per bond of the closed chain (\(v = 1, \ldots , n\), \(n + 1 \equiv 1\)), with \(B^i = Z_v^{-1}\, A^i\, Z_{v+1}\) for every site \(v\) and every \(i\). This is the first corollary following the general normal-PEPS theorem of [ 220 , Section 4 ] specialized to one site-independent tensor: the source states the corollary for site-dependent families, and its conclusion is the per-bond gauge family delivered here. The system size is the optimal \(n \ge 2L + 1\) of the source’s alternative proof (its Section “Normal MPS: alternative proof”), rather than the \(n \ge 3L\) of the blocking route. The source’s translation-invariant corollary (a single gauge \(Z\) and a constant \(\lambda \) with \(\lambda ^n = 1\)) refines this conclusion and is not part of this statement. A vanishing physical dimension is already excluded by block injectivity.
The per-bond form of the strengthened closed-chain corollary (Corollary 24.9.3.7), proved through the overlapping windows at \(n \ge 2L + 1\), gives the per-bond gauge family directly.
Let \(n\) be positive, let \(A\) and \(B\) be tensors of \(D \times D\) matrices over physical dimension \(d\) with \(A\) being \(L\)-block injective, and let \(Z_v\) and \(Z'_v\) (\(v = 1, \ldots , n\), \(n + 1 \equiv 1\)) be two families of invertible matrices with \(B^i = Z_v^{-1} A^i Z_{v+1}\) and \(B^i = Z'^{-1}_v A^i Z'_{v+1}\) at every site \(v\) and every \(i\). Then for every bond \(v\) there is a nonzero scalar \(c\) with \(Z'_v = c\, Z_v\). No condition on the system size is needed.
Iterating each relation along a word \(x\) of length \(L\) from the starting site \(v\) gives \(B^{x_1} \cdots B^{x_L} = Z_v^{-1} A^{x_1} \cdots A^{x_L} Z_{v+L}\) and the same with \(Z'\). Since the word products \(A^{x_1} \cdots A^{x_L}\) span the full matrix algebra by \(L\)-block injectivity, the comparison extends linearly to every matrix \(W\): \(Z_v^{-1} W Z_{v+L} = Z'^{-1}_v W Z'_{v+L}\). Taking \(W\) to be the identity in this extended relation pins the two bond transports \(Z_v^{-1} Z_{v+L} = Z'^{-1}_v Z'_{v+L}\) to the same invertible matrix; cancelling it leaves \(Z_v^{-1} W Z_v = Z'^{-1}_v W Z'_v\) for every \(W\), so \(Z'_v Z_v^{-1}\) commutes with the full matrix algebra, hence is a scalar, nonzero by invertibility.
Let \(n\) be positive, let \(0 {\lt} L\) with \(2L + 1 \le n\), and let \(A\) and \(B\) be tensors of \(D \times D\) matrices with \(D{\gt}0\), each \(L\)-block injective. If two families \(Z\) and \(Z'\) of invertible matrices on the bonds of the closed chain both satisfy \(B^i = Z_v^{-1} A^i Z_{v+1}\) at every site, then they are proportional by a single constant: there is a nonzero scalar \(c\) with \(Z'_v = c\, Z_v\) at every bond. This is the uniqueness clause of the first corollary following the general normal-PEPS theorem of [ 220 , Section 4 ] , for one site-independent tensor. Equality of the two states is not needed.
At every bond the two gauges differ by a nonzero scalar \(\mu _v\) (Lemma 24.9.2.2). The relation \(B^i = Z_v^{-1} A^i Z_{v+1}\) for both families forces the scalar \(\mu _v^{-1}\mu _{v+1}\) to fix the nonzero tensor \(B\), so consecutive constants agree, and going around the cycle merges them into one.
Let \(n\) be positive, let \(A\) and \(B\) be tensors of \(D \times D\) matrices over physical dimension \(d\) with \(A\) being \(L\)-block injective, and let \(Z_v\) (\(v = 1, \ldots , n\), \(n + 1 \equiv 1\)) be invertible matrices with \(B^i = Z_v^{-1} A^i Z_{v+1}\) at every site \(v\) and every \(i\). Then for every site \(v\) there is a nonzero scalar \(c\) with \(Z_{v+1} = c\, Z_v\).
Iterating the per-bond relation along a word \(x\) of length \(L\) from the starting site \(v\) gives \(B^{x_1} \cdots B^{x_L} = Z_v^{-1} A^{x_1} \cdots A^{x_L} Z_{v+L}\). Comparing the iterations from \(v\) and from \(v + 1\) over the word products \(A^{x_1} \cdots A^{x_L}\), which span the full matrix algebra by \(L\)-block injectivity, the comparison extends linearly to every matrix \(W\): \(Z_v^{-1} W Z_{v+L} = Z_{v+1}^{-1} W Z_{v+1+L}\). Taking \(W\) to be the identity in this extended relation pins the two bond transports \(Z_v^{-1} Z_{v+L} = Z_{v+1}^{-1} Z_{v+1+L}\) to the same invertible matrix; cancelling it leaves \(Z_v^{-1} W Z_v = Z_{v+1}^{-1} W Z_{v+1}\) for every \(W\), so \(Z_{v+1} Z_v^{-1}\) commutes with the full matrix algebra, hence is a scalar, nonzero by invertibility.
Let \(n\) be positive, let \(0 {\lt} L\) with \(2L + 1 \le n\), and let \(A\) and \(B\) be tensors of \(D \times D\) matrices with \(D{\gt}0\), over physical dimension \(d\), each \(L\)-block injective, whose matrix product vectors agree at system size \(n\): \(V^{(n)}(A)_\sigma = V^{(n)}(B)_\sigma \) for every configuration \(\sigma \). Then there are an invertible matrix \(Z\) and a constant \(\lambda \) with \(\lambda ^n = 1\) such that \(B^i = \lambda \, Z^{-1} A^i Z\) for every \(i\). This is the translation-invariant corollary of [ 220 , Section 4 ] , the statement for TI MPS following the first corollary after the general normal-PEPS theorem. The system size is the optimal \(n \ge 2L + 1\) of the source’s alternative proof.
This is the single-gauge form of the strengthened closed-chain corollary (Corollary 24.9.3.6), proved through the overlapping windows at \(n \ge 2L + 1\).
Let \(0 {\lt} L\) and \(0{\lt}D\), and let \(A\) and \(B\) be tensors of \(D \times D\) matrices, each \(L\)-block injective. If invertible matrices \(Z\), \(Z'\) and constants \(\lambda \), \(\lambda '\) satisfy \(B^i = \lambda \, Z^{-1} A^i Z\) and \(B^i = \lambda '\, Z'^{-1} A^i Z'\) for every \(i\), then there is a nonzero scalar \(c\) with \(Z' = c\, Z\). This is the uniqueness clause of the translation-invariant corollary of [ 220 , Section 4 ] for TI MPS. No system size enters the statement: equality of the two states is not needed, nor are the root-of-unity conditions on \(\lambda \) and \(\lambda '\).
The scalar \(\lambda \) is nonzero because \(B\) is \(L\)-block injective with positive bond dimension, so some \(B^{i_0} \neq 0\). Iterating each relation along a word \(x\) of length \(L\) gives \(B^{x_1} \cdots B^{x_L} = \lambda ^L\, Z^{-1} A^{x_1} \cdots A^{x_L} Z\) and the primed analog; the word products span the full matrix algebra by \(L\)-block injectivity, so \(\lambda ^L\, Z^{-1} W Z = \lambda '^L\, Z'^{-1} W Z'\) for every matrix \(W\). The identity pins \(\lambda ^L = \lambda '^L\); cancelling the nonzero factor leaves \(Z^{-1} W Z = Z'^{-1} W Z'\) for every \(W\), so \(Z' Z^{-1}\) commutes with the full matrix algebra, hence is a nonzero scalar.
24.9.3 The optimal system size \(n \ge 2L + 1\)
The bound \(n \ge 3L\) is not optimal. A bond of the closed chain is straddled by the \(L + 1\) overlapping windows of \(L\) sites around it. For consecutive windows, the deformed closed-chain coefficients have the form
Injectivity on the complementary arc strips these identities to
and chaining the relations across the \(L + 1\) windows gives \(C_0(a)\, B^b = B^a\, C_L(b)\). This is the overlap mechanism in [ 220 , Lemma 5 ] . The lemmas below establish that argument: block injectivity extends to every length, word products transport between equal-state chains, and the bond operator is extracted and shown to act by conjugation, lowering the system size to \(n \ge 2L + 1\).
Let \(A\) be a tensor of \(D \times D\) matrices over physical dimension \(d\), \(L\)-block injective with \(0 {\lt} L\). Then \(A\) is \(m\)-block injective for every \(m \ge L\). This is the chain form of the statement that any region of at least the blocking size is injective, derived in the closing section of [ 220 ] (“Normal MPS: alternative proof”) from its union lemma.
It suffices to pass from length \(m\) to \(m + 1\). Write the identity as a combination of length-\(L\) word products and peel the leading letter of each: any matrix \(P\) becomes a combination of terms \(A^{i}\, (W P)\) with \(W\) a word product of length \(L - 1\). Each factor \(W P\) is a combination of length-\(m\) word products by the induction hypothesis, so each term is a combination of length-\((m+1)\) word products.
Let \(A\) and \(B\) be tensors of \(D \times D\) matrices over physical dimension \(d\), let \(n = k + q\), and suppose the length-\(k\) and length-\(q\) word products of \(A\) each span the full matrix algebra. If the matrix product vectors of \(A\) and \(B\) agree at system size \(n\), then there is a linear map \(\Lambda \) of the matrix algebra with \(\Lambda (A^{x_1} \cdots A^{x_k}) = B^{x_1} \cdots B^{x_k}\) for every word \(x\) of length \(k\). The same holds when, instead of the traces, the word products of the two tensors are themselves equal at length \(n\). This is the operator-transport mechanism underlying Lemma 5 of [ 220 ] : an operator expanded over the window products of one network is re-read in the other.
Pair the matrix algebra against the complementary word products: let \(\Psi _A(M)\) be the family of traces \(\operatorname{tr}(M\, A^{y_1} \cdots A^{y_q})\) over the length-\(q\) words \(y\), and \(\Psi _B\) its \(B\)-analog. \(\Psi _A\) is injective because the length-\(q\) products span and the trace pairing is nondegenerate. On the spanning family of length-\(k\) products the two pairings match: \(\Psi _A(A^{x}) = \Psi _B(B^{x})\), since both compute closed-chain coefficients of total length \(n\), equal by hypothesis. Hence the range of \(\Psi _A\) lies in that of \(\Psi _B\), forcing \(\Psi _B\) to be injective by dimension count, and a left inverse of \(\Psi _B\) composed with \(\Psi _A\) is the transport. For the matrix-product version replace the traces by the products themselves.
Let \(0 {\lt} L\) with \(2L + 1 \le n\), let \(B\) be a tensor of \(D \times D\) matrices over physical dimension \(d\), \(L\)-block injective, and let \(C_0, \ldots , C_L\) be deformed window tensors: each \(C_j\) assigns a matrix to every word of length \(L\), read as replacing the blocked tensor of the \(L\)-site window starting \(j\) sites left of a fixed bond of the closed chain on \(n\) sites. Suppose the deformed states agree for consecutive window positions: for every \(j {\lt} L\), every prefix \(p\) of \(j\) sites, every assignment \(u\) on the \(L + 1\) sites covered by the two windows, and every suffix \(s\) on the remaining sites,
Then the deformation is a virtual operation on the bond: there is a matrix \(X\) such that, for all length-\(L\) words \(a\) and \(b\),
and \(X\) is unique. This is Lemma 5 of [ 220 ] (its closing section, “Normal MPS: alternative proof”), specialized to one site-independent tensor; the source states it for site-dependent tensors on five sites with \(L = 2\), with the deformed window tensors arising as physical operators contracted with the blocked windows they act on; the site-dependent form, in the setting in which the source states the lemma, is Lemma 24.9.4.4, and this statement is its constant specialization. The algebra-homomorphism clause of the source lemma is established with the insertion correspondence in Lemma 24.9.3.4.
Place the tensor at every site of the site-dependent form (Lemma 24.9.4.4): the arc products of the constant chain are the word products of the repeated tensor, and \(L\)-block injectivity of the tensor is window injectivity of the constant chain.
Let \(0 {\lt} L\) with \(2L + 1 \le n\) and \(0{\lt}D\), and let \(A\) and \(B\) be tensors of \(D \times D\) matrices over physical dimension \(d\), each \(L\)-block injective, whose matrix product vectors agree at system size \(n\). Then there is an invertible matrix \(Z\) such that, for every word \(w\) of length \(n\),
This captures the insertion correspondence of Lemma 5 of [ 220 ] and its algebra-homomorphism clause for one site-independent tensor: the map sending an insertion on one network to the corresponding insertion on the other is an automorphism of the matrix algebra, hence inner.
Regard \(A\) and \(B\) as constant site-dependent chains on \(n\) sites. Window injectivity of a constant chain is block injectivity of the single tensor, and agreement of the matrix product vectors at size \(n\) is the same-state hypothesis, so the site-dependent overlapping-window capstone (Corollary 24.9.4.8) supplies a per-bond gauge family relating the two chains. The arc products of a constant chain are the word products of the tensor, and the gauge conjugation of arc products (Theorem 24.9.4.9), read at the full chain length \(n\) where the end bond wraps to the starting bond, is conjugation of the length-\(n\) word products by the gauge at the starting bond.
Let \(0 {\lt} L\) with \(2L + 1 \le n\) and \(0 {\lt} D\), and let \(A\) and \(C\) be tensors of \(D \times D\) matrices over physical dimension \(d\), each \(L\)-block injective, with equal word products at length \(n\): \(C^{w_1} \cdots C^{w_n} = A^{w_1} \cdots A^{w_n}\) for every word \(w\) of length \(n\). Then there is a constant \(\lambda \) with \(\lambda ^n = 1\) and \(C^i = \lambda A^i\) for every \(i\).
Transport word products of \(A\) to those of \(C\) at the window length \(L\), at \(L + 1\), at the complementary length \(n - 1 - L\), and at \(n - L\) (Lemma 24.9.3.2, matrix-product version; the lengths lie between \(L\) and \(n - L\) by \(2L + 1 \le n\)). For a transport pair at lengths \(k\) and \(k + 1\), the transported identity \(\Lambda _k(\mathbb {1})\) commutes with every letter of \(C\) - its two one-letter extensions agree, \(C^i\, \Lambda _k(\mathbb {1}) = \Lambda _{k+1}(A^i) = \Lambda _k(\mathbb {1})\, C^i\) - hence with the full matrix algebra by block injectivity, so it is a scalar \(c_k \mathbb {1}\), nonzero because the transport is surjective onto the spanning word products, hence bijective. Peeling one letter off the full-length equality through the spanning windows of lengths \(L\) and \(n - 1 - L\) then leaves \(C^i = (c_L\, c_{n-1-L})^{-1} A^i =: \lambda A^i\); evaluating any nonzero length-\(n\) word product gives \(\lambda ^n = 1\).
Let \(0 {\lt} L\) with \(2L + 1 \le n\) and \(0{\lt}D\), and let \(A\) and \(B\) be tensors of \(D \times D\) matrices over physical dimension \(d\), each \(L\)-block injective, whose matrix product vectors agree at system size \(n\): \(V^{(n)}(A)_\sigma = V^{(n)}(B)_\sigma \) for every configuration \(\sigma \). Then there are an invertible matrix \(Z\) and a constant \(\lambda \) with \(\lambda ^n = 1\) such that \(B^i = \lambda \, Z^{-1} A^i Z\) for every \(i\). This is the strengthened closed-chain corollary of [ 220 ] (the corollary after Lemma 5 in its closing section “Normal MPS: alternative proof”), proved through the overlapping windows at the optimal \(n \ge 2L + 1\) rather than the \(n \ge 3L\) of the blocking route; the single-gauge corollary 24.9.2.5 delegates to it. The uniqueness clause of the source corollary - the gauge \(Z\) is unique up to a multiplicative constant - needs no system size and is Corollary 24.9.2.6.
By Lemma 24.9.3.4 the word products of \(B\) at length \(n\) are those of \(A\) conjugated by an invertible matrix. Absorbing the conjugation into \(B\) - which preserves \(L\)-block injectivity - leaves two tensors with equal word products at length \(n\), and Lemma 24.9.3.5 makes them proportional letterwise by an \(n\)-th root of unity. Undoing the absorption gives \(B^i = \lambda \, Z^{-1} A^i Z\).
Let \(n\) be positive, let \(0 {\lt} L\) with \(2L + 1 \le n\) and \(0{\lt}D\), and let \(A\) and \(B\) be tensors of \(D \times D\) matrices over physical dimension \(d\), each \(L\)-block injective, whose matrix product vectors agree at system size \(n\). Then there are invertible matrices \(Z_v\), one per bond of the closed chain (\(v = 1, \ldots , n\), \(n + 1 \equiv 1\)), with \(B^i = Z_v^{-1}\, A^i\, Z_{v+1}\) for every site \(v\) and every \(i\). This is the per-bond gauge family of the closed-chain corollary, proved at the source’s strengthened bound \(n \ge 2L + 1\) ( [ 220 ] , the corollary after Lemma 5 in its closing section “Normal MPS: alternative proof”). The named matrix-level Corollary 24.9.2.1 delegates to it.
The single-gauge form (Corollary 24.9.3.6) gives \(Z\) and \(\lambda \) with \(\lambda ^n = 1\) and \(B^i = \lambda \, Z^{-1} A^i Z\). The family \(Z_v := \lambda ^{v} Z\) dresses the gauge with powers of the root of unity: away from the seam the consecutive powers contribute the factor \(\lambda \), and across the seam the wraparound contributes \(\lambda ^{1-n} = \lambda \) because \(\lambda ^n = 1\), so \(B^i = Z_v^{-1} A^i Z_{v+1}\) at every site.
24.9.4 Site-dependent chains
The source states its Lemma 5 for site-dependent tensors: five sites carrying tensors \(A_1, \ldots , A_5\) whose two-site windows are injective. While the previous results focus on a repeated tensor, the site-dependent setting treats chains carrying a distinct tensor per site. Windows are arcs of consecutive sites, and the closed-chain corollary delivers one gauge per bond. Most of the matrix-chain statements below take one physical dimension \(d\) and one bond dimension \(D\). For the Applications-section translational-invariance corollary, the cycle-graph formulation instead retains one dimension \(D_e\) per bond, derives their equality from the injective Fundamental Theorem, and then identifies the virtual spaces to construct the repeated tensor in the source’s standing regime of at least three sites. The literal two-site reading of the printed corollary is false; this is recorded by Theorem 24.9.4.14 and [ 29 ] .
Let a closed chain on \(n \ge 1\) sites carry one tensor of \(D \times D\) matrices over physical dimension \(d\) per site, \(A_0, \ldots , A_{n-1}\). The arc product of a word \(x=x_1\cdots x_\ell \) read from site \(s\) is
with site indices read cyclically. The chain is window injective at length \(L\) when, for every site \(s\), the arc products of the length-\(L\) words read from \(s\) span the full matrix algebra. This is the site-dependent setting of the closing section of [ 220 ] (“Normal MPS: alternative proof”): an MPS on five sites in which the blocking of any two consecutive tensors is injective, for a general window length \(L\).
If every tensor in a closed chain is injective, then the chain is window injective at length \(1\). Indeed, the length-one arc products at site \(s\) are precisely the matrices of the tensor at site \(s\).
The family of length-one words is identified with the physical alphabet. Under this identification the length-one arc product is exactly the corresponding local matrix, so the two spanning conditions coincide.
Let a site-dependent chain on \(n \ge 1\) sites be window injective at length \(L\) with \(0{\lt}L\). Then for every \(m \ge L\) and every site \(s\), the arc products of the length-\(m\) words read from \(s\) span the full matrix algebra. This is the site-dependent form of the remark that any region of at least the blocking size is injective ( [ 220 ] , closing section, cf. Lemma 24.9.3.1).
Write the identity as a combination of window products at the starting site and peel the leading letter of each: any matrix becomes a combination of terms \(A_s^i(WP)\) with \(W\) an arc product of length \(L-1\) read from \(s+1\). Each factor \(WP\) is a combination of length-\(m\) arc products read from \(s+1\) by induction, so each term is a combination of length-\((m+1)\) arc products read from \(s\).
Let \(0{\lt}L\) with \(2L+1\le n\), let the closed chain on \(n\) sites carry one tensor of \(D \times D\) matrices per site, window injective at length \(L\), and fix a site \(r\). Let \(C_0, \ldots , C_L\) be deformed window tensors around the bond \((r+L-1,r+L)\): each \(C_j\) assigns a matrix to every word of length \(L\), read as replacing the blocked tensor of the \(L\)-site window starting at site \(r+j\). Suppose the deformed states agree for consecutive window positions: for every \(j{\lt}L\), every prefix \(p\) of \(j\) sites read from \(r\), every assignment \(u\) on the \(L+1\) sites covered by the two windows, and every suffix \(s\) on the remaining sites,
Then the deformation is a virtual operation on the bond: there is a matrix \(X\) with \(C_0(a)=A_{(r)}^aX\) and \(C_L(b)=XA_{(r+L)}^b\) for all length-\(L\) words \(a\), \(b\), and \(X\) is unique. This is Lemma 5 of [ 220 ] in the site-dependent setting in which the source states it, with the deformed window tensors arising as physical operators contracted with the blocked windows they act on; Lemma 24.9.3.3 is its constant specialization.
Comparing the windows at \(j\) and \(j+1\) through the complementary arc of \(n-L-1\ge L\) sites, whose arc products span by Lemma 24.9.4.3, strips the state equality to the letter level: \(C_j(u_1\cdots u_L)A_{r+j+L}^{u_{L+1}} =A_{r+j}^{u_1}C_{j+1}(u_2\cdots u_{L+1})\) on every window of \(L+1\) sites. Chaining the \(L\) relations along the \(2L\) sites flanking the bond turns the leftmost window into the rightmost one: \(C_0(a)A_{(r+L)}^b=A_{(r)}^aC_L(b)\) for all length-\(L\) words. Writing the identity as a combination \(\sum _b\alpha _bA_{(r+L)}^b=\mathbb {1}\), the matrix \(X:=\sum _b\alpha _bC_L(b)\) satisfies \(A_{(r)}^aX=C_0(a)\); the mirrored combination of the \(C_0\)-family collapses onto the same matrix, giving \(XA_{(r+L)}^b=C_L(b)\), and stripping the spanning factors makes \(X\) unique.
Let two site-dependent chains \(A\), \(B\) on \(n\) sites generate the same closed-chain state, let \(k+q=n\), and suppose the \(A\)-arc products of length \(k\) read from a site \(s\) and of length \(q\) read from \(s+k\) each span the full matrix algebra. Then there is a linear map \(\Lambda \) of the matrix algebra with \(\Lambda (A_{(s)}^x)=B_{(s)}^x\) for every word \(x\) of length \(k\).
As for one repeated tensor (Lemma 24.9.3.2): pair the matrix algebra against the complementary arc products. The pairing is injective on the \(A\)-side by spanning and trace nondegeneracy, and the two pairings match on the spanning arc family because both compute closed-chain coefficients of total length \(n\), equal after rotating the trace of the closed chain to the starting site \(s\).
Let \(0{\lt}L\) with \(2L+1\le n\), let \(A\) and \(B\) be site-dependent chains on \(n\) sites, each window injective at length \(L\), generating the same closed-chain state, and fix a site \(r\). Then there is a linear map \(\Phi \) of the matrix algebra, unital and multiplicative, such that \(\operatorname{tr}(XA_{(r+L)}^w)=\operatorname{tr}(\Phi (X)B_{(r+L)}^w)\) for every matrix \(X\) and every word \(w\) of length \(n\), and \(\Phi \) is the unique linear map with this pairing property. This is the closing clause of Lemma 5 of [ 220 ] —the maps \(O_1\mapsto X\) and \(O_3^T\mapsto X\) are uniquely defined and are algebra homomorphisms—in the site-dependent setting of the source, with the algebra structure carried by the insertions: \(\Phi \) sends an insertion on the bond \((r+L-1,r+L)\) of the first chain to the bond operator extracted on the second.
A virtual insertion \(X\) on the bond is realized on each of the \(L+1\) overlapping windows around it by deformed window tensors placing \(X\) after the first \(L-j\) letters of the window starting at site \(r+j\). Each deformation is transported to the second chain by the arc transport at its own starting site (Lemma 24.9.4.5); the same-state hypothesis makes the transported deformations generate one common state, and the bond-operator extraction (Lemma 24.9.4.4) produces \(\Phi (X)\). Uniqueness of the bond operator makes \(\Phi \) linear, unital and multiplicative; the pairing against all closed-chain words follows by expanding the insertion over the window products, and pins \(\Phi \) through the spanning arcs of length \(n\) (Lemma 24.9.4.3) and nondegeneracy of the trace pairing.
Let \(0{\lt}L\) with \(2L+1\le n\), and let \(A\) and \(B\) be site-dependent chains on \(n\) sites with a common positive bond dimension, each window injective at length \(L\), generating the same closed-chain state. Then for every site \(p\) there is an invertible matrix \(Z\) with \(B_{(p)}^w=ZA_{(p)}^wZ^{-1}\) for every word \(w\) of length \(n\). The statement for one repeated tensor is Lemma 24.9.3.4.
The insertion correspondence at the bond (Lemma 24.9.4.6) is unital and nonzero, hence an automorphism of the full matrix algebra, and by Skolem–Noether (Theorem [ 216 , “Skolem–Noether” ] ) it is conjugation by an invertible \(Z\); pairing insertions against all closed-chain words read from \(p\) and using nondegeneracy of the trace pairing transfers the conjugation to the arc products.
Let \(0{\lt}L\) with \(2L+1\le n\), and let \(A\) and \(B\) be site-dependent chains on \(n\) sites with a common positive bond dimension, each window injective at length \(L\), generating the same closed-chain state. Then the chains are gauge equivalent: there are invertible matrices \(Z_v\), one per bond of the closed chain, with \(B_v^i=Z_vA_v^iZ_{v+1}^{-1}\) for every site \(v\) and every \(i\), with indices read cyclically. This is the closed-chain corollary of the closing section of [ 220 ] obtained from its site-dependent Lemma 5 at every bond; the source displays the corollary for translation-invariant tensors (Corollary 24.9.3.6), with the site-dependent Lemma 5 as its engine.
The per-bond conjugations (Lemma 24.9.4.7) give window covariance with nonzero scalars: on every arc of \(m\) sites with \(L\le m\) and \(m+L\le n\), the conjugation at the near end intertwines the arc products of the two chains across the far bond, the bond-operator extraction (Lemma 24.9.4.4) produces the connecting matrix, and the conjugation at the far end pins it to a nonzero scalar multiple of the gauge there through the centralizer of the full matrix algebra, so \(B_{(p)}^u=c_{p,m}Z_pA_{(p)}^uZ_{p+m}^{-1}\) on all length-\(m\) words \(u\). Comparing the covariance on windows of lengths \(L+1\) and \(L\) through the spanning window products leaves the letterwise relation \(B_v^i=\mu _vZ_vA_v^iZ_{v+1}^{-1}\) with nonzero scalars \(\mu _v\); iterating it once around the closed chain against a nonzero arc product forces \(\prod _v\mu _v=1\), and dressing the gauges with the partial products of the scalars absorbs them, including across the seam.
Let \(A_0,\ldots ,A_{n-1}\) and \(B_0,\ldots ,B_{n-1}\) be two site-dependent closed chains with a cyclic gauge relation \(B_v^i=Z_vA_v^iZ_{v+1}^{-1}\) at every site. Then they generate the same closed-chain state. More generally, the product along any arc is conjugated by the two gauges on the boundary bonds of that arc; for a full turn around the chain the two boundary bonds coincide, and cyclicity of trace removes the remaining conjugation.
Iterate the sitewise gauge relation along the arc. Consecutive boundary matrices cancel, leaving only the gauges at the two ends. For a word of length \(n\) read from the first site, the two ends are the same bond, so the closed trace is invariant under the resulting conjugation.
Let \(A_0,\ldots ,A_{n-1}\) and \(B_0,\ldots ,B_{n-1}\) be two site-dependent closed chains on \(n\ge 3\) sites, with common physical dimension and common positive bond dimension. Suppose every local tensor in both chains is injective and the two closed-chain states are equal. Then there are invertible matrices \(Z_0,\ldots ,Z_{n-1}\), one per bond of the closed chain, such that \(B_v^i=Z_vA_v^iZ_{v+1}^{-1}\) for every site \(v\) and every physical index \(i\), with indices read cyclically. This is the \(L=1\), uniform-dimension instance of [ 220 , Theorem thm:inj_MPS, lines 688–725 ] .
For a closed chain \(A_0,\ldots ,A_{n-1}\), its cyclic shift is the chain whose \(v\)-th tensor is \(A_{v+1}\), with indices read modulo \(n\). The generated state is cyclic-shift invariant when the closed-chain state of \(A_0,\ldots ,A_{n-1}\) agrees with that of \(A_1,\ldots ,A_{n-1},A_0\).
On the cycle graph with \(n\ge 3\) sites, let \(r(v)=v+1\) be the one-site rotation. The cyclic shift of a site-dependent tensor family \(A_0,\ldots ,A_{n-1}\) is the transport along \(r^{-1}\), so its tensor at site \(v\) is \(A_{v+1}\). Thus the shifted family is \(A_1,\ldots ,A_{n-1},A_0\), exactly as in [ 220 , lines 1807–1827 ] . The generated state is cyclic-shift invariant when the original and shifted families generate the same closed-chain state.
Let \(A_0,\ldots ,A_{n-1}\) be a site-dependent injective closed MPS on \(n\ge 3\) sites, with one dimension \(D_e\) for each bond \(e\). If its generated state is invariant under the cyclic shift \(A_v\mapsto A_{v+1}\), then the injective Fundamental Theorem compares the family with its shift by invertible matrices on the corresponding bonds. Consequently the bond from \(v\) to \(v+1\) and the bond from \(v+1\) to \(v+2\) have the same dimension. Iterating around the cycle gives \(D_e=D_f\) for every pair of bonds \(e,f\).
This is the at-least-three-site form of the “all bond dimensions are the same” clause of the Applications-section corollary in [ 220 , lines 1803–1842 ] . As in the injective Fundamental Theorem, injectivity includes the convention that every virtual space is nonzero.
Transport along the inverse rotation preserves injectivity and replaces the bond-dimension function \(D_e\) by \(D_{r(e)}\). Apply the injective Fundamental Theorem to the original and shifted families. Equality of their bond-dimension functions gives \(D_e=D_{r(e)}\); rotation sends the successor bond at \(v\) to the successor bond at \(v+1\). Cyclic induction then proves equality on all bonds.
The bond-uniformity implication is false for two sites. More precisely, there are injective tensors
whose closed-chain coefficients are invariant under the cyclic shift, but whose positive virtual dimensions are unequal. Consequently the condition \(n\ge 3\) in Corollary 24.9.4.13 cannot be removed. This corrects the unqualified printed corollary in [ 220 , lines 1803–1805 ] ; see [ 29 ] .
Let \(e_0,e_1\) be the standard basis of \(\mathbb C^2\) and take \(A_1^i=e_i^{\mathsf T}\) and \(A_2^i=e_i\). Each local tensor map sends a virtual basis to \(e_0,e_1\), hence is injective. Moreover
so the state is cyclically invariant, whereas the adjacent dimensions are \(1\) and \(2\).
Let \(A_0,\ldots ,A_{n-1}\) be an injective site-dependent closed chain with positive bond dimension on \(n\ge 3\) sites. If its generated state is invariant under the cyclic shift \(A_v\mapsto A_{v+1}\), then there are invertible matrices \(Z_0,\ldots ,Z_{n-1}\), one per bond, such that \(A_{v+1}^i=Z_vA_v^iZ_{v+1}^{-1}\) for every site \(v\) and physical index \(i\). This is the first comparison step in the Applications-section translation-invariant description corollary of [ 220 , lines 1807–1824 ] .
Apply Corollary 24.9.4.10 to the chain and its cyclic shift. Injectivity is preserved by the shift, and the state equality is exactly the cyclic-shift invariance hypothesis.
Suppose a closed chain \(A_0,\ldots ,A_{n-1}\) is gauge equivalent to its cyclic shift. Then for every site \(v\) there are invertible matrices \(L_v\) and \(R_v\) such that \(A_v^i=L_vA_0^iR_v^{-1}\) for every physical index \(i\). This is the telescoping step in [ 220 , lines 1828–1862 ] , where the products denoted \(L_i\) and \(R_i\) express all tensors through the first one.
Write the cyclic-shift gauge relation from one site to the next and iterate it along the chain. At the first site one takes \(L_0=R_0=\mathbb {1}\); passing from \(v\) to \(v+1\) multiplies the left and right virtual factors by the adjacent gauges.
Let \(A_0,\ldots ,A_{n-1}\) be an injective site-dependent closed chain with positive bond dimension on \(n\ge 3\) sites. If its generated state is invariant under the cyclic translation of the sites, then for every site \(v\) there are invertible matrices \(L_v\) and \(R_v\) such that \(A_v^i=L_vA_0^iR_v^{-1}\) for every physical index \(i\). This is the uniform-bond-dimension form of the \(L_v,R_v\) step in the Applications-section proof of [ 220 , lines 1803–1890 ] .
Apply the injective chain theorem to the chain and its cyclic shift, then telescope the resulting bond gauges around the chain.
Let \(A_0,\ldots ,A_{n-1}\) be an injective site-dependent closed chain on \(n\ge 3\) sites, with one physical dimension \(d\) and one positive bond dimension \(D\). If the closed-chain state is invariant under the cyclic shift \(A_v\mapsto A_{v+1}\), then there is an injective tensor \(B\), with bond dimension \(D\), such that, for every physical configuration \(\sigma \),
This is the uniform-bond-dimension target corresponding to the Applications-section corollary of [ 220 , lines 1803–1890 ] . The source also concludes that all bond dimensions of the original site-dependent representation are equal; in the present uniform-dimension statement that clause has already been built into the setting.
Apply Corollary 24.9.4.15 to compare the chain with its cyclic shift, giving one invertible gauge \(Z_v\) per bond with \(A_{v+1}^i=Z_vA_v^iZ_{v+1}^{-1}\). Telescoping the gauges into the running products \(P_m=Z_{m-1}\cdots Z_0\) expresses every tensor through the first, \(A_m^i=P_m(A_0^iZ_0)P_{m+1}^{-1}\), so the closed trace collapses to \(\operatorname{tr}(B^{\sigma _0}\cdots B^{\sigma _{n-1}}P_n^{-1})\) with the tentative repeated tensor \(B=A_0Z_0\). Reading the gauge relation across the seam \(A_{n+1}\equiv A_0\) shows that the loop product \(P_n\) commutes with the full matrix algebra spanned by \(B\), hence is a scalar \(\lambda \ne 0\). Since \(\mathbb {C}\) is algebraically closed, there is an \(n\)-th root \(c^n=\lambda ^{-1}\); the rescaled tensor \(cB\) is still injective and its constant chain generates the same closed state.
Let \(A_0,\ldots ,A_{n-1}\) be a site-dependent injective closed MPS on \(n\ge 3\) sites, with dimensions \(D_e\) on its individual bonds. If the closed-chain state is translationally invariant, in the finite closed-chain sense that it is invariant under the cyclic shift \(A_v\mapsto A_{v+1}\) of [ 220 , lines 1807–1827 ] , then there are a positive integer \(D\) and an injective tensor \(B\) of \(D\times D\) matrices such that \(D_e=D\) for every bond \(e\) and
for every physical configuration \(\sigma \).
This completes the at-least-three-site form of the translational-invariance corollary and its proof in [ 220 , lines 1803–1890 ] . The equality \(D_e=D\) is Corollary 24.9.4.13. Identifying each virtual space with \(\mathbb {C}^D\) gives a uniform closed-chain representation, to which the source’s \(L_i,R_i\) telescoping and repeated-tensor construction apply. The source section places its injective Fundamental Theorem in the regime of at least three sites; the omitted two-site case is false by Theorem 24.9.4.14, as recorded in [ 29 ] .
By Corollary 24.9.4.13, every bond has the dimension \(D\) of a fixed reference bond. Write \(e_v\) for the bond from \(v\) to \(v+1\), transport every bond index to \(\{ 0,\ldots ,D-1\} \), and let
where \(A'_v\) is the transported local tensor. If \(g(v)=\eta (e_v)\), the two corresponding changes of finite summation variables give
Each \(\iota _v\) is a bijection, so the same coordinate change preserves injectivity of every local tensor. If \(r(v)=v+1\) is the cyclic rotation, then \(\operatorname{Coeff}_{\mathrm{shift}(C)}(\sigma )=\operatorname{Coeff}_C(\sigma \circ r^{-1})\); hence cyclic-shift invariance is preserved. Apply Corollary 24.9.4.18 to this uniform chain. Its \(L_i,R_i\) telescoping and seam closure produce the required repeated injective tensor \(B\).
Let \(A\) be an injective PEPS on a discrete \(n\times m\) torus with \(n,m{\gt}1\). If its represented state is translation invariant, then its bond dimensions are orientation-uniform. Explicitly, with
at the reference right and up edges, every horizontal edge has dimension \(D_h\) and every vertical edge has dimension \(D_v\).
This is the first conclusion of the two-dimensional Applications-section corollary in [ 220 , lines 1891–1894 ] .
State translation invariance identifies \(A\) with \(A^{\tau _{a,b}}\) at every translation. Transport preserves injectivity, so Theorem 24.4.1.23 gives
Translations act transitively on the horizontal edges and separately on the vertical edges. Applying the displayed equality to the reference right and up edges gives the two claimed constants.
Let \(A\) be an injective PEPS on a discrete \(n\times m\) torus with \(n,m{\gt}1\). If the generated state is invariant under all lattice translations \(\tau _{a,b}\), that is, \(\operatorname{Coeff}_A(\sigma \circ \tau _{a,b})=\operatorname{Coeff}_A(\sigma )\) for every translation and every physical configuration \(\sigma \), then there are positive dimensions \(D_h,D_v\) such that the bond dimensions of \(A\) are orientation-uniform with these values, and there is an injective translation-invariant torus tensor \(B\) with the same bond-dimension function and the same represented state as \(A\).
This is the full two-dimensional Applications-section corollary of [ 220 , lines 1891–1894 ] .
The bond-dimension assertion is Corollary 24.9.4.20. The construction of the site-independent injective tensor \(B\) is the remaining part of the corollary.
Under the positive-bond-dimension hypotheses of Corollary 24.9.4.10, suppose \(Z_v\) and \(Z'_v\) are two families of invertible matrices satisfying \(B_v^i=Z_vA_v^iZ_{v+1}^{-1}\) and \(B_v^i=Z'_vA_v^i(Z'_{v+1})^{-1}\) for every \(v,i\). Then there is a single nonzero scalar \(c\) such that \(Z'_v=cZ_v\) for every bond \(v\). This is the uniqueness clause in [ 220 , line 724 ] .
For each bond put \(C_v=Z_v^{-1}Z'_v\). Comparing the two gauge relations gives \(C_vA_v^i=A_v^iC_{v+1}\) for every local matrix. Since the matrices of \(A_v\) span the full matrix algebra, evaluating this identity on the identity matrix gives \(C_v=C_{v+1}\); hence all \(C_v\) are one common matrix. The same relation then says that this common matrix commutes with the full matrix algebra, so it is a scalar matrix. Its invertibility makes the scalar nonzero.
Two remarks place these statements against [ 220 ] . The injective matrix product states of the opening section of [ 220 ] are the case \(L=1\), in which a single tensor already spans the matrix algebra; the corollaries above contain them at \(n\ge 3\), with no separate argument needed. The site-dependent results are stated for one physical dimension \(d\) and one bond dimension \(D\) around the chain, while [ 220 ] places no restriction on the local dimensions; this uniform-dimension restriction is the only narrowing.
24.10 The vertex-injective case and the residual edge scalars
Suppose PEPS tensors \(A\) and \(B\) on a connected graph are injective, generate the same state, and \(A\) satisfies the normal blocking hypotheses. Then their defining tensors are related by a local gauge. This is the vertex-injective specialization of the general normal-PEPS theorem: when each single tensor is already injective, the gauge follows from the injective Fundamental Theorem, without requiring the region blocking hypotheses.
Injectivity, same state, and connectivity are exactly the hypotheses of the injective Fundamental Theorem, which supplies the local gauge.
An edge-scalar family \(c=(c_e)_{e\in E}\) determines the endpoint scalar \(c_{v,e}\) by \(c_{v,e}=c_e\) at the lower endpoint of \(e\) and \(c_{v,e}=c_e^{-1}\) at the upper endpoint.
An edge-scalar family is vertex-balanced when \(\prod _{e\ni v}c_{v,e}=1\) for every vertex \(v\).
24.11 Balanced Edge Scalars
The edge gauges are determined only up to a scalar on each edge. The residual freedom is the balanced edge scalars: a nonzero scalar \(c_e\) on every edge, whose endpoint readings \(c_{v,e}\) multiply to one around each vertex, \(\prod _{e\ni v}c_{v,e}=1\).
 \(\prod _{e\ni v}c_{v,e}=1\).
Two gauge families related by such an assignment give the same gauge equivalence, which is the precise sense in which the gauges of the Fundamental Theorem are unique: modulo balanced edge scalars, not modulo a single global constant.
Two gauge families are equivalent modulo balanced edge scalars if there is a nonzero scalar \(c_e\) on each edge such that the corresponding endpoint actions satisfy \(X_{v,e}=c_{v,e}Y_{v,e}\), and \(\prod _{e\ni v}c_{v,e}=1\) for every vertex \(v\).
If two edge-scalar families are multiplied, then their endpoint scalars satisfy \((cd)_{v,e}=c_{v,e}d_{v,e}\) on every oriented half-edge.
At the lower endpoint this is ordinary multiplication of the edge scalars. At the upper endpoint, \((c_ed_e)^{-1}=c_e^{-1}d_e^{-1}\) because the edge scalars lie in \(\mathbb {C}^\times \).
Inverting an edge-scalar family gives \((c^{-1})_{v,e}=c_{v,e}^{-1}\) on every oriented endpoint.
At the lower endpoint, \((c^{-1})_{v,e}=c_e^{-1}=c_{v,e}^{-1}\). At the upper endpoint, \((c^{-1})_{v,e}=(c_e^{-1})^{-1}=c_{v,e}^{-1}\).
Every oriented endpoint scalar satisfies \(c_{v,e}\ne 0\).
Edge scalars are units, and the inverse of a unit is again a unit.
The pointwise product of two vertex-balanced edge-scalar families is again vertex-balanced.
For every vertex \(v\), \(\prod _{e\ni v}(cd)_{v,e} =(\prod _{e\ni v}c_{v,e})(\prod _{e\ni v}d_{v,e}) =1\cdot 1=1\).
The pointwise inverse of a vertex-balanced edge-scalar family is again vertex-balanced.
For every vertex \(v\), \(\prod _{e\ni v}(c^{-1})_{v,e} =(\prod _{e\ni v}c_{v,e})^{-1}=1^{-1}=1\).
Every edge-gauge family is equivalent to itself modulo balanced edge scalars, witnessed by \(c_e=1\) for every edge \(e\).
If \(c_e=1\), then \(c_{v,e}=1\), \(X_{v,e}=c_{v,e}X_{v,e}\), and \(\prod _{e\ni v}c_{v,e}=1\).
If one gauge family differs from another by balanced edge scalars, then the second differs from the first by the inverse balanced edge-scalar family.
If \(X_{v,e}=c_{v,e}Y_{v,e}\) with \(c_{v,e}\ne 0\), then \(Y_{v,e}=c_{v,e}^{-1}X_{v,e}\). The inverse scalar family is balanced by Theorem 24.11.6.
If \(c\) and \(d\) witness the equivalences of \(X\) with \(Y\) and of \(Y\) with \(Z\) modulo balanced edge scalars, then their pointwise product scalar family \((cd)_e = c_e d_e\) witnesses that \(X\) is equivalent to \(Z\) modulo balanced edge scalars.
From \(X_{v,e}=c_{v,e}Y_{v,e}\) and \(Y_{v,e}=d_{v,e}Z_{v,e}\) one obtains \(X_{v,e}=(c_{v,e}d_{v,e})Z_{v,e}\). The product scalar family is balanced by Theorem 24.11.5.
Gauge equivalence modulo balanced edge scalars is reflexive, symmetric, and transitive.
Reflexivity is witnessed by \(1\), symmetry by \(c^{-1}\), and transitivity by \(cd\).
The preceding equivalence relation is the quotient relation on edge-gauge families modulo vertex-balanced edge scalars.
If two gauge families \(X\) and \(Y\) differ by a balanced edge-scalar reweighting, then for every vertex \(v\), virtual configuration \(\eta \), and physical index \(\sigma \),
In each summand of the gauged tensor at \(v\), the edge scalars contribute the factor \(\prod _{e\ni v}c_{v,e}=1\). Hence the summand, and therefore the whole local tensor, is unchanged.
If two gauge families \(X\) and \(Y\) differ by a balanced edge-scalar reweighting, then applying them to the same PEPS tensor \(A\) produces the same gauged tensor:
For every vertex \(v\), virtual index \(\eta \), and physical index \(\sigma \), \((A^X)_v(\eta ,\sigma )=(A^Y)_v(\eta ,\sigma )\) for the two gauged tensors by Theorem 24.11.12. Hence the two gauged tensors are equal.
If two gauge families \(X\) and \(Y\) differ by a balanced edge-scalar reweighting, then the PEPS tensors obtained by applying those gauge families represent the same state: for every physical configuration \(\sigma \),
The two gauged tensors are equal, hence all of their state coefficients are equal.
If two gauge families relate the same injective PEPS tensor to the same target tensor, then their edge gauges differ by nonzero scalars \(c_e\) whose oriented product at every vertex is \(1\). Thus the correct graph quotient is by balanced edge scalars.
Combining the two gauge relations gives, at every vertex, equality of the gauged local tensors. Linear independence of the local tensor family promotes this to equality of the products of incident edge-gauge entries over every pair of virtual configurations. Each oriented endpoint gauge is invertible and, since every bond space is nonzero, indexed by a nonempty type; the many-leg scalar extraction then yields, at each vertex, nonzero proportionality constants between the two families whose product is \(1\). Reading the lower-endpoint constant of each edge defines a single edge scalar \(c_e\); the inverse relation transports it to the upper endpoint, and invertibility makes the proportionality constant unique, so the vertex products of the per-vertex constants identify with the oriented products of \(c_e\). These are all \(1\), so \(c\) is vertex-balanced.
The local left inverse \(\Psi _v\), the realization map \(T \mapsto O_T\), the split at one incident edge, and the partition \(V = \{ u\} \sqcup (V \setminus \{ u,v\} ) \sqcup \{ v\} \) provide the local structure for the edge-centered reduction of [ 220 , Section 3 ] . The local gauge then follows from comparison with the corresponding three-site injective chain, with uniqueness determined modulo balanced edge scalars.
24.11.1 Inserted-site scalar extraction
The final comparison of [ 220 , Section 3, proof of Theorem 3 ] turns two region proportionalities into a single scalar at one site. Fix a finite region \(R\) and a site \(v\notin R\), and write \(S=R\cup \{ v\} \) for the region with \(v\) adjoined. A local configuration \(\eta \) at \(v\) assigns a virtual index to every edge incident to \(v\). The label on its \(v\)-incident \(R\)-boundary edges reads \(\eta \) on the \(v\)-incident edges that bound \(R\), while the base boundary label \(\mu \) fixes the remaining \(v\)-incident edges. Under inserted-site consistency, the \(R\)-boundary label and the values fixed by \(\mu \) on the remaining \(v\)-incident edges determine \(\eta \) completely.
Fix a region \(R\) and a site \(v\notin R\), and let \(\mu \) be a boundary label of \(S=R\cup \{ v\} \). Two local configurations at \(v\) that are both consistent with \(\mu \) and carry the same \(R\)-boundary label coincide.
Read both configurations on each \(v\)-incident edge. On a \(v\)-incident edge that bounds \(R\) the value is the shared \(R\)-boundary label. On a \(v\)-incident edge that does not bound \(R\), the edge runs from \(v\) to a site outside \(S\), and inserted-site consistency reads the value from \(\mu \). Both readings agree edge by edge, so the two configurations are equal.
Let \(A\) and a comparison tensor \(C\) share their bond dimensions and have positive bond dimensions, and suppose the \(R\)-blocked family of \(C\) is linearly independent. If the blocked weights satisfy the two region proportionalities \(A_R=c_R C_R\) and \(A_S=c_S C_S\) over \(R\) and over \(S=R\cup \{ v\} \), with \(c_R\ne 0\), then the inserted-site tensors are proportional with ratio \(c_S/c_R\) at every local configuration \(\eta \) at \(v\) and every physical index \(\sigma \):
Write \(b(\mu ,\eta )\) for the label that a local configuration \(\eta \) at \(v\), consistent with the base boundary label \(\mu \), induces on the \(v\)-incident edges that bound \(R\). With \(m\) the bond-only inserted-site multiplicity, the inserted-site factorization reads each blocked weight of \(S\) as the inserted-site tensor summed against the \(R\)-boundary-label blocked weight of \(R\) over the local configurations consistent with \(\mu \):
and likewise for \(C\). Feeding both proportionalities through (70), cancelling the nonzero \(m\), and substituting the \(R\)-proportionality leaves, for every base label \(\mu \), a vanishing combination of the \(R\)-blocked family of \(C\) with coefficient \(c_R\, A_v(\eta )-c_S\, C_v(\eta )\) summed over the consistent local configurations. By Lemma 24.11.1.1 the consistent configurations inject into their \(R\)-boundary labels, so linear independence of the \(R\)-blocked family separates the combination to one term, forcing \(c_R\, A_v(\eta ,\sigma )=c_S\, C_v(\eta ,\sigma )\) and hence (69).
Suppose \(A\) and \(B\) have the same bond dimension on every edge, and that these bond dimensions are positive. Let \(C\) be the gauge action of \(X\) on \(B\), reindexed along this bond-dimension equality, and assume that the \(R\)-blocked family of \(C\) is linearly independent. If the two two-block scalar proportionalities of the blocked weights of \(A\) and \(C\) over \(R\) and over \(S=R\cup \{ v\} \) hold, with ratios \(c_R\) and \(c_S\) and with \(c_R\ne 0\), then the per-vertex gauge relation
holds at every local configuration \(\eta \) at \(v\) and every physical index \(\sigma \).
24.12 Exact contraction on the open square grid
For \(\Lambda =\{ 0,\ldots ,L-1\} ^2\), a forward edge is an ordered pair \(((x,y),(x+1,y))\) or \(((x,y),(x,y+1))\) with both endpoints in \(\Lambda \).
The forward edges are in bijection with the lexicographically oriented edges of the open square graph by preserving both endpoints. For every vertex this gives a bijection of incident edges, and for every family of dimensions \((D_e)_e\) it gives a bijection of assignments \(\prod _e\{ 0,\ldots ,D_e-1\} \), with each coordinate unchanged.
Let \(A_v\) be arbitrary local tensors with physical dimension \(q\) and edge-dependent virtual dimensions \(D_e\). Transport each virtual coordinate along the edge correspondence, and put the physical argument last when it was written first. The resulting graph tensor \(\widetilde A\) has dimensions \(\widetilde D_{\iota (e)}=D_e\). For every physical configuration \(s\),
The same equality holds when the source tensor already has its physical argument last. The physical-first assertion permits zero virtual dimensions.
Reindex the finite sum by the bijection of virtual assignments. Its restriction to every incident edge preserves that edge’s index, so each factor in the vertex product is equal.
A local tensor may be written as \(A_v(s_v,a|_v)\) or \(A_v(a|_v,s_v)\). In either case its contraction is the vector in \(\ell ^2(\Lambda \to \{ 0,\ldots ,q-1\} ;\mathbb {C})\) whose \(s\) coordinate is \(\sum _a\prod _v A_v(s_v,a|_v)\), with the arguments reversed in the second presentation. The second presentation includes the requirement \(D_e{\gt}0\). Its maximum bond dimension is \(\max (\{ D_e:e\in E\} \cup \{ 0\} )\).
24.13 Physical consequences of the square-grid correspondence
The physical coordinates are identical in both presentations, so the coordinate identification is a linear isometry. The transported contraction equals the original vector \(\Phi \). In particular its norm and nonvanishing are unchanged, and so is every error \(\| \| \Phi \| ^{-1}\Phi -z\Omega \| \), for every vector \(\Omega \) of the common Euclidean space and every \(z\in \mathbb {C}\). The equality includes \(\Phi =0\) with the convention \(0^{-1}=0\).
Apply coordinatewise equality of the contractions in their common Euclidean space.
Any pointwise condition on \(D_e\) is equivalent to the same condition on the transported dimensions. For \(B\in \mathbb {N}\), the maximum bond dimension is at most \(B\) exactly when each transported bond dimension is at most \(B\), and the same equivalence holds for every real threshold \(B\ge 0\). For every region \(R\subseteq \Lambda \), the edge correspondence restricts to a bijection of crossing edges and preserves their cardinality.
Every edge retains its dimension and its two endpoints. The empty maximum is zero. For a real threshold \(B\ge 0\), compare natural dimensions with \(\lfloor B\rfloor \).
Let \(L\ge 0\) be an integer. The nearest-neighbor graph on \(\{ 0,\ldots ,L-1\} ^2\), with open boundary, has at most \(2L^2\) edges. This is the elementary counting bound used in the doubled-Hamiltonian boundary estimate of [ 248 ] .
Orient every horizontal edge to the right and every vertical edge upward. Each edge is determined by its initial vertex and its orientation. There are \(L^2\) vertices and two orientations, so the edge set injects into a set of cardinality \(2L^2\). This argument also includes \(L=0,1\).
For every region \(R\), the two contractions have equal unnormalized reduced densities \(\operatorname{tr}_{R^c}|\Phi \rangle \langle \Phi |\) and equal von Neumann entropies of these densities. The densities have trace \(\| \Phi \| ^2\), so the entropy is the entanglement entropy of the region only when \(\| \Phi \| =1\). Writing the complement as a finite-set difference or as nonmembership gives the same partial trace after the coordinatewise identification of complement configurations.
With \(M_{x,z}=\Phi (x\cup z)\) as in Definition 24.13.7,
and the coefficient equality of the two contractions gives the same matrix \(M\) for both. The complement \(R^c\) is indexed either by \(\Lambda \setminus R\) as a finite set or by the sites not in \(R\); the bijection between the two index sets maps a configuration \(z\) to the configuration with the same value at every site, so it reindexes the sum in (73). Equal matrices have equal von Neumann entropies.
Fix a target vector \(\Omega \). The physical-first approximation constraint asks for positive \(D_e\le CL^c\), a nonzero contraction \(\Phi \), and a phase \(\theta \) with \(\| \| \Phi \| ^{-1}\Phi -e^{i\theta }\Omega \| \le L^{-1}\). The virtual-first phase-error predicate concerns vectors only: for vectors \(x,\Omega \) and \(\varepsilon \in \mathbb R\) it asks for a phase \(\theta \) that minimizes the normalized error of \(x\) against \(e^{i\varphi }\Omega \) over all real \(\varphi \) and attains error at most \(\varepsilon \). Bond-dimension bounds and nonvanishing of the contraction are separate hypotheses in that presentation.
For every target vector \(\Omega \), an approximation witness in either source presentation gives a graph PEPS on the original open square with the same positive dimensions, bound \(CL^c\), and error \(L^{-1}\). The entire minimizing-phase condition is preserved for the virtual-first presentation.
Use the transported tensor. Its dimensions are identical edge by edge; substitute the equality of its vector in the nonzero and phase-error conditions.
Let \(\Omega \) be a vector on the sites \(\Lambda \) of the square and \(R\subseteq \Lambda \). For configurations \(x\) on \(R\) and \(z\) on \(R^c\), let \(x\cup z\) be their joined configuration and set \(M_{x,z}=\Omega (x\cup z)\). The unnormalized regional density of \(\Omega \) is \(MM^\dagger \). For \(\Omega =\Phi \) it equals the partial trace in Theorem 24.13.4.